Industrial Robot Arms
An industrial robot arm is a programmable manipulator built for repetitive factory work: moving parts, welding, painting, assembling, and tending machines. It is the oldest and most common kind of robot in the world, and most of the tutorials and simulators you meet assume one.
Typical characteristics
- Serial chain. The links run in a single chain from the base to the tool. Most arms have six revolute joints: three that position the wrist in space and three that orient the tool.
- A wrist built for easy math. On many six-axis arms the three wrist axes meet at a point. That makes the inverse kinematics, the calculation of joint angles for a target pose, much simpler.
- SCARA arms. A SCARA arm has four axes: two revolute joints that swing in a horizontal plane, one prismatic joint that moves the tool up and down, and a final rotation. They are fast and stiff for pick-and-place and assembly from above.
- A wide range of sizes. From a tabletop arm that carries a few kilograms to a heavy arm that carries hundreds, with reach to match.
- High speed and repeatability. They are built to return to the same point accurately, cycle after cycle.
- Fixed in place. Arms are bolted to the floor, a pedestal, a wall or the ceiling, and usually work inside a guarded cell. A robot that can work next to people without a fence is a cobot.
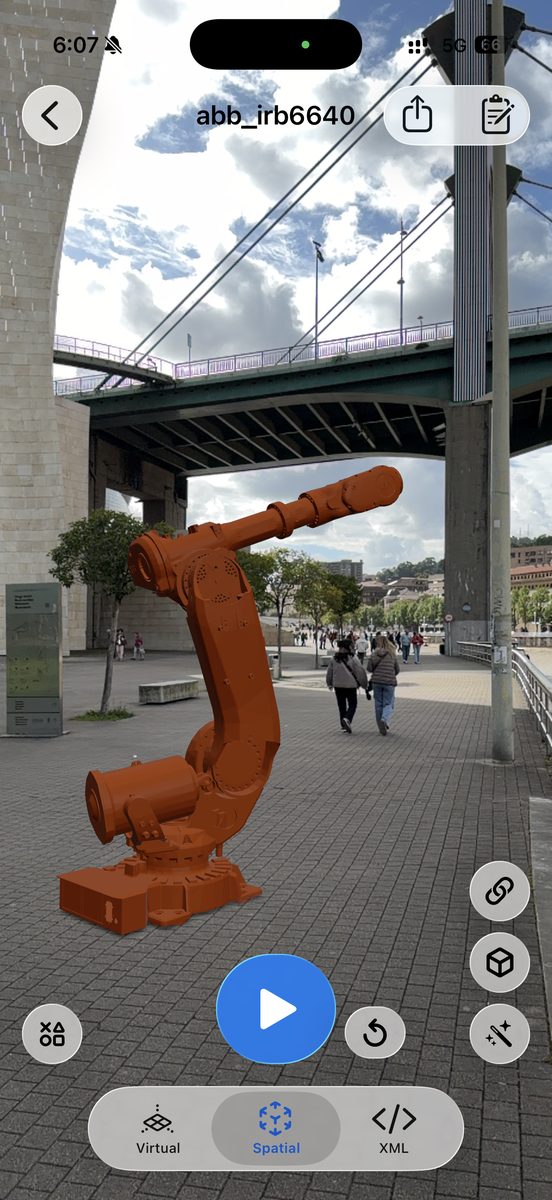
A six-axis arm, the ABB IRB 6640 from the gallery, placed on the floor in ARMOR’s Spatial view.
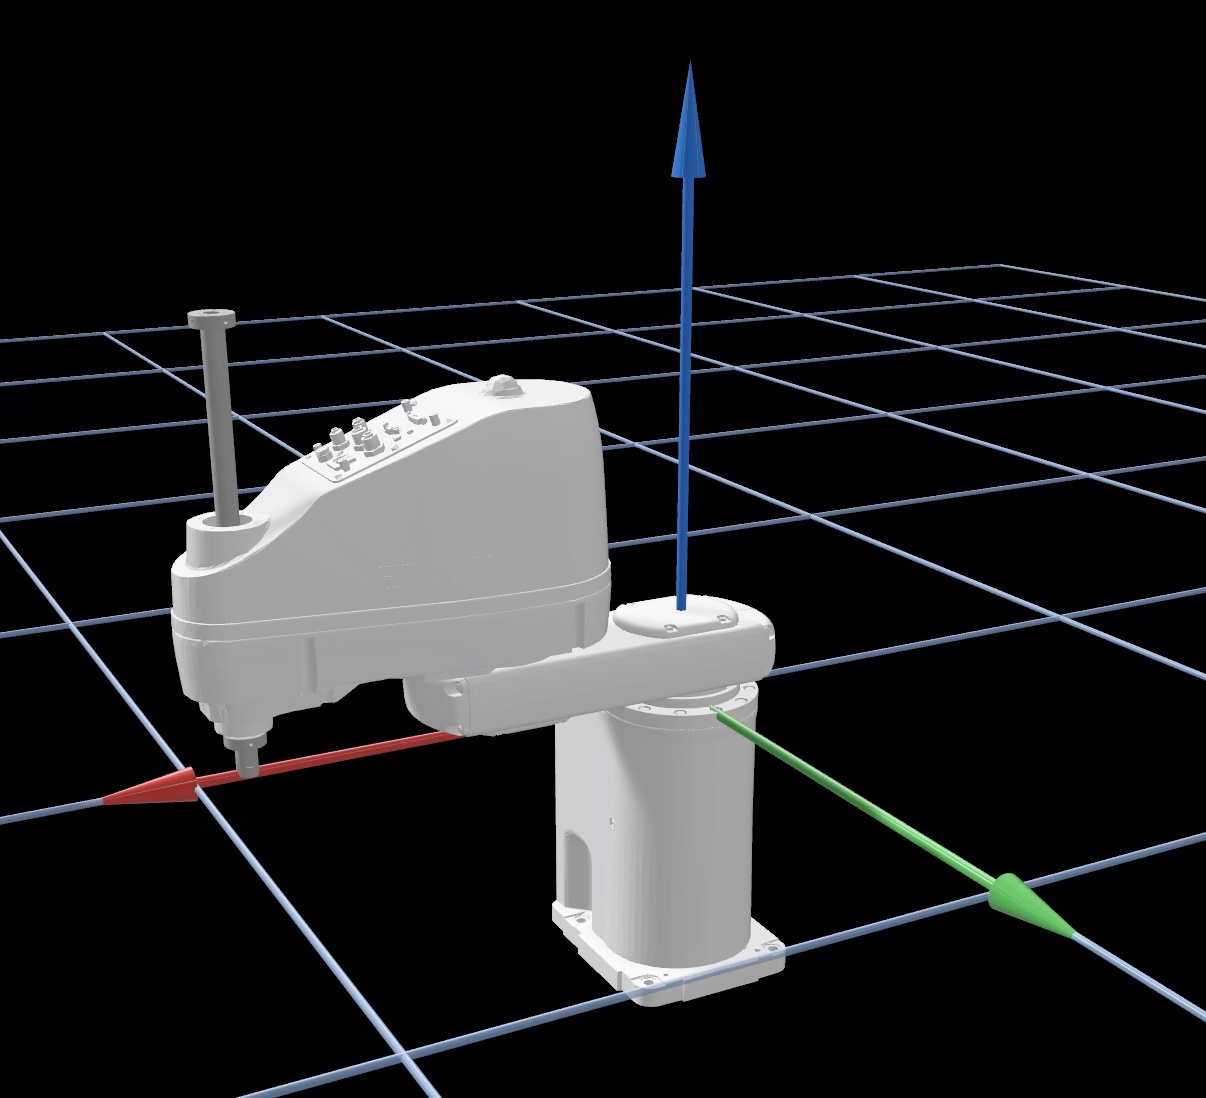
A four-axis SCARA arm, the Epson GX8-C452S from the gallery, in ARMOR’s 3D view. The vertical shaft at the left is the prismatic axis that moves the tool up and down.
In a URDF and in ARMOR
- Fixed base. Choose a fixed (welded) base so the arm stays bolted down. See Worlds & Robot Placement. Gallery arms import this way.
- Joint limits are the story. Each joint has an angle range, a speed limit and an effort limit, and these determine the reachable workspace. You can read and edit them in Joints.
- Visual and collision meshes. Vendor descriptions usually pair a detailed visual mesh with a simplified collision mesh. That keeps simulation fast, and it means the shape you see is not exactly the shape that collides.
- Missing masses. Descriptions made for visualization often carry no mass data. ARMOR can estimate it from the meshes: see Mass and Inertia.
- Driving the joints. To move an arm under physics instead of posing it, give each joint a controller with Add Default Controllers. See ros2_control Actuators.
- Linkages in the arm. Some arms add a parallelogram or parallel-link mechanism at the shoulder or elbow for rigidity under load. Kawasaki’s BX300L is described this way in the gallery. A URDF can only describe a tree of links, so such a mechanism is simplified, or coupled with mimic joints.
- Grippers. A gripper whose two fingers move together is normally one real actuator with a mimic joint on the second finger.
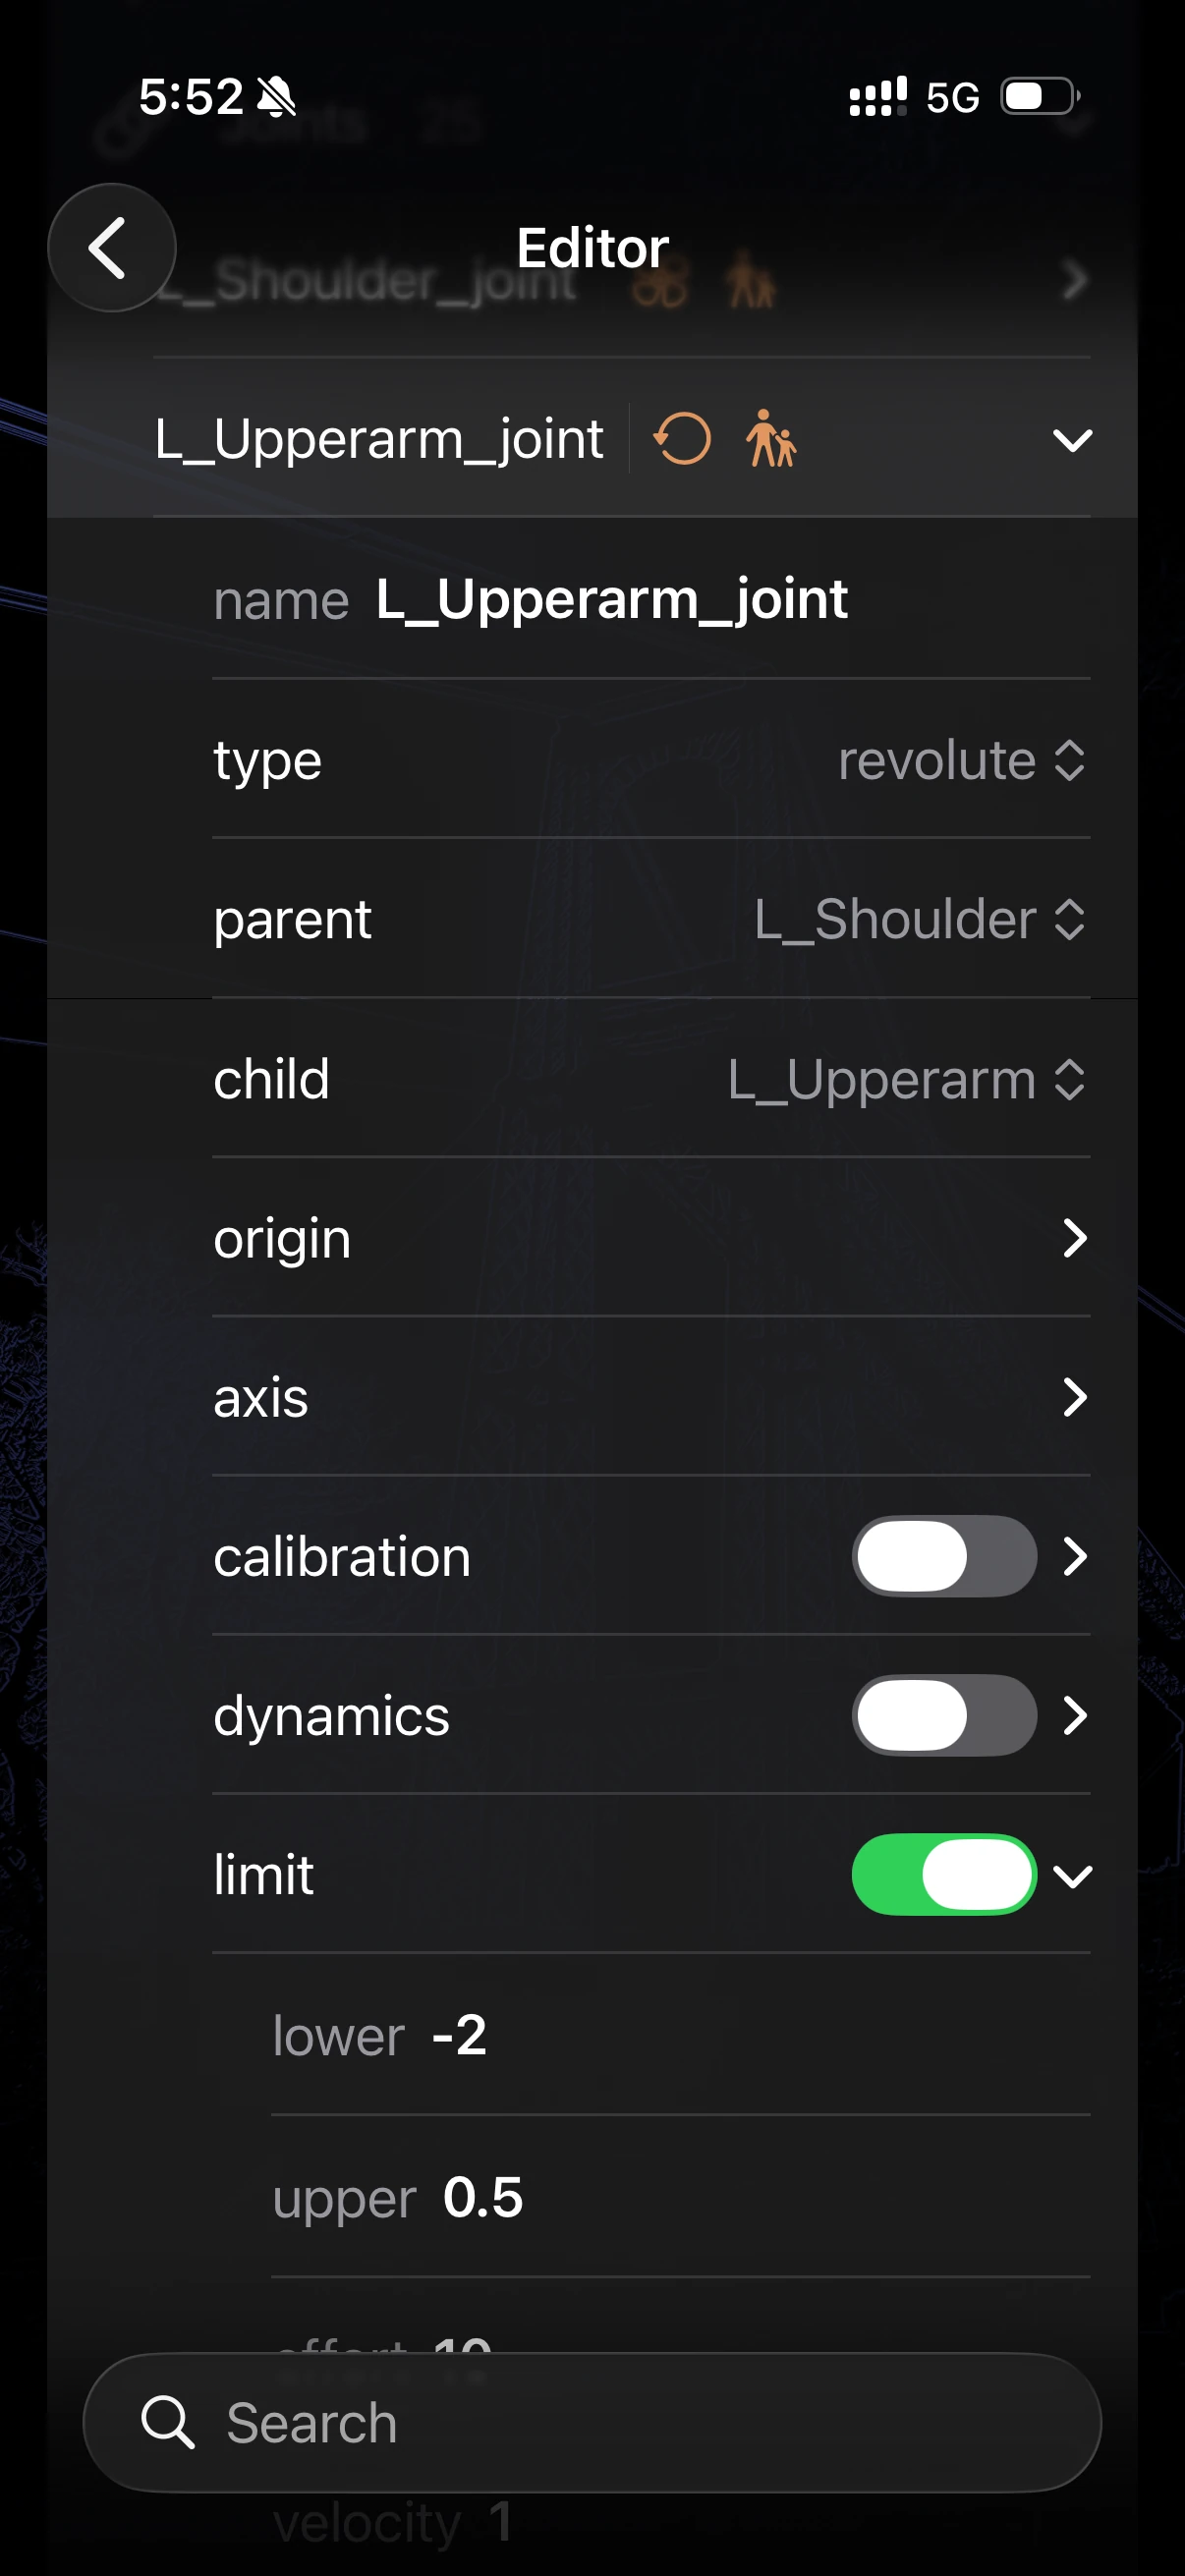
A joint expanded in the Robot editor. The limit rows hold the angle range, effort and speed that set an arm’s reachable workspace.
Real-world use and tradeoffs
Industrial arms are chosen for throughput. A larger arm carries more and reaches farther, but it is heavier and slower to start and stop, and it needs a bigger footprint and a bigger safety zone. A smaller arm is quicker and fits a bench.
The price of speed is isolation. A fast arm with a heavy payload is dangerous to a person, so it works behind fences, light curtains or other guarding, and the work cell is designed around it. Where people and robot must share space, a cobot trades some of that speed and payload for safety features.
An arm also needs more around it than the arm itself: a tool, a controller, programs, and often vision. A URDF describes only the mechanism.
Where the field is heading
As of late 2026, the biggest changes in industrial arms are in the controller and the safety rules, more than in the mechanism.
- More open controllers. New controller generations, such as ABB’s OmniCore, FANUC’s R-50iA, and KUKA’s KR C5 and iiQKA.OS2, are replacing older ones. FANUC’s R-50iA has run Python on the controller since January 2025, and FANUC released an official ROS 2 driver in December 2025 (FANUC). For simulation, vendor arms are moving closer to ROS 2 and the robot descriptions it uses.
- Revised safety standards. ISO 10218 was revised in 2025 (Part 1, Part 2), and the US followed with ANSI/A3 R15.06-2025 in September 2025 (A3).
- Simulating the cell first. In March 2026 NVIDIA announced that FANUC, ABB, Yaskawa and KUKA are integrating its Omniverse and Isaac simulation tools for virtual commissioning, which means testing a work cell in simulation before building it (NVIDIA). This is an announcement, so check each vendor for what is shipping.
- Still the workhorse. The International Federation of Robotics counted 542,076 industrial robots installed worldwide in 2024 (IFR), more than any other class.
Examples in the gallery
Browse the whole category in the gallery’s Industrial Arms filter. A few starting points:
- ABB IRB 120: ABB’s smallest six-axis arm, a 3 kg-payload, tabletop-scale robot.
- KUKA KR 6 R900 sixx: a compact, fast six-axis handling arm.
- FANUC LR Mate 200iD: a compact arm for small parts, published by FANUC.
- Yaskawa Motoman MH5: a compact, high-speed arm, published by Yaskawa.
- Stäubli RX160: a 20 kg-payload, 1.6 m-reach arm.
- ABB IRB 6700: a heavy-payload arm, 200 kg at 2.6 m reach.
- Kawasaki BX300L: a heavy arm with a parallel-link elbow.
- Epson GX8-C452S and Mitsubishi RH-6CRH6020: four-axis SCARA arms.
Where to find more models
- Vendor pages. Each gallery entry links to its maker: ABB, KUKA, FANUC, Stäubli and Epson.
- ROS-Industrial. The ros-industrial organization hosts robot descriptions for many manufacturers, one repository per family, such as abb, kuka_experimental and staubli. See Finding URDF Files.
- MuJoCo Menagerie. DeepMind’s mujoco_menagerie collects curated MuJoCo models.
- Awesome Robot Descriptions. awesome-robot-descriptions is a broad index of robot description repositories.
Next steps
- Cobots: arms designed to work next to people.
- Joints: limits, dynamics and mimic joints.
- Mass and Inertia: fix a description that has no mass data.