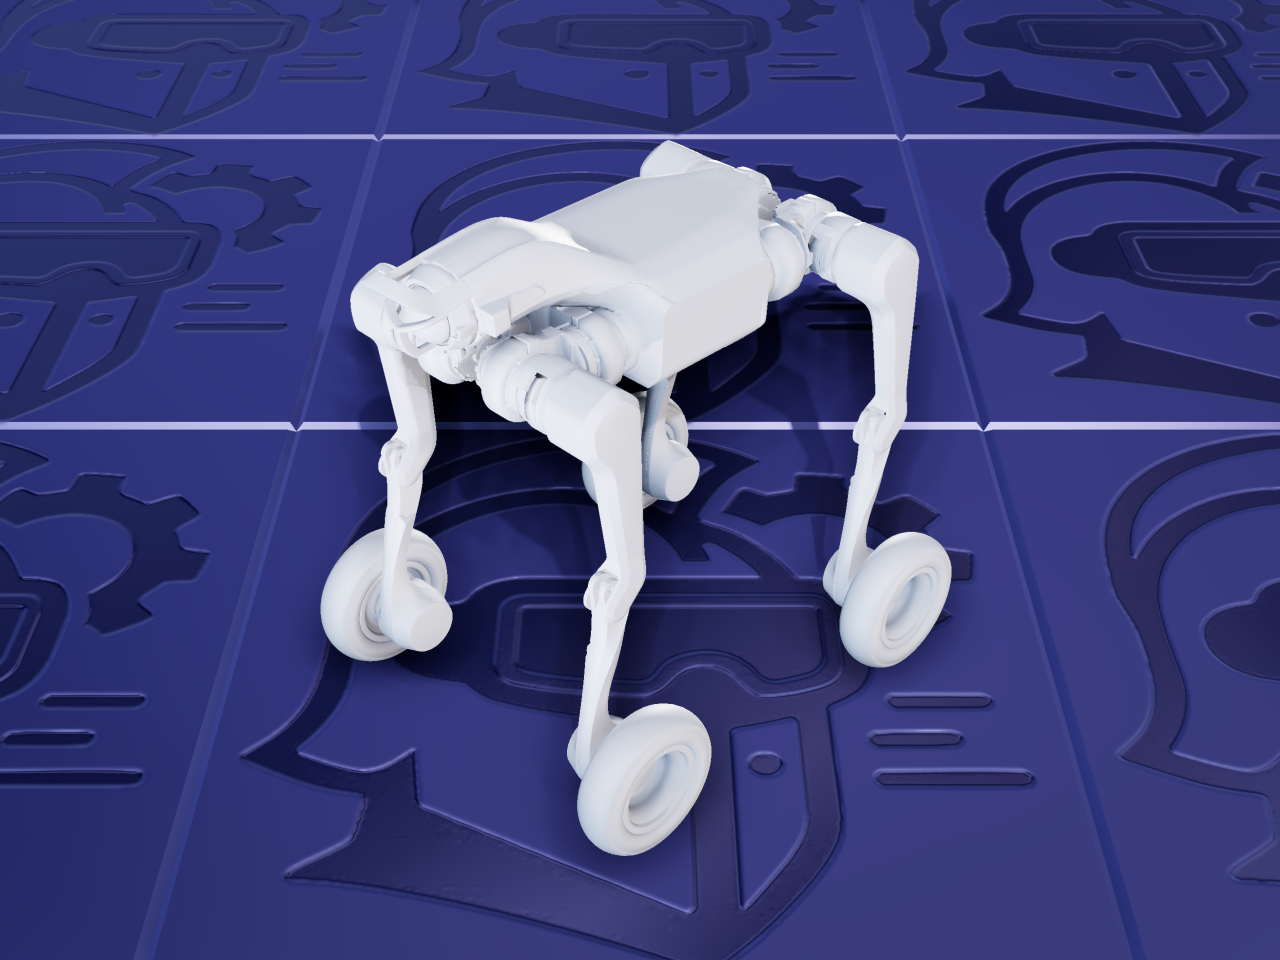
AS2-W is a wheel-legged quadruped from Unitree, listed in its
unitree_ros repository as a wheeled version of the AS2. This entry links
directly to Unitree’s own description.
The mechanism
Each of the four legs carries three actuated joints (hip, thigh and calf) and ends in a wheel on a continuous joint instead of a foot: 4 × (3 + 1) = sixteen degrees of freedom. The wheels let it roll on flat ground, and the legs let it step. There are no mimic joints or closed kinematic loops.
About this file — read before importing
This links directly to
unitree_ros’s as2w_description package,
Unitree’s own repository. ARMOR links directly to that repository rather than re-hosting
anything, so what you get is exactly what Unitree publishes, unmodified.