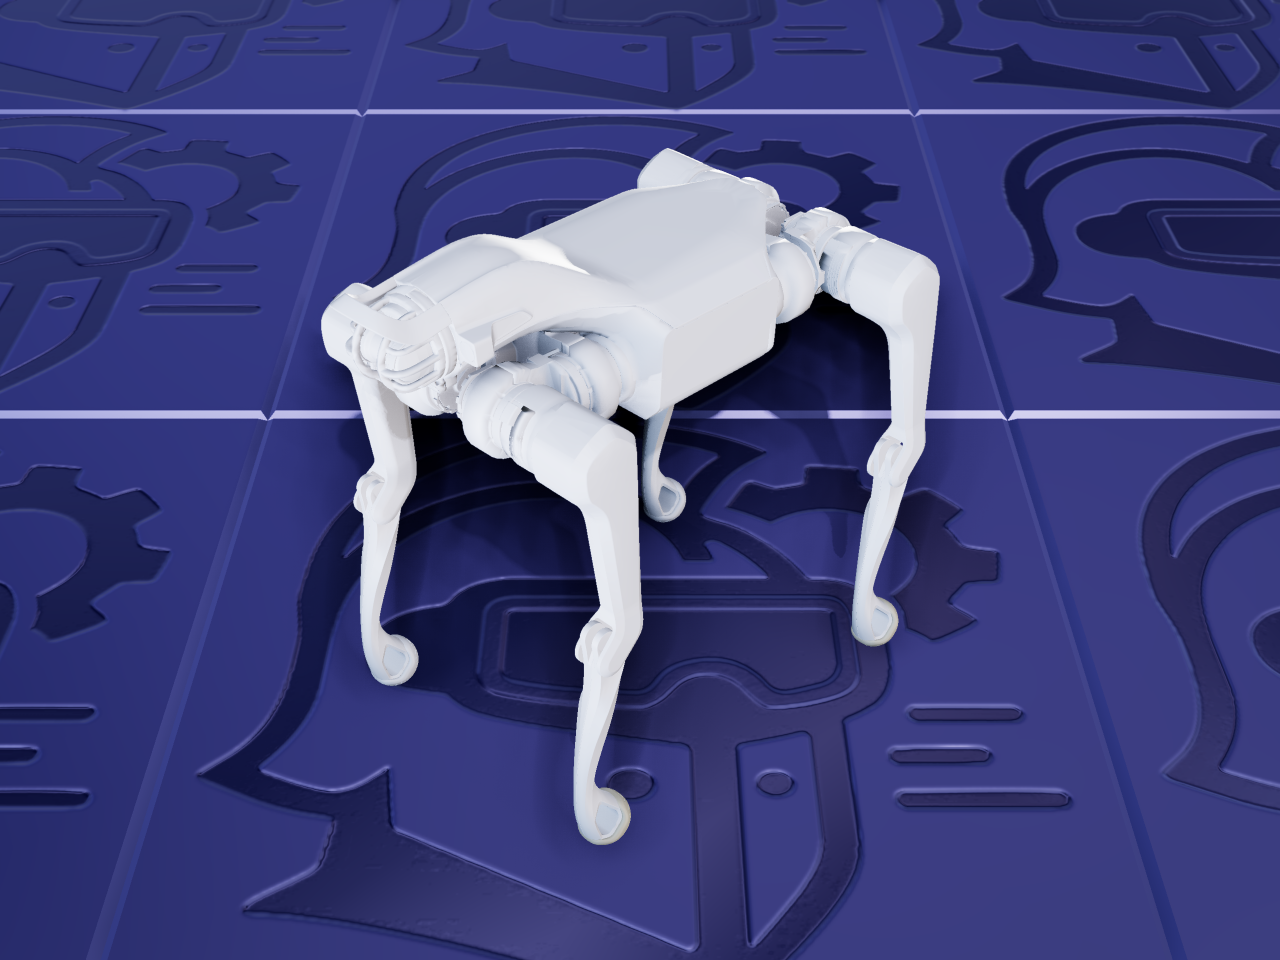
AS2 is a quadruped robot from Unitree, listed in its unitree_ros
repository beside the wheeled AS2-W. This entry links directly to Unitree’s own description.
The mechanism
Each of the four legs carries three actuated joints — a hip abduction joint, a thigh joint and a calf (knee) joint — giving twelve degrees of freedom in total. The URDF also declares a floating joint from the world to the base, which is how the robot is left free to move; it is not an actuated joint. There are no mimic joints or closed kinematic loops.
About this file — read before importing
This links directly to
unitree_ros’s as2_description package,
Unitree’s own repository. ARMOR links directly to that repository rather than re-hosting
anything, so what you get is exactly what Unitree publishes, unmodified.