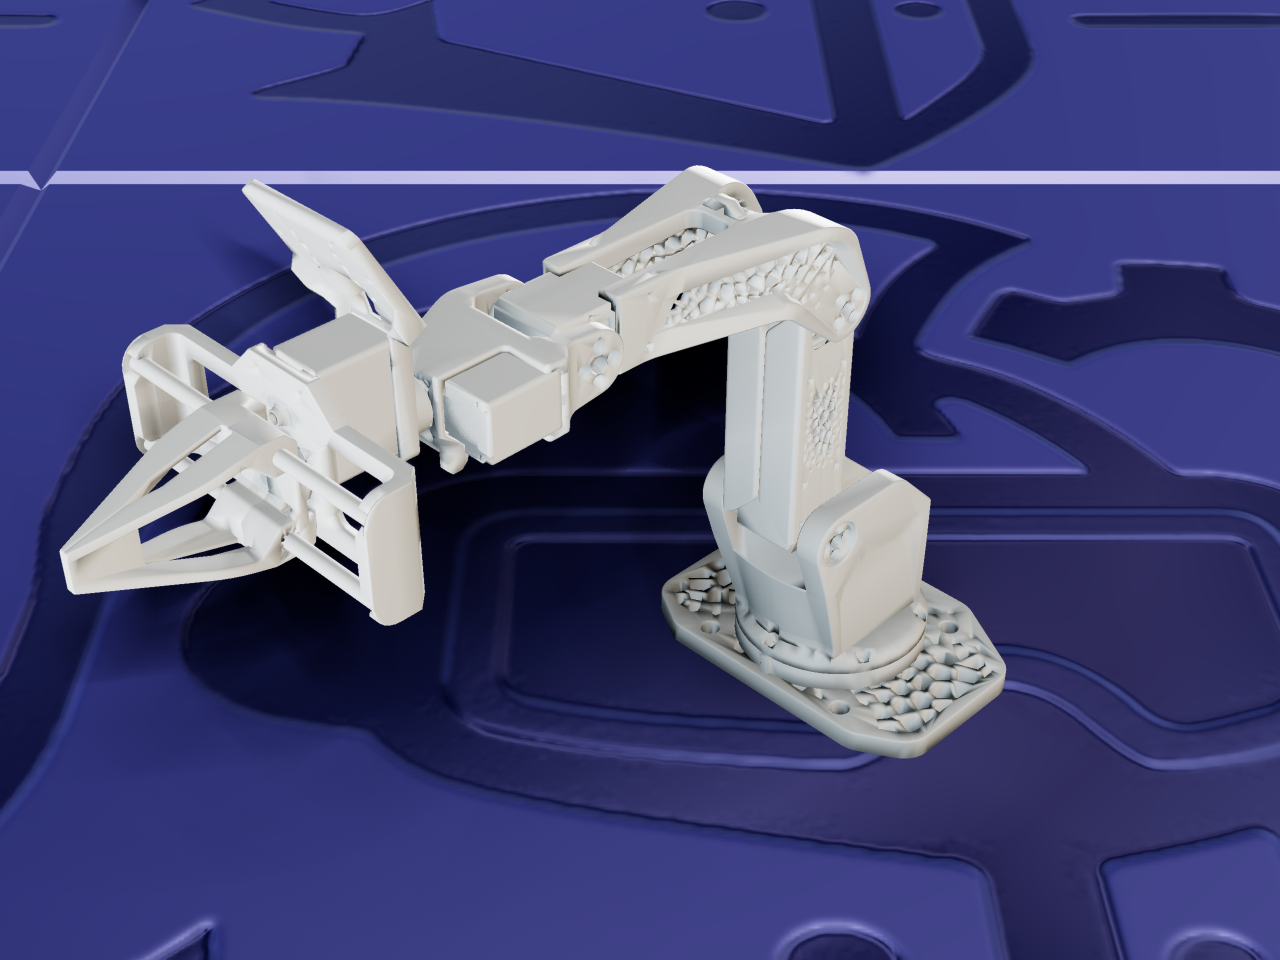
SO-ARM 102 rendered in ARMOR
Indie & Desktop manipulator desktop 3D printed open source parallel gripper 6 DOF

SO-ARM 102

by Robonine

Robonine's SO-ARM 102 — an open-source leader–follower robot arm kit for teleoperation and imitation learning that builds on the SO-ARM 100 and 101, with a stiffer carbon-fiber-filled frame and a parallel gripper.

Add to ARMOR

9 files 3.2 MB download

Opens in the ARMOR app on iPhone, iPad, or Mac. Don’t have it yet? Get ARMOR.

Model

8Links
7Joints
6Actuated DOF
8Meshes

Mesh formats: STL

SO-ARM 102 is Robonine’s open-source leader–follower robot arm kit for teleoperation and imitation learning. It builds on the SO-ARM 100 and 101 (see the SO-101 entry) with a stiffer frame printed in carbon-fiber-filled PET and a parallel gripper in place of the angular jaw. This entry links directly to Robonine’s own repository.

The mechanism

A serial chain of five revolute arm joints ends in a parallel gripper whose two jaws are prismatic joints. The second jaw is defined to follow the first through a mimic joint, so the gripper is one actuated degree of freedom and the arm has six in all. There are no closed kinematic loops. It is a desktop arm, so it is fixed-base.

About this model

Robonine generated the URDF from its CAD design and published the checks it ran on the export alongside it: that every inertia tensor is physical, that each joint’s zero lies within its limits, and that the meshes match the CAD bounds. The arm’s collision shapes are simplified boxes, and its masses are computed from the CAD volumes, the print settings and the servo weights.

About this file — read before importing

This links directly to the simulation/urdf folder of Robonine’s SO-ARM-102 repository. ARMOR links directly to that repository rather than re-hosting anything, so what you get is exactly what Robonine publishes, unmodified.

License & attribution

Source code
CC-BY-4.0
Model & mesh files
CC-BY-4.0
Attribution
SO-ARM-102 (simulation/) — Robonine — Creative Commons Attribution 4.0 International, per the repository's LICENSING.md, which assigns every file under simulation/ (the URDF, Xacro and STL meshes) to CC BY 4.0. Suggested credit: "Robonine, SO-ARM 102, https://github.com/roboninecom/SO-ARM-102, CC BY 4.0". The fabrication designs under models/ are CERN-OHL-P-2.0 and the software is Apache-2.0.

ARMOR does not host or redistribute this model. Choosing “Open in ARMOR” downloads the files directly from Robonine’s own repository, unmodified. Your use of the model is governed by the license above.

Read the full license →
ARMOR is an independent tool published by DCDC LLC. It is not affiliated with, sponsored by, or endorsed by Robonine. "SO-ARM 102" is used here only to identify the robot this file describes. This model is downloaded directly from Robonine's own repository under the Creative Commons Attribution 4.0 license, which you accept by downloading.

Looking for a different robot? Find more URDF sources or browse the rest of the gallery.