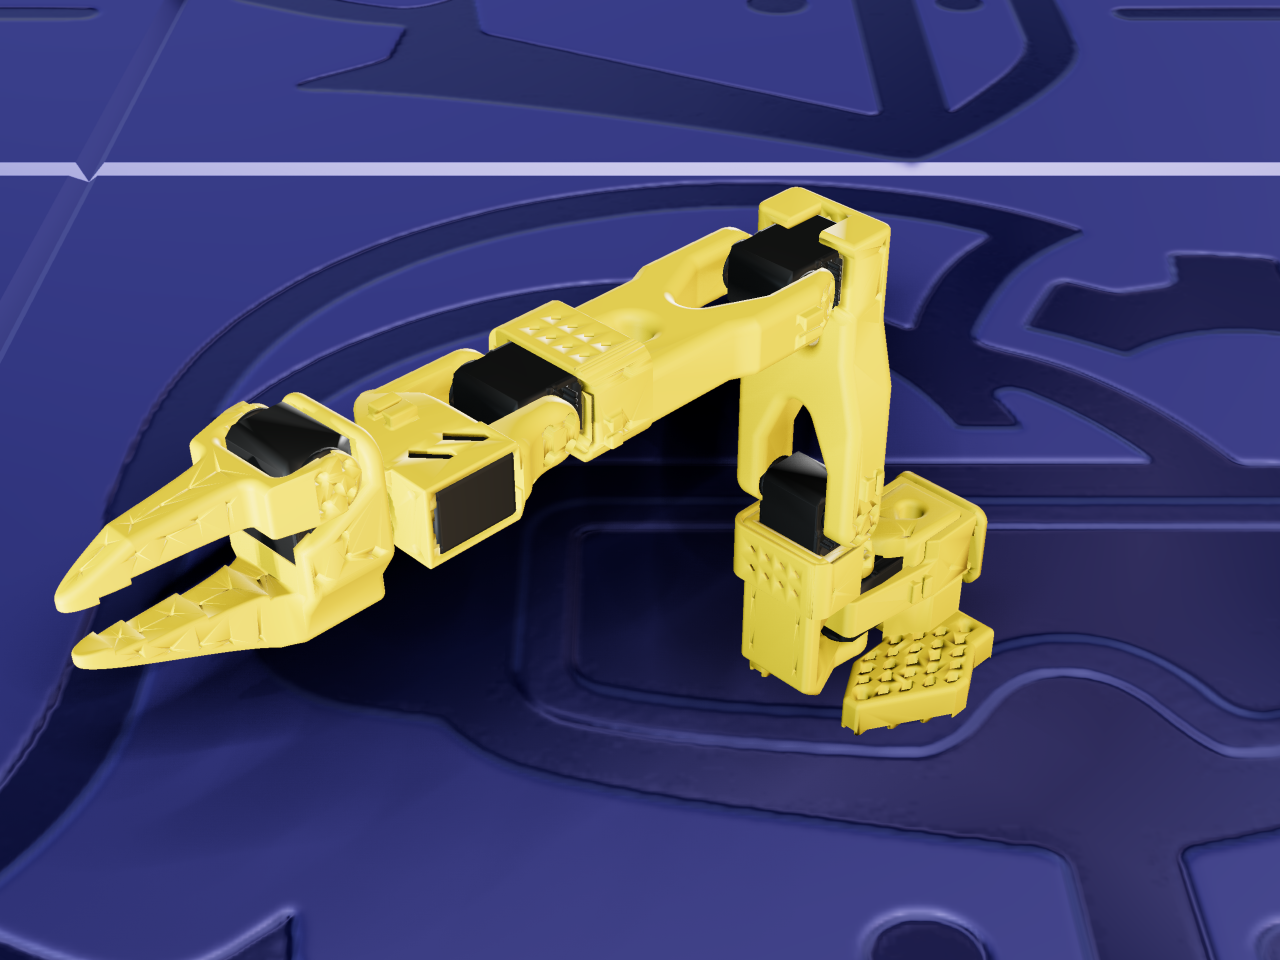
The SO-101 is a low-cost, 3D-printable robot arm from The Robot Studio, designed in collaboration with Hugging Face to work with the open-source LeRobot library. It is used to learn robotics and to record demonstrations for training a policy. This entry links directly to The Robot Studio’s own repository.
The mechanism
A serial chain of five revolute arm joints (shoulder pan, shoulder lift, elbow flex, wrist flex and wrist roll) ends in a gripper whose single moving jaw is a sixth revolute joint. That makes six actuated degrees of freedom, with no mimic joints or closed kinematic loops. It is a desktop arm, so it is fixed-base.
Follower, leader and calibration
The repository has two arms. The follower does the work. The leader has a handle and trigger in place of the gripper, and a person moves it by hand to teleoperate a follower. The follower comes in two calibrations that differ only in where each joint’s zero sits: the current one puts zero at the middle of the joint’s range, and the old one puts it at the arm fully extended. A third follower variant adds a wrist camera.
The SO-100 is the earlier generation that the SO-101 replaced. Its joint ranges and zero positions differ, so its angles are not interchangeable with the SO-101’s.
About these models
The repository generated these URDFs from its Onshape CAD design with the onshape-to-robot plugin and then edited them to use relative mesh paths and to drop the base collision meshes, which caused problems in simulation. The motor properties for the STS3215 servos are adapted from the Open Duck Mini project.
About this file — read before importing
This links directly to the Simulation folder of The Robot Studio’s
SO-ARM100 repository. ARMOR links directly to that
repository rather than re-hosting anything, so what you get is exactly what The Robot Studio
publishes, unmodified.