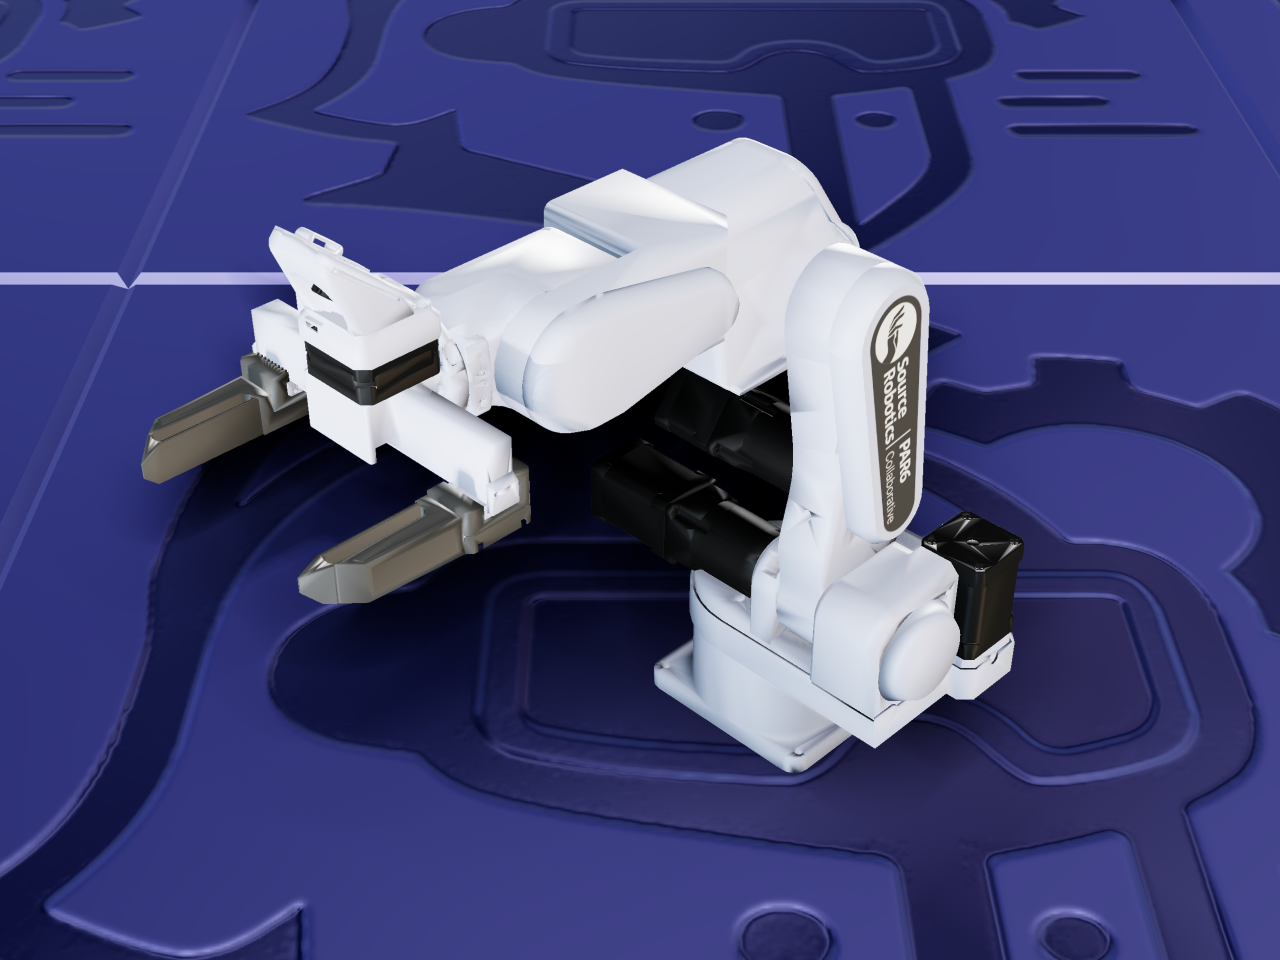
PAR6 is the collaborative robot arm from Source Robotics,
the maker of the PAROL6 desktop arm. Source Robotics publishes the model description in its
central robot_descriptions repository, alongside PAROL6 and the two grippers it mounts on
both arms.
The mechanism
Six actuated joints in series (a base rotation, shoulder, elbow, and three wrist axes) give the arm its six degrees of freedom. The first five are revolute, and the last wrist axis rolls continuously with no travel limit. The tool variants add a gripper whose second finger follows the first, so the gripper is one actuated degree of freedom and the arm with a gripper has seven. There are no closed kinematic loops.
Which end effector?
The arm comes in six configurations: the bare flange, the MSG gripper (solid or soft TPU jaws), the SSG48 gripper (solid or fin-ray jaws), and the original pneumatic gripper. The jaw options differ in geometry only; the soft TPU and fin-ray jaws are modeled as rigid. The side cover of the upper arm carries a Source Robotics badge as a texture.
How it differs from PAROL6
PAR6 and PAROL6 share their joint names, axis directions, and the 177 mm forearm, so the same joint angles drive both. They differ in the length of the last wrist housing (the flange sits 57.1 mm past the last joint on PAR6 and 50.5 mm on PAROL6) and in the meshes of their links.
About this file — read before importing
This links directly to the par6_description package of Source Robotics’ own
robot_descriptions repository. ARMOR
links directly to that repository rather than re-hosting anything, so what you get is exactly
what Source Robotics publishes, unmodified.