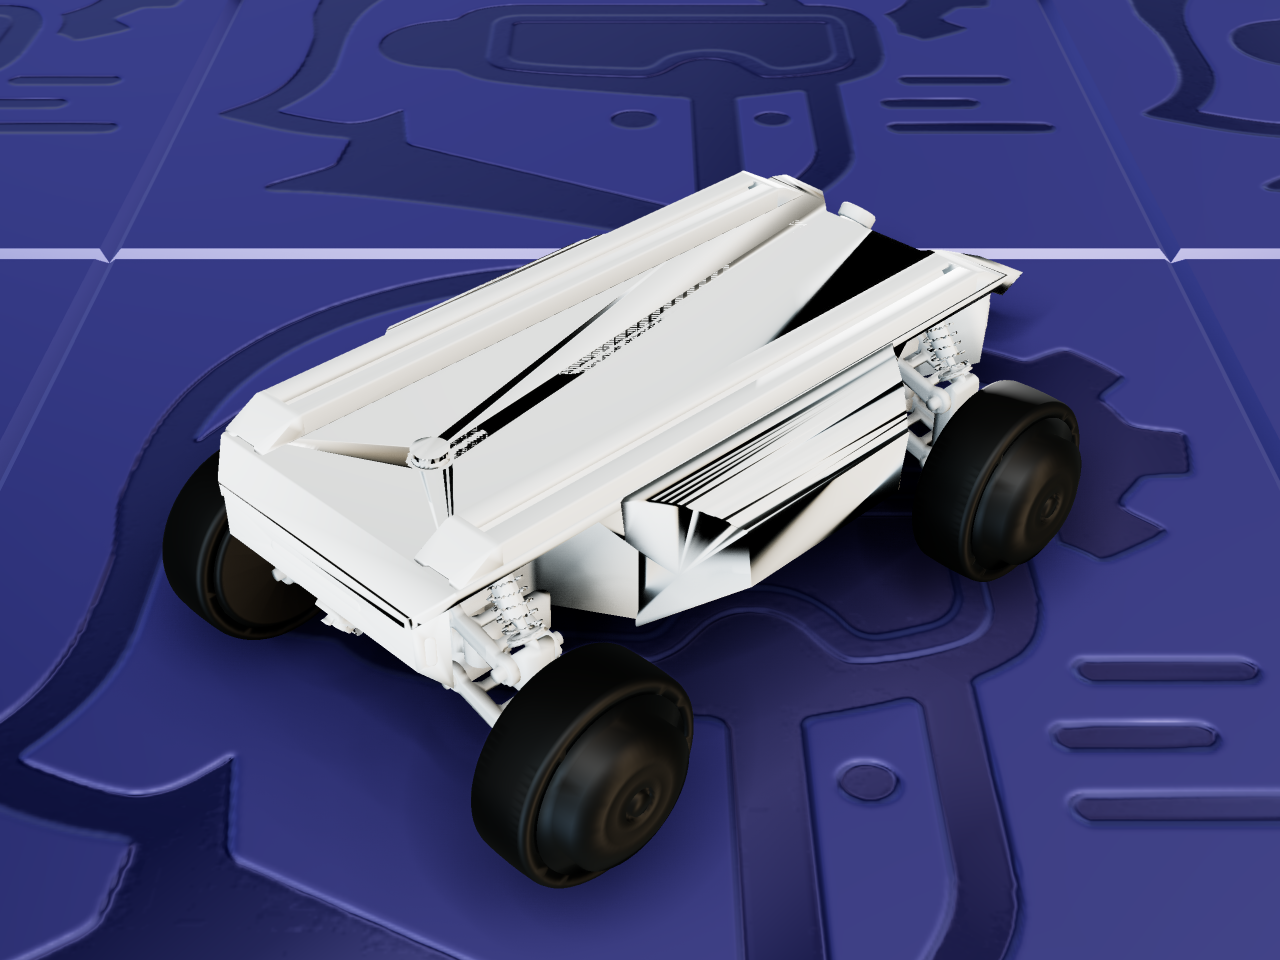
FR-mini is a wheeled mobile-robot chassis from Yuhesen, published as a Gazebo simulation model: a four-wheel base with steering on the front pair of wheels and drive on all four.
The mechanism
Six actuated joints: a steering hinge on each front wheel, plus a continuous drive-wheel joint at each of the four wheels — six degrees of freedom. No mimic joints and no closed loops; the two steering hinges are independent in the description. Collision shapes are simple primitives (a box chassis and a cylinder per wheel) and every moving link declares mass, so the chassis settles onto its four wheels when dropped in a world and the wheel joints turn freely. About 0.54 × 0.40 × 0.21 m and 20 kg. (The repository also publishes a visual-only FR-mega shell; it has no joints, collision or mass and isn’t part of this entry.)
About this file — read before importing
This links directly to
YHS-ROBOT-Description, Yuhesen’s own
repository. ARMOR links directly to that repository rather than re-hosting anything, so what
you get is exactly what Yuhesen publishes, unmodified. The repository has no license — no
LICENSE file, and every package.xml says TODO — so under default copyright nothing grants
permission to reuse these files. Read that before building on them. The model is Yuhesen’s own
Gazebo simulation package: its Gazebo plugin blocks and ros_control transmissions are
Gazebo and ROS configuration, not something ARMOR runs.