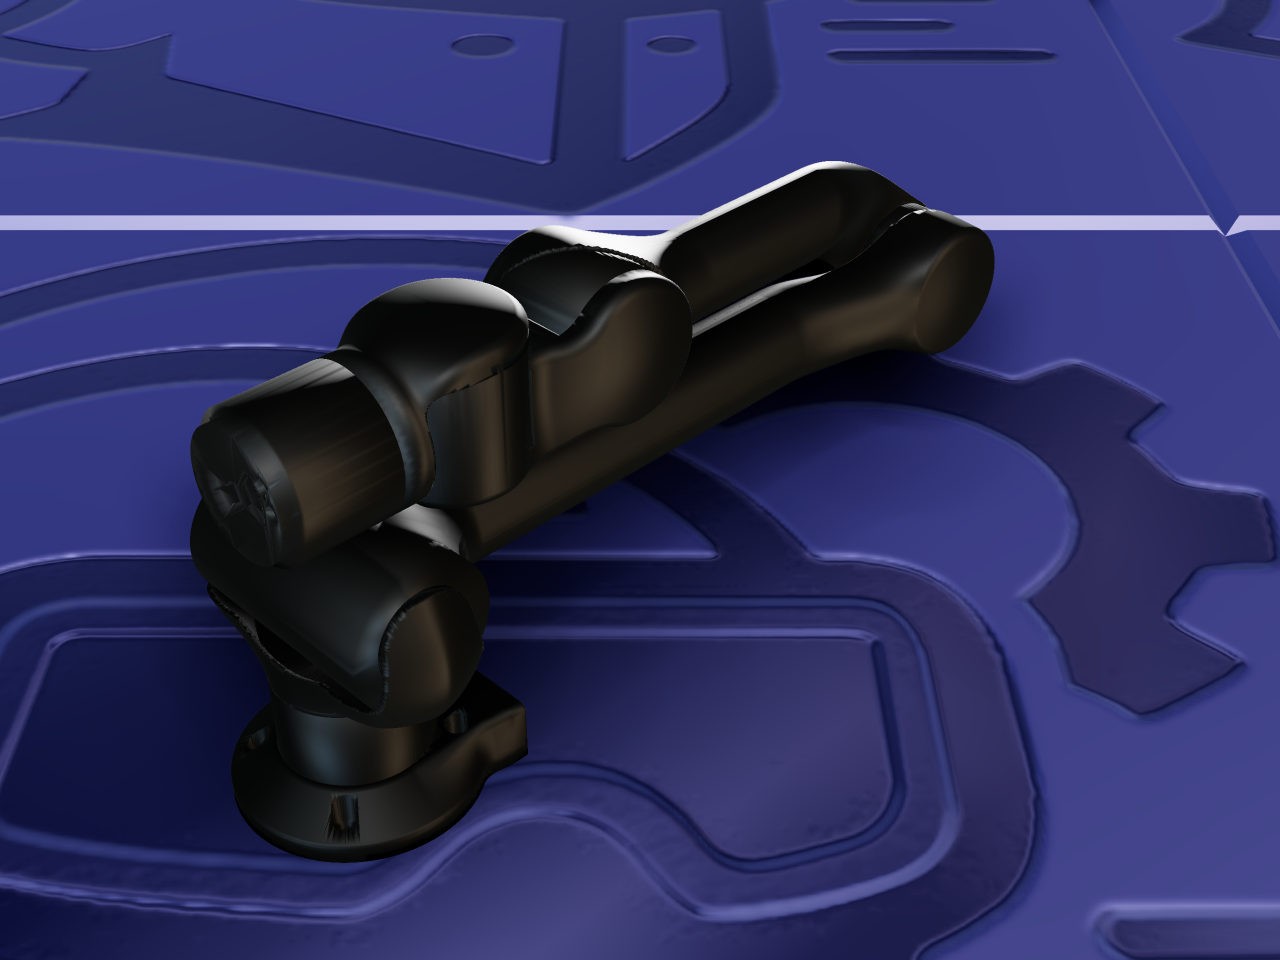
Z1 is Unitree’s own lightweight 6-axis robotic arm — a compact research and education platform, separate from the company’s better-known legged quadrupeds and humanoids.
The mechanism
Six revolute joints in series form a textbook 6-axis arm — no mimic joints, no closed loops, every movable joint an independent actuator.
About this file — read before importing
This links directly to
unitree_ros’s z1_description package,
Unitree’s own repository. ARMOR links directly to that repository rather than re-hosting
anything, so what you get is exactly what Unitree publishes, unmodified.