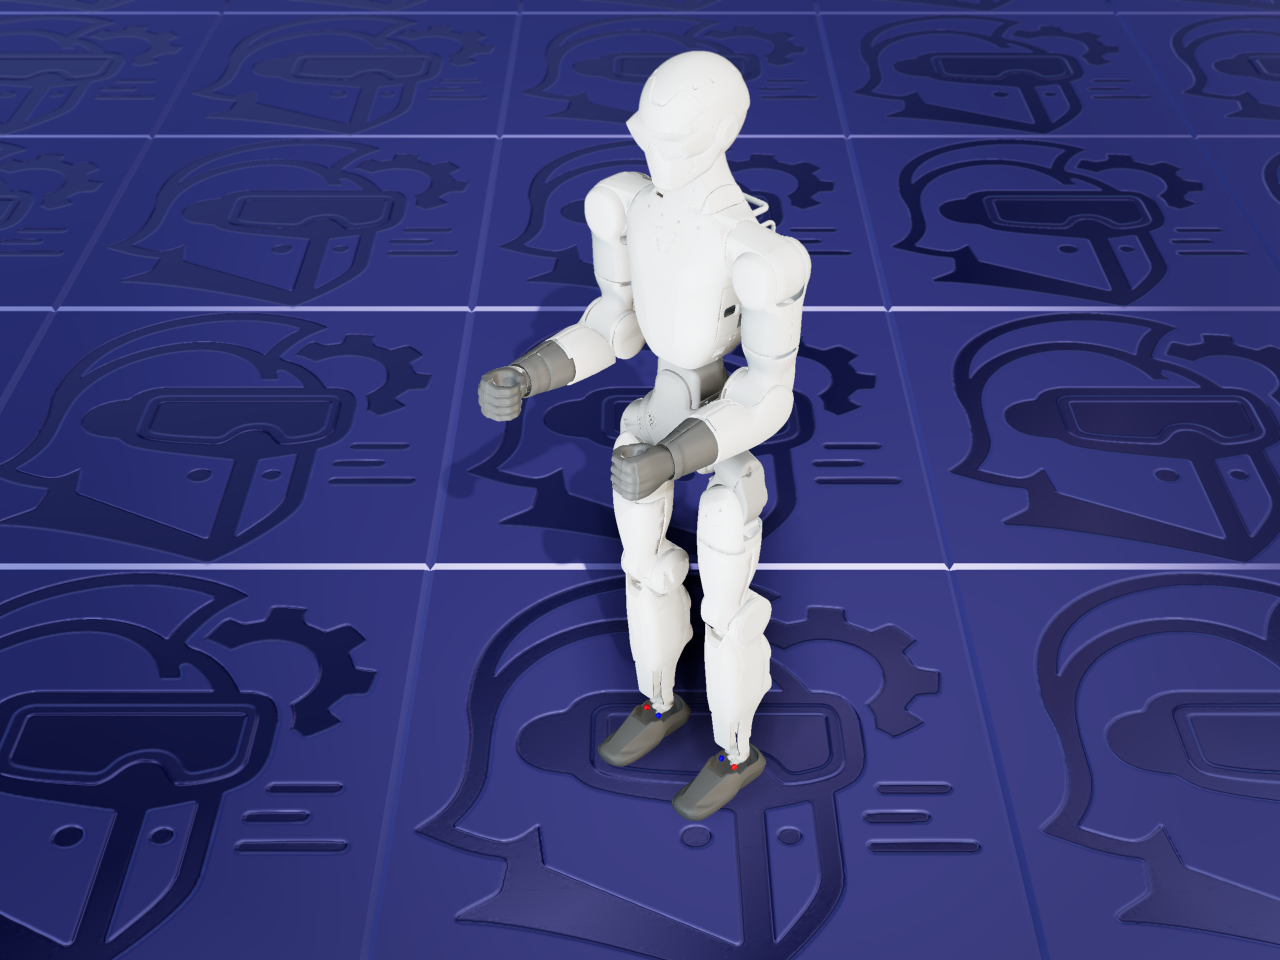
R1 is Unitree’s compact bipedal humanoid line — smaller and more affordable than the full-size H1/H1-2/G1 platforms, offered in a full configuration and a lighter R1 Air variant.
The mechanism
Each leg carries six actuated joints (hip pitch, roll, and yaw; knee; ankle pitch and roll) for twelve leg DOF. The full R1 platform adds a two-axis waist (roll, yaw), a two-axis head (yaw, pitch), and five actuated joints per arm (shoulder pitch, roll, and yaw; elbow; wrist roll) for ten arm DOF — 12 + 2 + 2 + 10 = twenty-six actuated degrees of freedom in total. R1 Air drops the waist and head joints entirely and simplifies each arm to four joints (shoulder pitch, roll, and yaw; elbow) — 12 + 8 = twenty actuated degrees of freedom, a lighter, lower-cost configuration of the same leg mechanism.
No mimic joints or closed kinematic loops in either configuration.
Choosing a variant
R1 for the full-featured platform (waist rotation, head, wrist rotation). R1 Air for the simplified, lighter-duty configuration.
About this file — read before importing
These are real, literal URDFs, not xacro templates. This gallery entry links directly to the official unitree_ros repository, unmodified, configured per variant. ARMOR downloads and imports each one directly.