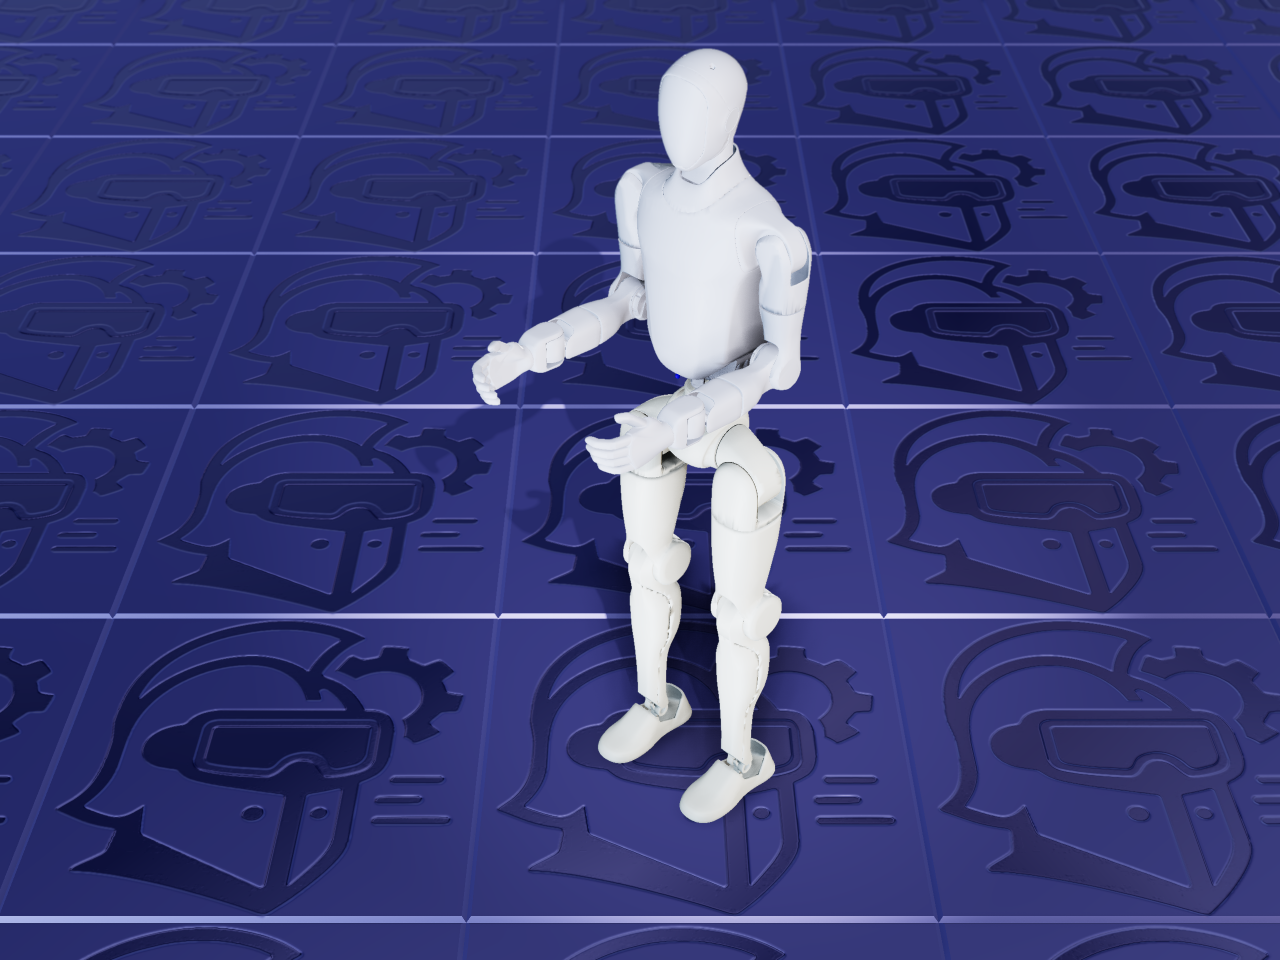
H2-X rendered in ARMOR
Humanoid humanoid bipedal manipulator 31 DOF

H2-X

by Unitree Robotics

Unitree's H2-X humanoid — a full-size biped with the H2's thirty-one-joint layout: six joints per leg, a three-axis waist, a two-axis head and seven joints per arm.

Add to ARMOR

37 files 9.9 MB download

Opens in the ARMOR app on iPhone, iPad, or Mac. Don’t have it yet? Get ARMOR.

Model

50Links
31Joints
31Actuated DOF
36Meshes

Mesh formats: STL

H2-X is a full-size humanoid from Unitree, listed in its unitree_ros repository beside the H2. This entry links directly to Unitree’s own description.

The mechanism

Each leg carries six actuated joints (hip pitch, roll and yaw; knee; ankle pitch and roll) for twelve. The waist adds three (yaw, roll and pitch), the head two (pitch and yaw), and each arm seven (shoulder pitch, roll and yaw; elbow; wrist roll, pitch and yaw) for fourteen: 12 + 3 + 2 + 14 = thirty-one actuated degrees of freedom, all revolute, with no mimic joints or closed kinematic loops. It has the same joint layout as Unitree’s H2.

About this file — read before importing

This links directly to unitree_ros’s h2x_description package, Unitree’s own repository. ARMOR links directly to that repository rather than re-hosting anything, so what you get is exactly what Unitree publishes, unmodified.

License & attribution

Source code
BSD-3-Clause
Model & mesh files
BSD-3-Clause
Attribution
h2x_description (unitree_ros) — Copyright 2016-2022 HangZhou YuShu TECHNOLOGY CO.,LTD. ("Unitree Robotics") — BSD 3-Clause License, per the repository's own LICENSE file.

ARMOR does not host or redistribute this model. Choosing “Open in ARMOR” downloads the files directly from Unitree Robotics’s own repository, unmodified. Your use of the model is governed by the license above.

Read the full license →
ARMOR is an independent tool published by DCDC LLC. It is not affiliated with, sponsored by, or endorsed by Unitree Robotics (Hangzhou Yushu Technology Co., Ltd.). "Unitree" and "H2-X" are used here only to identify the robot this file describes. This model is downloaded directly from Unitree's own repository under the BSD 3-Clause License, which you accept by downloading.

Looking for a different robot? Find more URDF sources or browse the rest of the gallery.