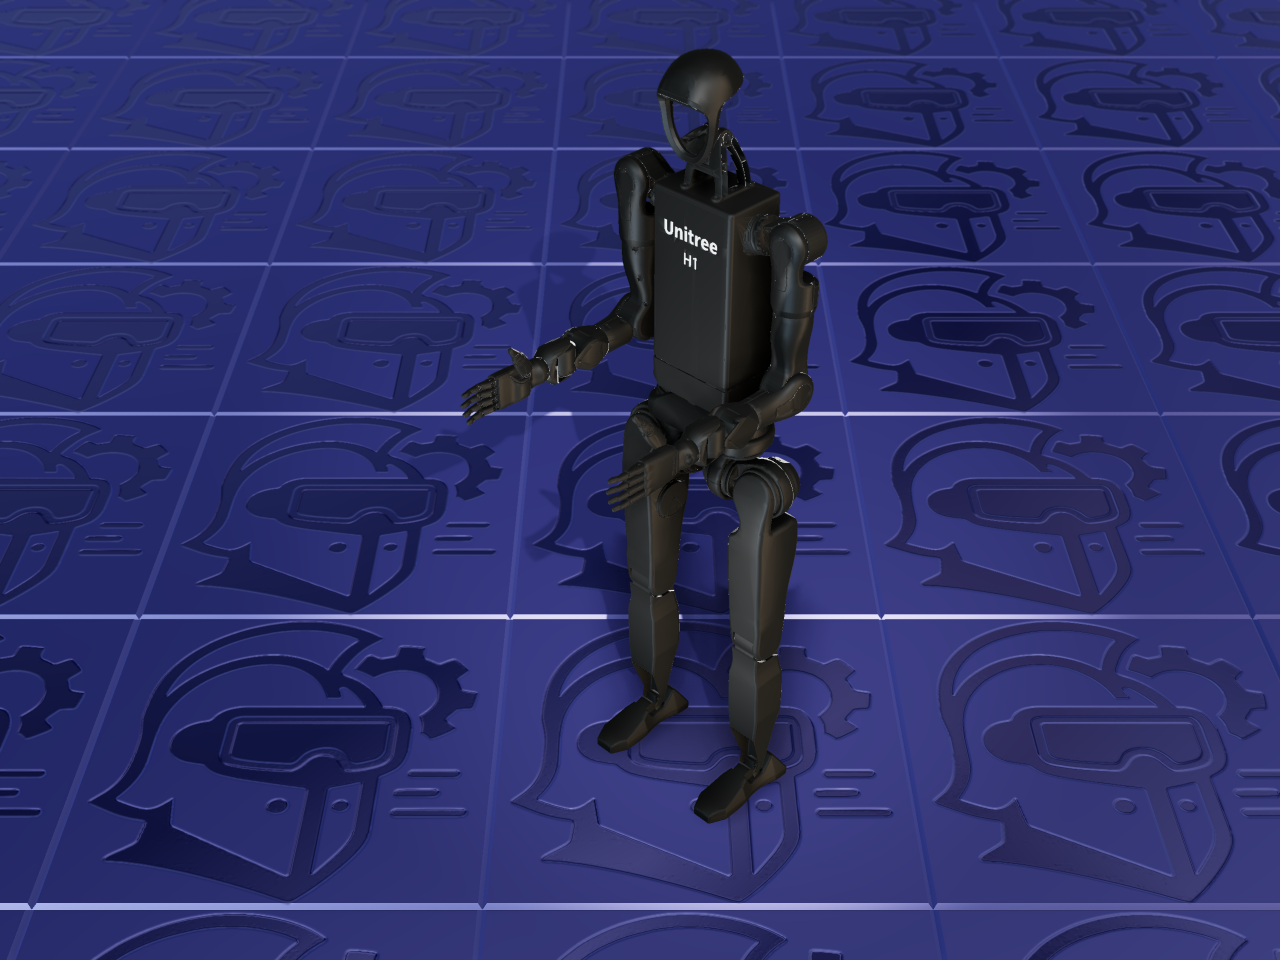
H1-2 is Unitree’s upgraded full-size humanoid — a genuinely distinct successor to H1, not a hardware revision of it: a three-axis waist (H1 has one), an optional built-in dexterous hand at each wrist, and roughly double the total actuated joints of H1’s base platform.
The mechanism
Each leg carries six actuated joints (hip pitch, roll, and yaw; knee; ankle pitch and roll) for twelve leg DOF. The waist adds three actuated joints (yaw, roll, pitch) — a full 3-axis waist, unlike H1’s single yaw joint — and each arm carries six actuated joints (shoulder pitch, roll, and yaw; elbow; wrist pitch and yaw) for twelve arm DOF — 12 + 3 + 12 = twenty-seven actuated degrees of freedom on the handless platform, all independently driven, no mimic joints or closed kinematic loops.
The optional dexterous hand adds a thumb-and-index hand at each wrist — the thumb’s
three joints and the index finger’s proximal joint are independently actuated, while the
index finger’s intermediate joint mechanically follows (a mimic joint in the URDF) —
six real motors per hand, not the naive twelve-joint count. With both hands attached, total
actuated DOF rises to 39.
About this file — read before importing
This links directly to
unitree_ros’s h1_2_description package,
Unitree’s own repository. ARMOR links directly to that repository rather than re-hosting
anything, so what you get is exactly what Unitree publishes, unmodified. The repository
also ships an alternate h1_2_with_FTP_hand.urdf (a different hand model, same 39 real
DOF, many more fixed sub-links for visual detail) — not added here as a third variant,
same reasoning as excluding G1’s third-party Inspire-hand and BrainCo-hand variants.