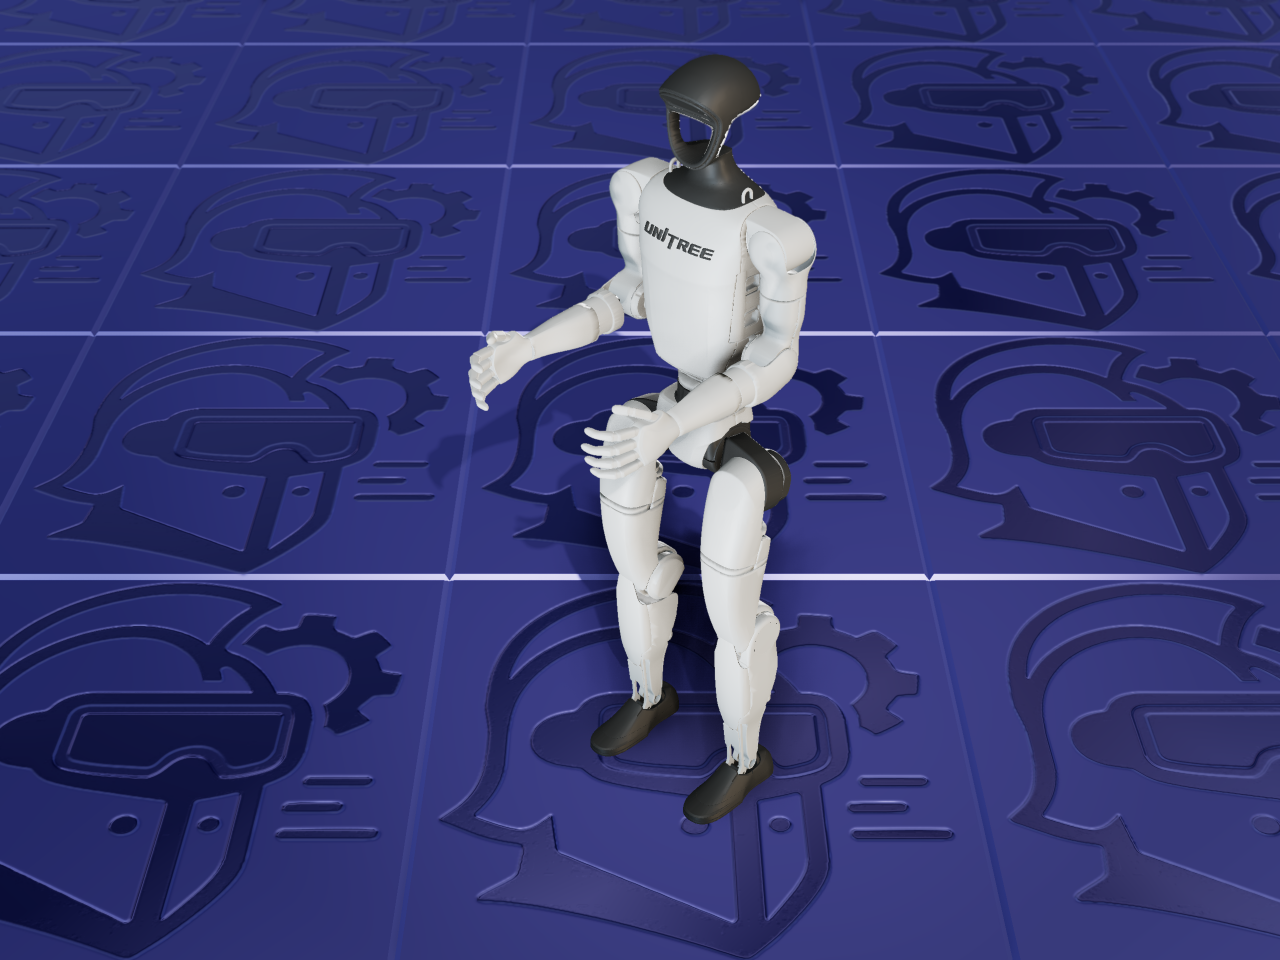
G1 is Unitree’s compact, general-purpose humanoid — about 1.3 m tall, aimed squarely at research and product development rather than the high-speed dynamics H1 is built for. It’s become one of the most widely deployed humanoid platforms in current locomotion and manipulation research.
The mechanism
Each leg carries six actuated joints (hip pitch, roll, and yaw; knee; ankle pitch and roll) for twelve leg DOF. The base platform holds waist yaw fixed and adds five actuated joints per arm (shoulder pitch, roll, and yaw; elbow; wrist roll) for twenty-three actuated degrees of freedom total. The 29-DOF platform frees the waist for full pitch/roll/ yaw rotation and adds two more wrist joints per arm (pitch and yaw), all independently driven — no mimic joints or closed kinematic loops anywhere in the base mechanism.
The optional dexterous hand adds a 3-fingered hand at each wrist, with every finger joint independently actuated (unlike H1’s hand, no joints here are mechanically coupled) — seven real motors per hand. With both hands attached, total actuated DOF rises to 43.
Every URDF in this description also declares one floating joint anchoring the pelvis to
a world frame — a physics-engine bookkeeping joint representing the robot’s free-floating
base, not a real actuator, and excluded from every DOF count above.
About this file — read before importing
This links directly to
unitree_ros’s g1_description package,
Unitree’s own repository. ARMOR links directly to that repository rather than re-hosting
anything, so what you get is exactly what Unitree publishes, unmodified. The repository
actually ships many more G1 configurations than the three here (locked-waist variants,
firmware/gear-ratio revisions, a third-party Inspire-brand hand) — these three cover the
mechanically distinct base cases; see the repository’s own README for the full matrix if
you need one of the others.