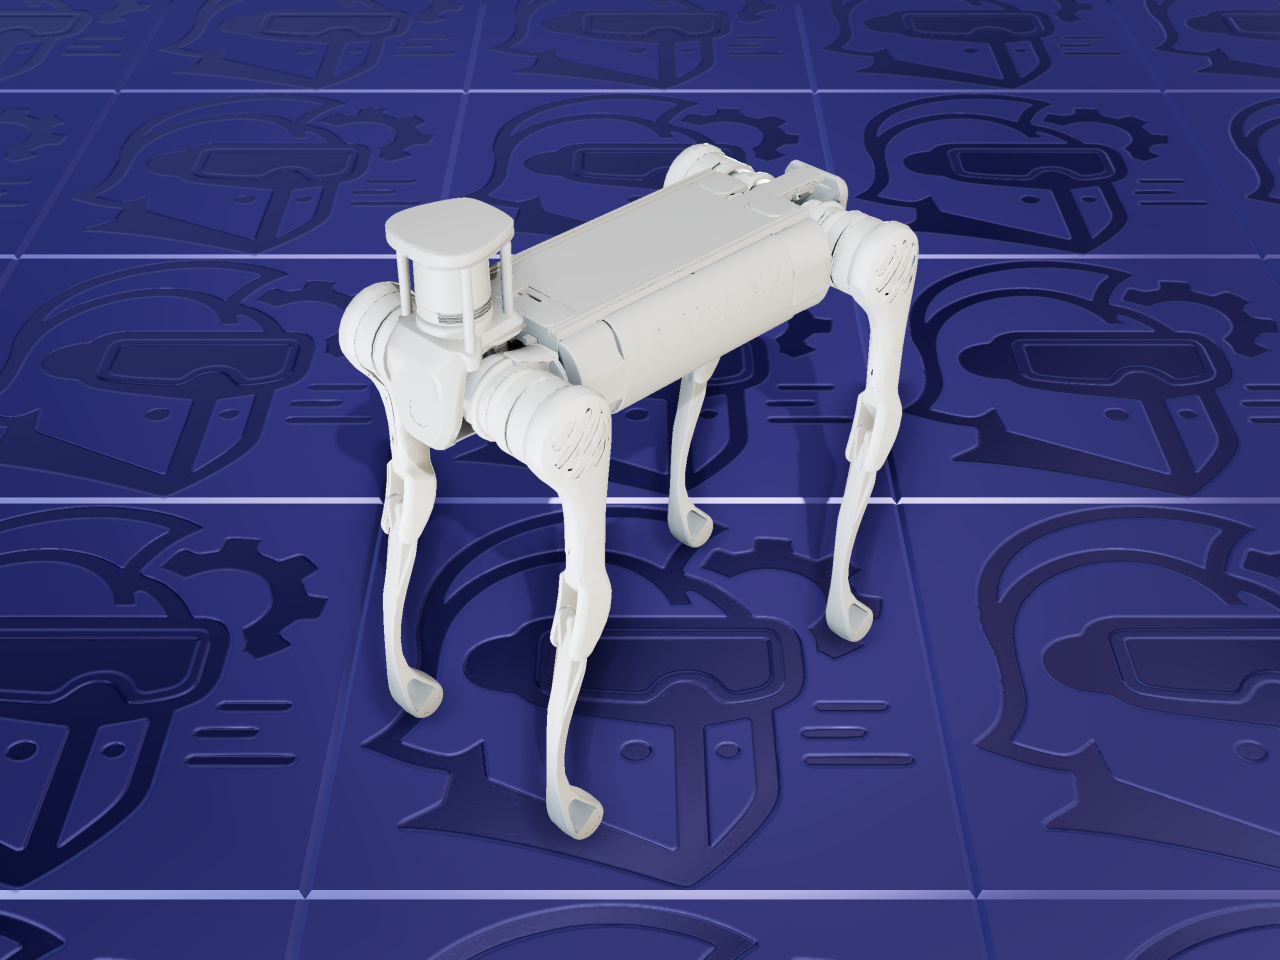
B2 is Unitree’s large industrial quadruped — bigger and stronger than Go2, built for heavier sensor/manipulator payloads and longer-range field deployment (inspection, logistics, security) rather than compact agility.
The mechanism
Each of the four legs carries three actuated joints — a hip abduction joint, a hip flexion joint, and a knee — giving twelve degrees of freedom in total. No mimic joints or closed kinematic loops anywhere in the description, so this is a direct, unadjusted read of the URDF’s actuated joints — the same leg mechanism as Go2, scaled up.
About this file — read before importing
This links directly to
unitree_ros’s b2_description package,
Unitree’s own repository. ARMOR links directly to that repository rather than re-hosting
anything, so what you get is exactly what Unitree publishes, unmodified.