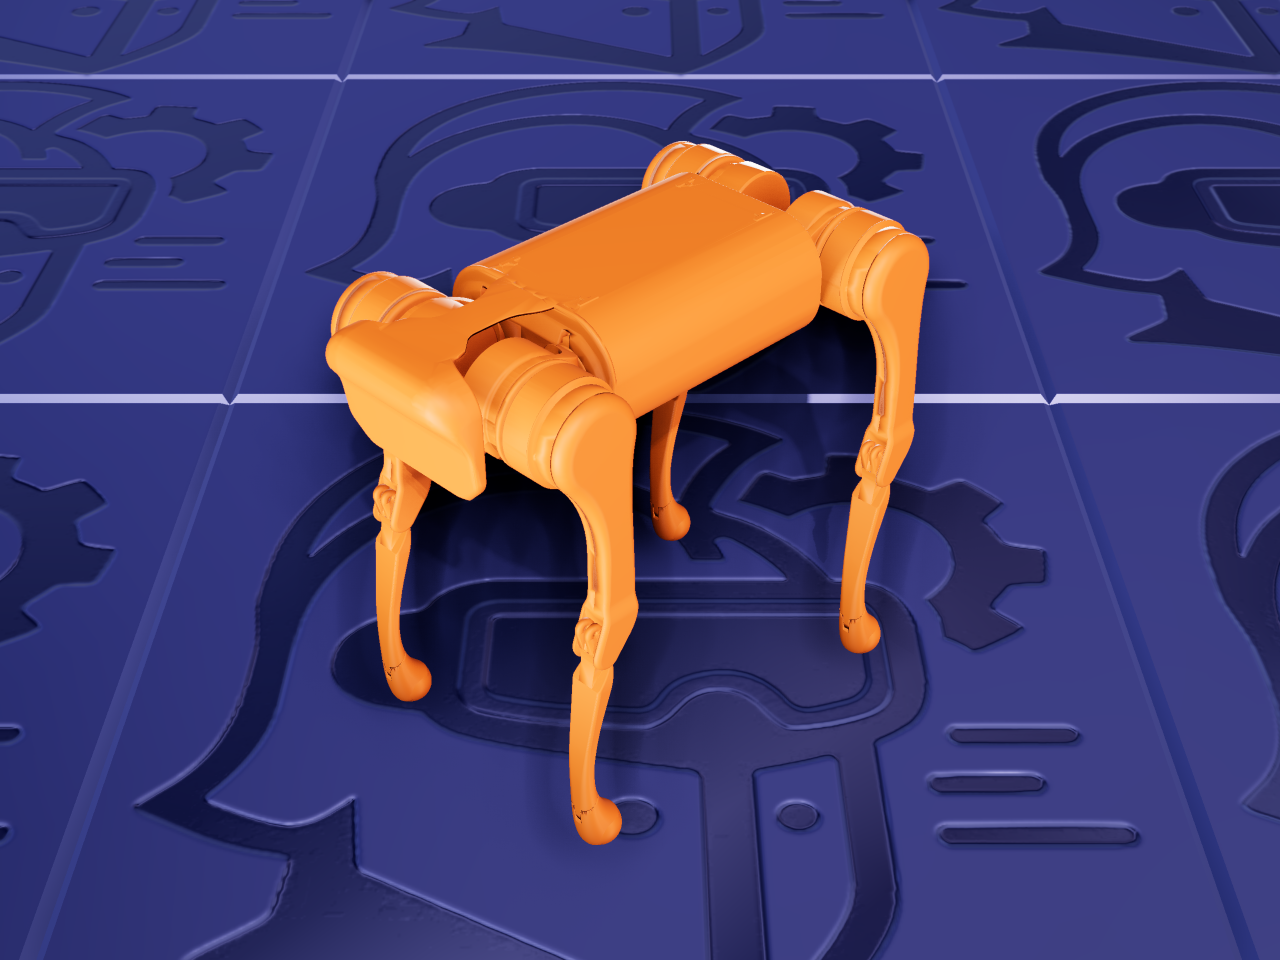
A1 rendered in ARMOR
Mobile & Legged quadruped legged 12 DOF

A1

by Unitree Robotics

Unitree's original compact research quadruped — a small, agile robot dog still widely used as a reference platform in legged-locomotion academia.

Add to ARMOR

7 files 8.7 MB download

Opens in the ARMOR app on iPhone, iPad, or Mac. Don’t have it yet? Get ARMOR.

Model

23Links
12Joints
12Actuated DOF
5Meshes

Mesh formats: DAE

A1 is Unitree’s original compact research quadruped — small and agile enough to carry by hand, and still a common reference platform in legged-locomotion academia even as Unitree’s own lineup has moved on to newer models.

The mechanism

Each of the four legs carries three actuated joints — a hip abduction joint, a hip flexion joint, and a knee — giving twelve degrees of freedom in total. No mimic joints or closed kinematic loops anywhere in the description, so this is a direct, unadjusted read of the URDF’s actuated joints.

About this file — read before importing

This links directly to unitree_ros’s a1_description package, Unitree’s own repository. ARMOR links directly to that repository rather than re-hosting anything, so what you get is exactly what Unitree publishes, unmodified.

License & attribution

Source code
BSD-3-Clause
Model & mesh files
BSD-3-Clause
Attribution
a1_description (unitree_ros) — Copyright 2016-2022 HangZhou YuShu TECHNOLOGY CO.,LTD. ("Unitree Robotics") — BSD 3-Clause License, per the repository's own LICENSE file.

ARMOR does not host or redistribute this model. Choosing “Open in ARMOR” downloads the files directly from Unitree Robotics’s own repository, unmodified. Your use of the model is governed by the license above.

Read the full license →
ARMOR is an independent tool published by DCDC LLC. It is not affiliated with, sponsored by, or endorsed by Unitree Robotics (Hangzhou Yushu Technology Co., Ltd.). "Unitree" and "A1" are used here only to identify the robot this file describes. This model is downloaded directly from Unitree's own repository under the BSD 3-Clause License, which you accept by downloading.

Looking for a different robot? Find more URDF sources or browse the rest of the gallery.