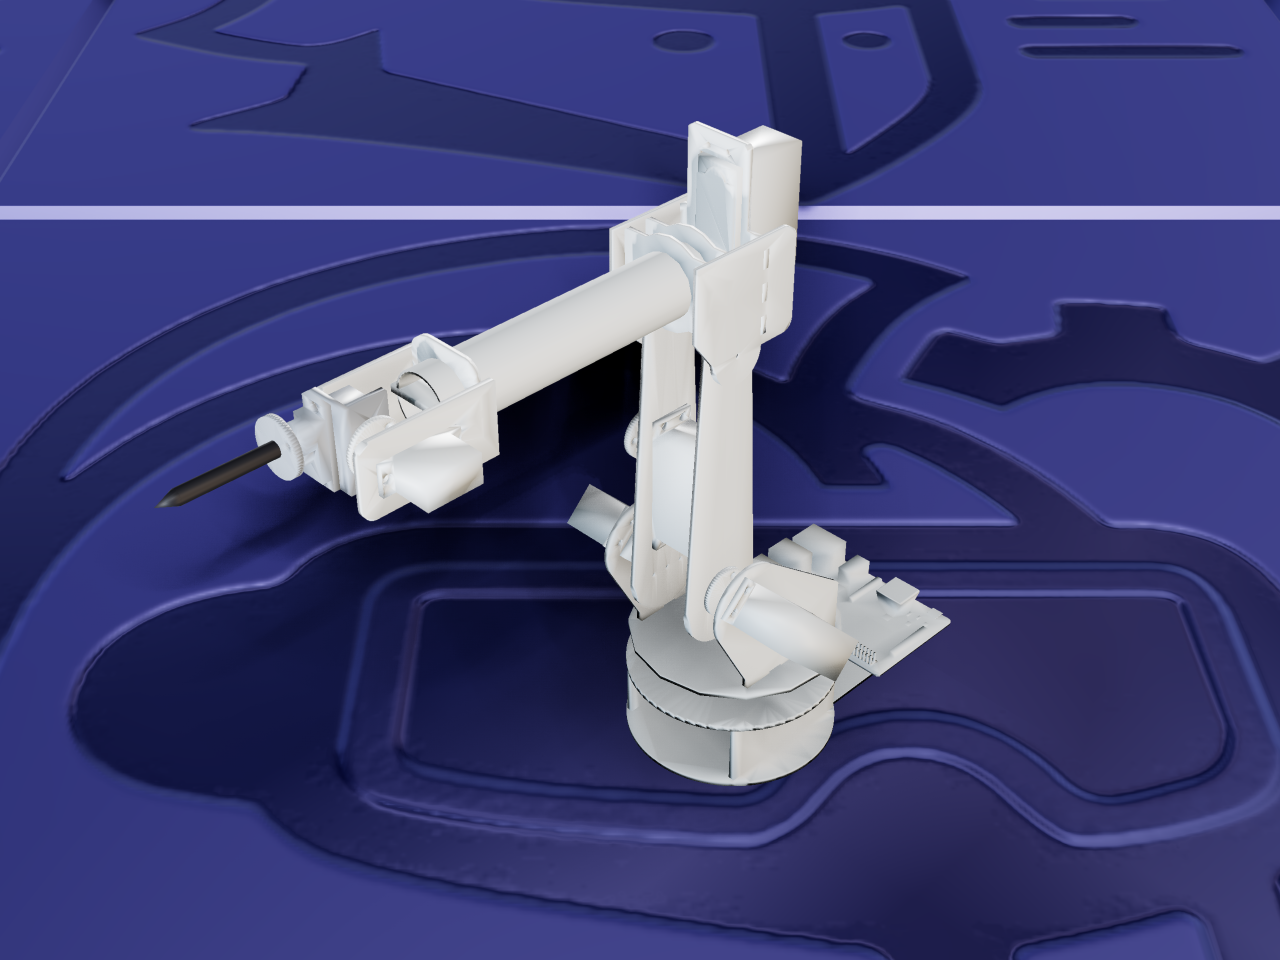
TATTOTRONIX is a 5 degree-of-freedom desktop manipulator built to hold a tattoo pen — but nothing below the tool flange knows that. The arm, its controllers, and its simulation are a general-purpose small manipulator; the tattoo machine is a separate tool bolted to the flange, swappable by a launch argument rather than an edit. At its zero pose the wrist axis stands 242 mm above the bench and the highest point of the arm is 292 mm; the tool flange itself reaches 214 mm forward.
The mechanism
Five revolute joints in series — a base yaw, shoulder pitch, elbow pitch, wrist roll, and wrist pitch — give the arm its five degrees of freedom, all independently actuated with no mimic joints or accessory mechanisms. The mechanical design is the project’s own CAD, exported as printed-shell meshes; mass and inertia for every link come from integrating those same meshes rather than an estimate, plus the real hobby servos (five MG996R, two SG90) mounted in each one.
About these files — read before importing
This links directly to MrDavidAlv/TATTOTRONIX,
the author’s own repository, on its humble branch (the active ROS 2 Humble port — the
project started life as ROS 1 training material and has since been substantially rebuilt).
It’s a genuinely documented project: every figure in its own kinematics, dynamics, and
control write-up is regenerated from the same URDF this entry loads, checked against live
TF and asserted in notebooks that run on every build. ARMOR links directly to that
repository rather than re-hosting anything, so what you get is exactly what the author
publishes, unmodified.