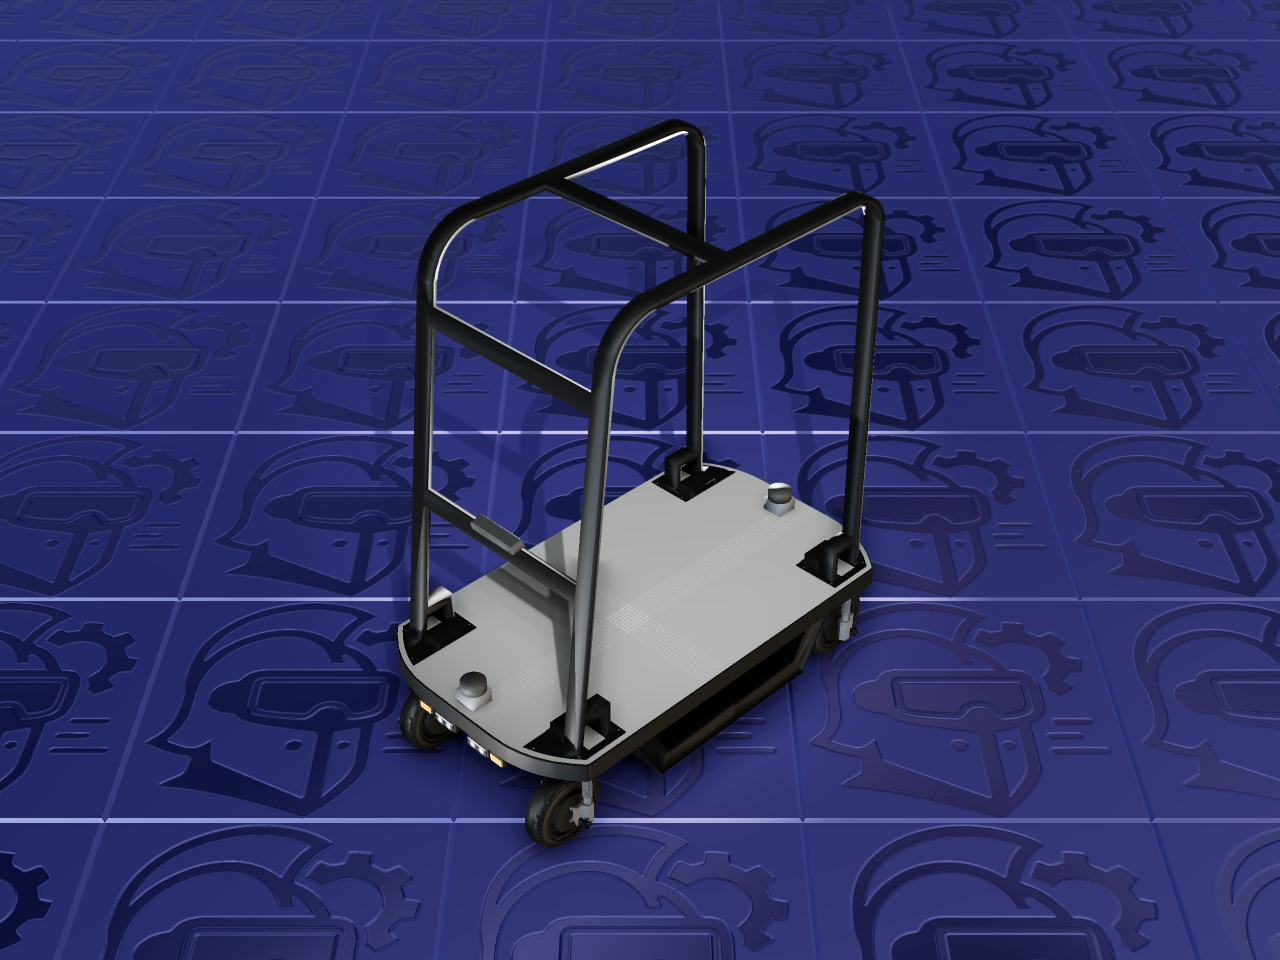
Tadeo eCar is a four-wheel-drive, four-wheel-steering electric platform for indoor and yard material transport, designed by Mario David Alvarez Vallejo and published as an open-source ROS 2 workspace with SLAM, visual SLAM, and Nav2 navigation. Because every wheel both drives and steers, it can follow a car-like path, spin on the spot, or move sideways without changing heading.
The mechanism
Each of the four wheel modules has a steering joint (revolute, about ±135° from straight ahead) and a drive joint (continuous), for eight actuated degrees of freedom. There are no mimic joints and no closed kinematic loops. The sensors, a ZED 2i stereo camera and a LiDAR at each end, sit on fixed joints and add frames, not motion.
Mass data — read before simulating
The author keeps this description as the robot’s shape only. It has visual and collision geometry but no mass or inertia, because the repository’s Gazebo model carries the physics. In ARMOR the robot loads, shows, and poses normally, but to simulate it you first need mass data, which ARMOR can estimate from the geometry (see Estimate All Masses in the Robot editor).
About this file — read before importing
The author’s description is xacro, not plain URDF, because the wheel radius and other measurements appear in many places and are defined once. This gallery entry links directly to the author’s own tadeo-eCar-ws repository, unmodified, and ARMOR expands the macros itself after downloading, so Open in ARMOR gives you a working robot.