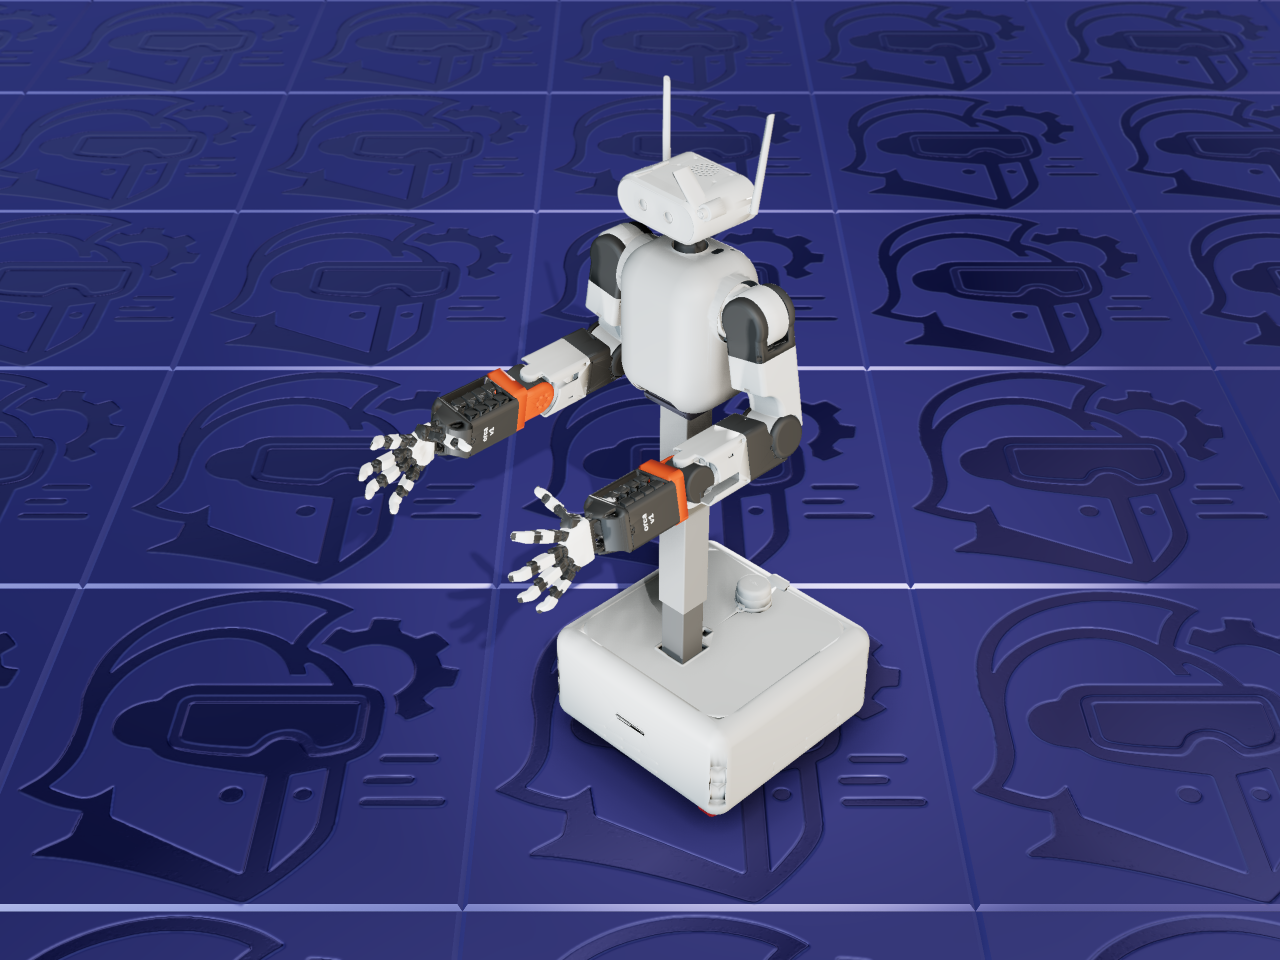
MABEL rendered in ARMOR
Mobile & Legged mobile manipulator bimanual wheeled humanoid-like open source 56 DOF

MABEL

by NYU and University of Toronto

MABEL — an open-source mobile bimanual robot from NYU and the University of Toronto: a three-module swerve base, a vertical lift, a pitching torso, an active head, two 7-DOF arms and two 17-DOF anthropomorphic hands, built for teleoperation and learning.

Add to ARMOR

154 files 64.2 MB download

Opens in the ARMOR app on iPhone, iPad, or Mac. Don’t have it yet? Get ARMOR.

Model

85Links
60Joints
56Actuated DOF
153Meshes

Mesh formats: STL

MABEL is an open-source mobile bimanual robot from a team at NYU and the University of Toronto, released at CoRL 2026. It is built for teleoperation and learning: a person drives it whole-body from a single Apple Vision Pro, without hand-held controllers, to collect demonstrations. This entry links directly to the project’s own repository.

The mechanism

A three-module swerve base carries a two-stage vertical lift, a pitching torso, and a three-axis head with stereo cameras. Two seven-axis arms (derived from Enactic’s OpenArm) end in two seventeen-joint anthropomorphic hands (derived from the ORCA Hand). That is 56 degrees of freedom by the authors’ count. The URDF itself has 60 movable joints, because it lists each swerve module’s steering and drive joints and each lift stage separately. There are no mimic joints or closed kinematic loops.

About this file — read before importing

This is a large model: it uses 153 STL meshes, most of them in the two hands, so the first import takes longer than a typical arm. The robot description is generated from the project’s MuJoCo model, and the authors note that the hand joints use a non-zero reference in MuJoCo, so an angle of zero in the URDF is the assembled pose.

About the license

The project uses several open licenses: Apache-2.0 for software, CERN-OHL-S-2.0 for the hardware designs (the arms’ CAD builds on OpenArm), and CC BY 4.0 for documentation and the hands. The robot description’s package leaves its own license field unfilled, so the hardware license is treated as the one covering the meshes. ARMOR links to the project’s repository and hosts none of it.

This links directly to the mabel_description package of the project’s open_mabel repository, so what you get is exactly what the authors publish, unmodified.

License & attribution

Source code
Apache-2.0
Model & mesh files
CERN-OHL-S-2.0
Attribution
open_mabel — the MABEL authors (NYU and University of Toronto). Per the repository's README: software Apache-2.0, hardware design files CERN-OHL-S-2.0, documentation and media CC BY 4.0. The robot description's meshes come from the hardware CAD, which builds on Enactic's OpenArm (CERN-OHL-S-2.0) and ORCA Dexterity's ORCA Hand (CC BY 4.0); the repository's THIRD_PARTY_NOTICES.md lists each. The mabel_description package.xml leaves its own license field as "TODO", so the hardware license is taken as the one covering the meshes.

ARMOR does not host or redistribute this model. Choosing “Open in ARMOR” downloads the files directly from NYU and University of Toronto’s own repository, unmodified. Your use of the model is governed by the license above.

Read the full license →
ARMOR is an independent tool published by DCDC LLC. It is not affiliated with, sponsored by, or endorsed by the MABEL authors, NYU, the University of Toronto, Enactic or ORCA Dexterity. "MABEL", "OpenArm" and "ORCA" are used here only to identify the robot this file describes. This model is downloaded directly from the project's own repository under its published licenses, which you accept by downloading.

Looking for a different robot? Find more URDF sources or browse the rest of the gallery.