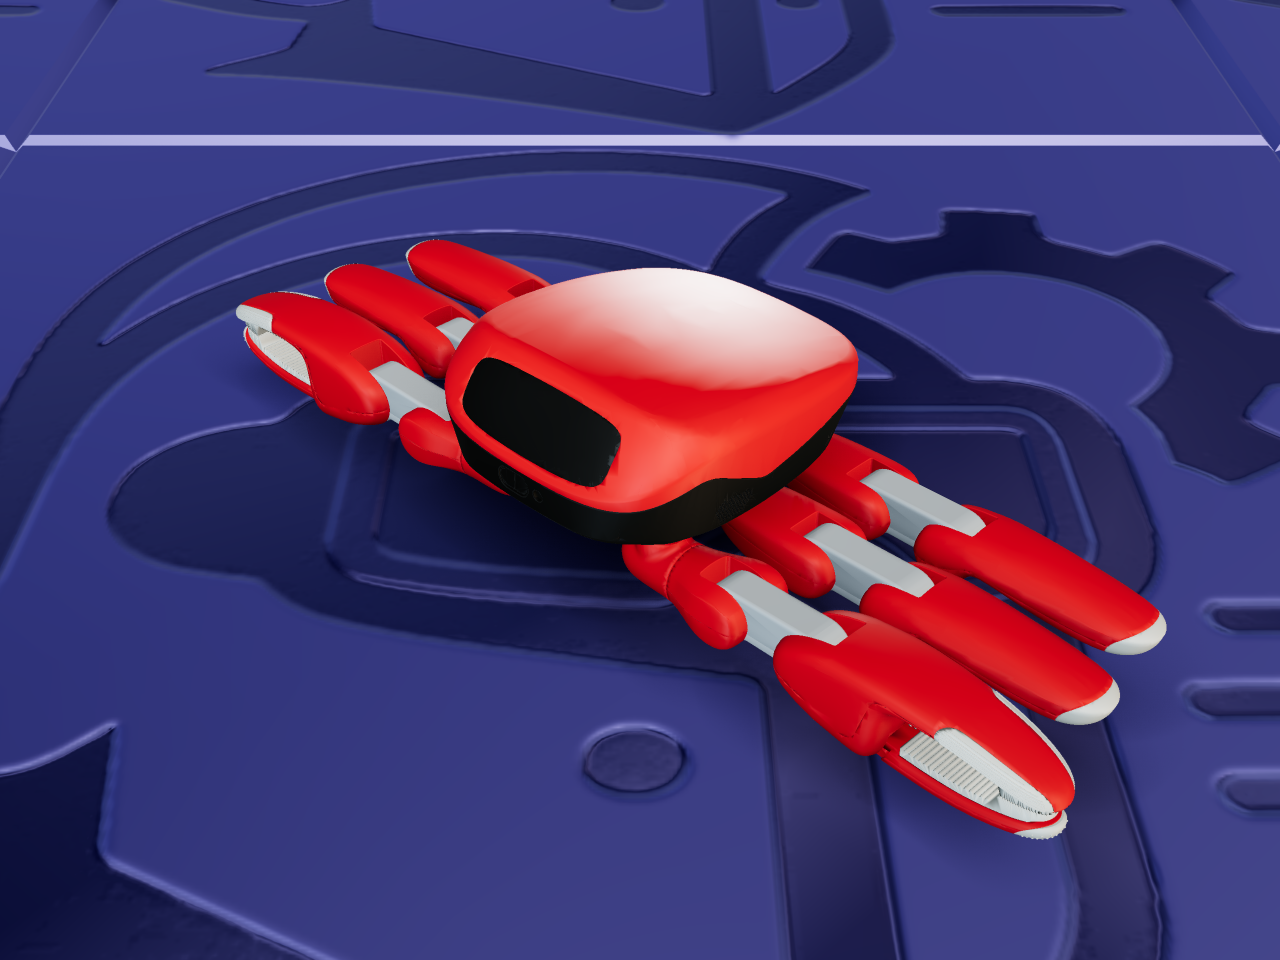
Jumper rendered in ARMOR
Mobile & Legged quadruped legged manipulator gripper 22 DOF companion robot

Jumper

by KingKong Robotics

A 22-DOF, six-limbed companion robot — four walking legs plus two gripper-equipped arms — built for jumping, walking, dancing, and simple grasping, from the KingKong Robotics open-source training stack.

Add to ARMOR

42 files 20.6 MB download

Opens in the ARMOR app on iPhone, iPad, or Mac. Don’t have it yet? Get ARMOR.

Model

41Links
22Joints
22Actuated DOF
41Meshes

Mesh formats: STL

Jumper is a 22-DOF, six-limbed companion robot from KingKong Robotics: four walking legs for quadrupedal locomotion and two gripper-equipped arms for simple grasping and expressive gesture, all in a 400 × 400 × 200 mm, 1.8 kg body. It ships with an open-source MuJoCo/Isaac Lab training stack the maintainer uses for its own walking, jumping, dancing, and gesture behaviors, built on mjlab and rsl_rl.

The mechanism

Four legs (left/right × middle/rear) each carry 3 actuated joints — hip yaw, hip flexion, and knee flexion — for walking and jumping. Two front limbs (left/right) are 5-DOF arms instead of legs: shoulder yaw, shoulder pitch, elbow, wrist, and a single-DOF gripper finger, each ending in a two-pad palm for grasping. All 22 joints are independently actuated — no mimic joints, no shared or coupled motion.

About these files — read before importing

This links directly to KingKongRobotics/jumper, the manufacturer’s own repository. Every link’s mass and inertia is measured CAD data (the project’s own conventions document records the exact reference values and explicitly prohibits silently recomputing them), and collision geometry intentionally reuses each link’s full visual mesh rather than a simplified proxy — the project’s own documentation notes MuJoCo treats these as convex hulls regardless. ARMOR links directly to that repository rather than re-hosting anything, so what you get is exactly what KingKong Robotics publishes, unmodified.

License & attribution

Source code
Apache-2.0
Model & mesh files
Apache-2.0
Attribution
jumper (KingKong Robotics) — Apache License 2.0, per the repository's own LICENSE and NOTICE files. The robot description under assets/jumper/ is the maintainer's own original work; NOTICE lists only the separate RL-training stack's third-party components, none of which touch this model.

ARMOR does not host or redistribute this model. Choosing “Open in ARMOR” downloads the files directly from KingKong Robotics’s own repository, unmodified. Your use of the model is governed by the license above.

Read the full license →
ARMOR is an independent tool published by DCDC LLC. It is not affiliated with, sponsored by, or endorsed by KingKong Robotics. This model is downloaded directly from KingKong Robotics' own repository under the Apache License 2.0, which you accept by downloading.

Looking for a different robot? Find more URDF sources or browse the rest of the gallery.