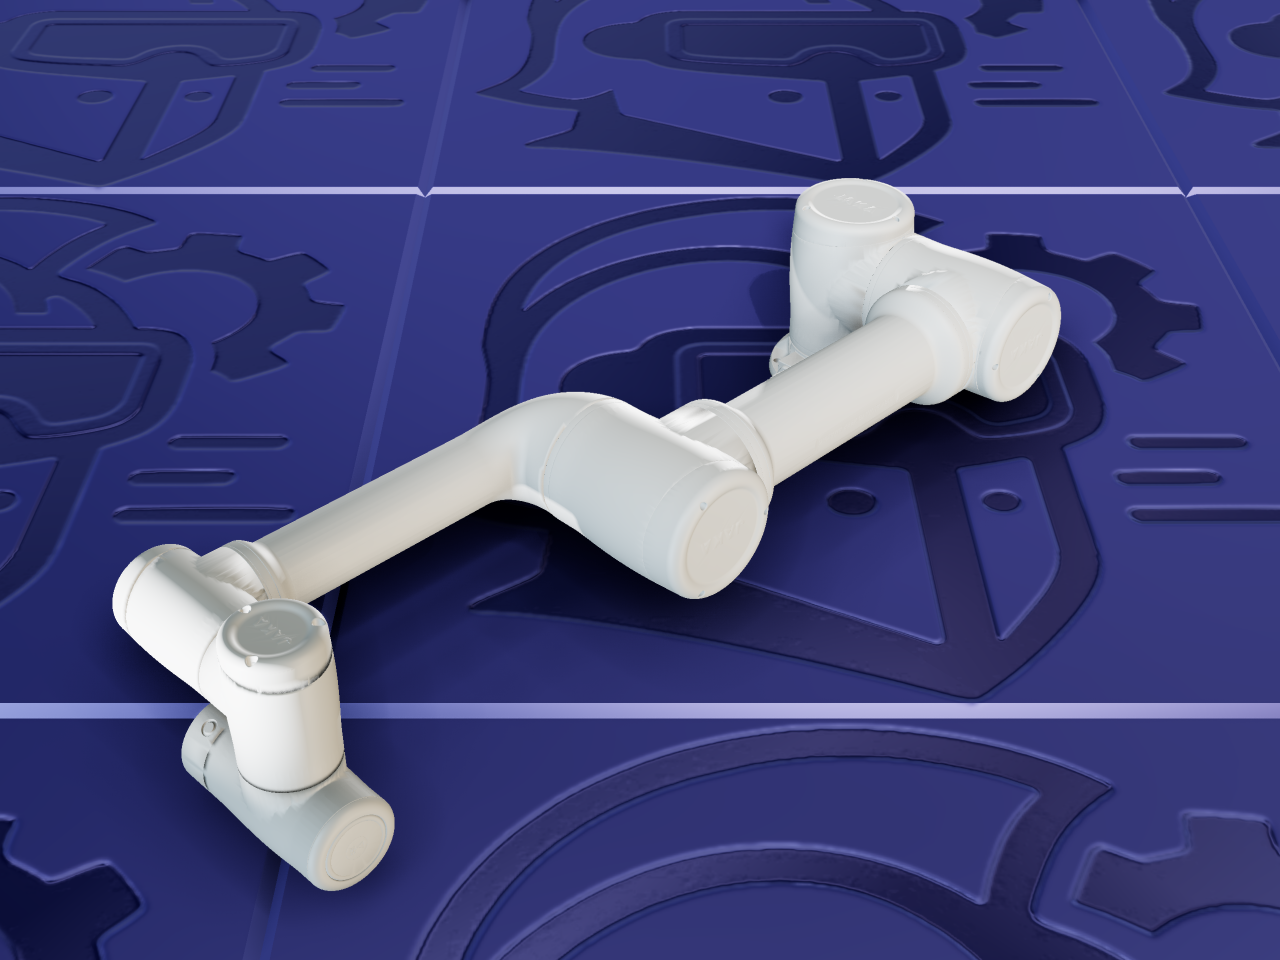
The Zu series is JAKA Robotics’ flagship general-purpose collaborative arm line — nine payload classes, from the compact 3 kg Zu3 up to the heavy-duty 35 kg Zu35, all sharing the same 6-axis mechanism scaled to size. JAKA’s own naming convention encodes payload directly in the model number.
The mechanism
Six revolute joints in series (joint_1 through joint_6) form a textbook 6-axis
collaborative arm on every model — no mimic joints, no closed loops, every movable joint an
independent actuator. Confirmed identical joint structure across every size in the line by
direct comparison of each model’s own URDF; only link dimensions, mass, and mesh geometry
scale between sizes.
Choosing a variant
All nine are mechanically identical — the choice is purely which payload class matches your application, from Zu3’s compact reach up to Zu35’s heavy-duty capacity.
About these files — read before importing
These are real, literal URDFs, not xacro templates — JAKA publishes a separate, complete URDF per model rather than one parameterized template. This gallery entry links directly to the official jaka_ros2 repository, unmodified. See this entry’s license notice above: this repository carries no license of any kind, so review that before building on any of these designs.