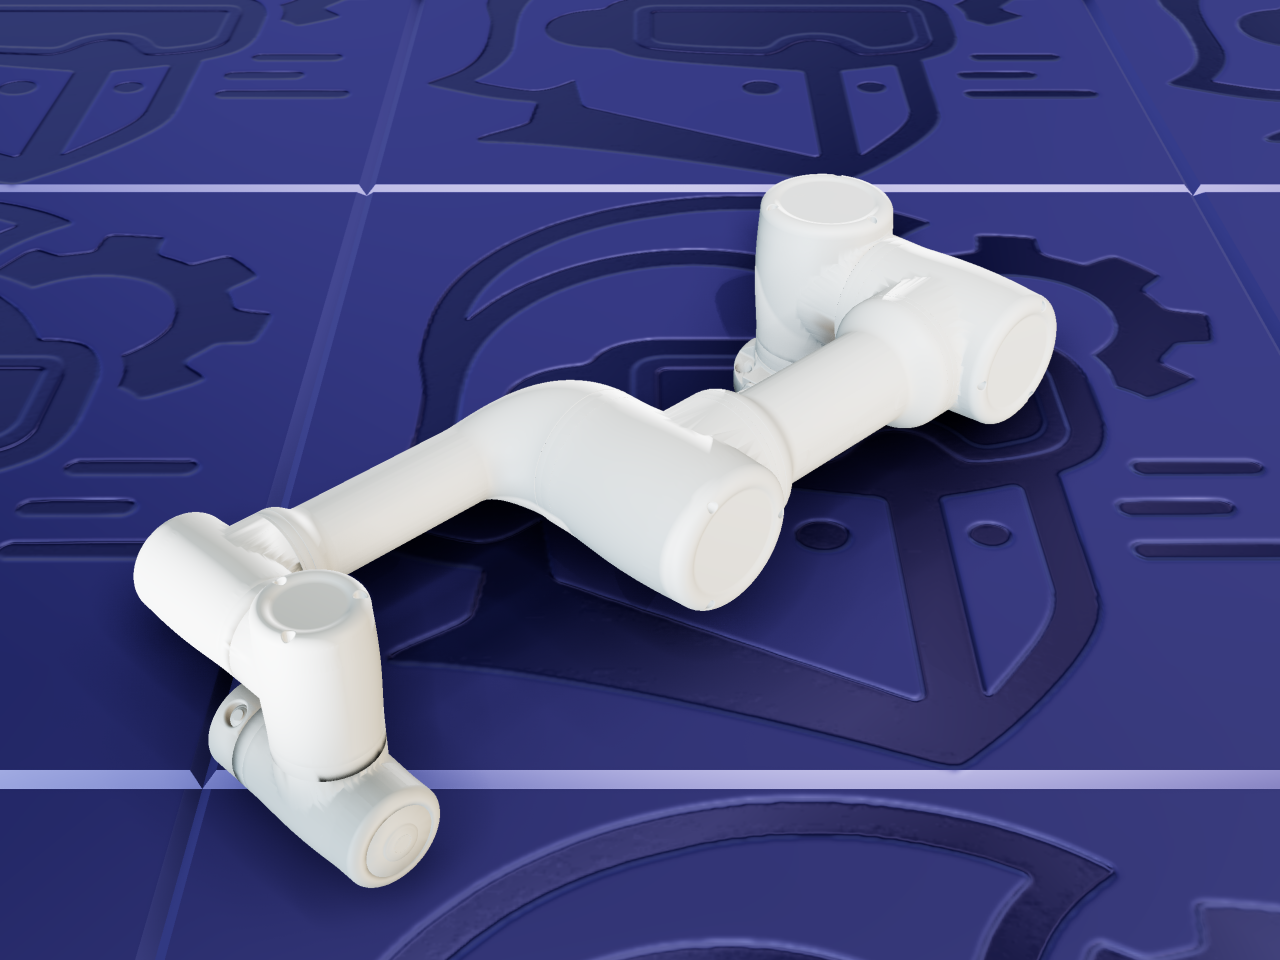
JAKA Pro rendered in ARMOR
Cobots manipulator cobot 6 DOF collaborative

JAKA Pro

by JAKA Robotics

JAKA's higher-performance collaborative arm line — five payload classes from 5 kg up to 18 kg, sharing the same 6-axis mechanism as the rest of JAKA's cobot lineup.

Add to ARMOR

Choose a collision treatment:

8 files 10 MB download

Opens in the ARMOR app on iPhone, iPad, or Mac. Don’t have it yet? Get ARMOR.

Model

8Links
6Joints
6Actuated DOF
7Meshes

Mesh formats: STL

The Pro series is JAKA Robotics’ higher-performance collaborative arm line — five payload classes from 5 kg up to 18 kg, sharing the same 6-axis mechanism as the rest of JAKA’s cobot lineup (Zu, S, A, and C).

The mechanism

Six revolute joints in series (joint_1 through joint_6) form a textbook 6-axis collaborative arm on every model — no mimic joints, no closed loops, every movable joint an independent actuator. Confirmed identical joint structure across every size in the line by direct comparison of each model’s own URDF; only link dimensions, mass, and mesh geometry scale between sizes.

Choosing a variant

All five are mechanically identical — the choice is purely which payload class matches your application.

About these files — read before importing

These are real, literal URDFs, not xacro templates — JAKA publishes a separate, complete URDF per model rather than one parameterized template. This gallery entry links directly to the official jaka_ros2 repository, unmodified. See this entry’s license notice above: this repository carries no license of any kind, so review that before building on any of these designs.

License & attribution

Source code
none
Model & mesh files
none
Attribution
jaka_description (jaka_ros2) has no license anywhere in the repository — see gallery/sources/NOTES.md under "JAKA Robotics batch" for the full finding (shared across every JAKA entry in this gallery). Under default copyright, no license actually permits downloading or reusing these files.

ARMOR does not host or redistribute this model. Choosing “Open in ARMOR” downloads the files directly from JAKA Robotics’s own repository, unmodified. Your use of the model is governed by the license above.

ARMOR is an independent tool published by DCDC LLC. It is not affiliated with, sponsored by, or endorsed by JAKA Robotics. "JAKA" and "Pro" are used here only to identify the robots these files describe. These models are downloaded directly from JAKA's own repository. No license governs them — see the license notice above before building on any of these designs.

Looking for a different robot? Find more URDF sources or browse the rest of the gallery.