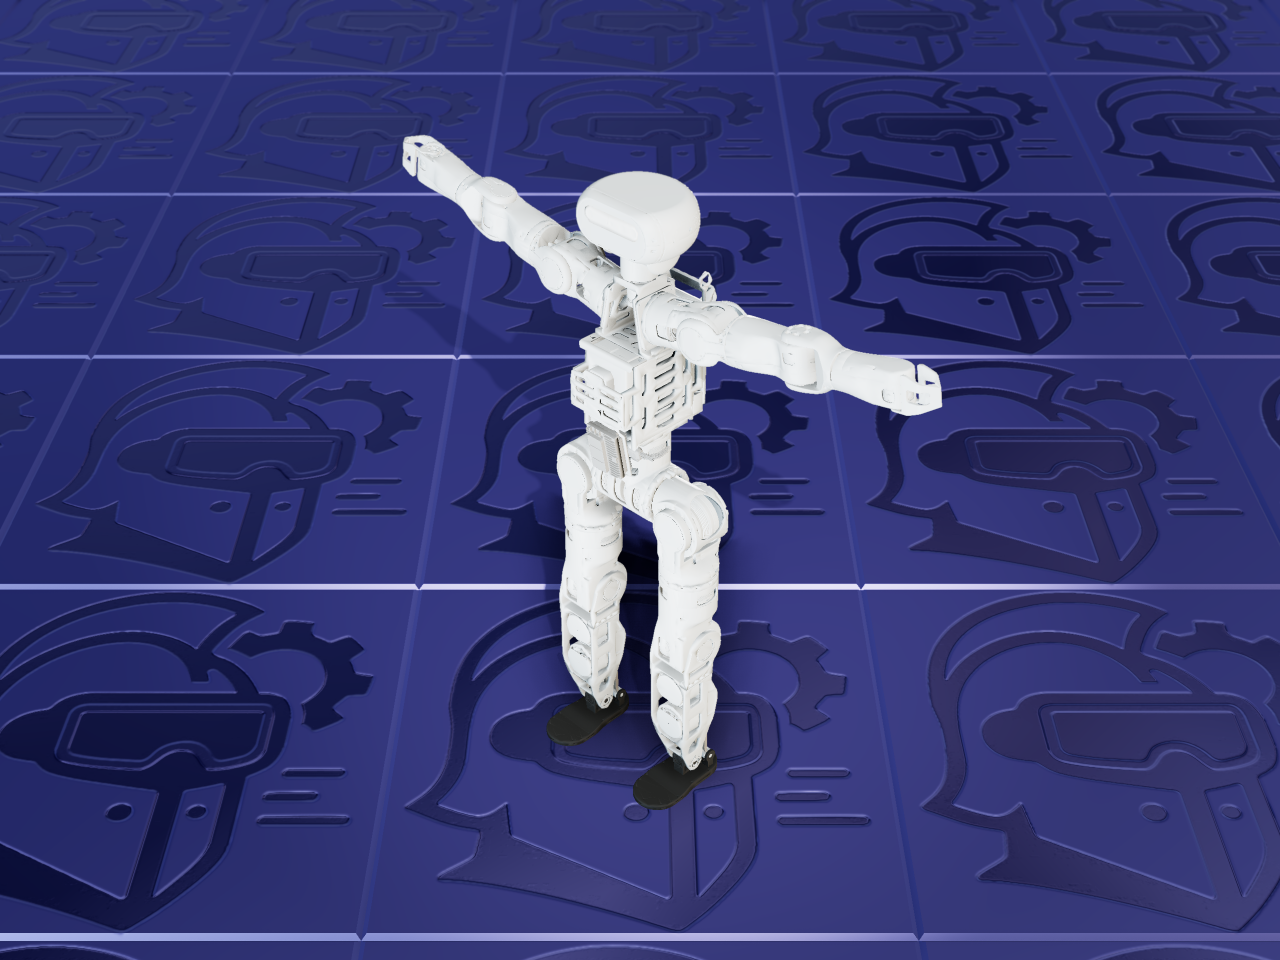
JAKA PI is JAKA Robotics’ full-size bipedal humanoid research platform, developed alongside reinforcement-learning training and sim2sim deployment code — a general-purpose humanoid built for locomotion and manipulation research rather than a specific commercial product line.
The mechanism
Each leg carries six actuated joints (hip pitch, roll, and yaw; knee; ankle pitch and roll) for twelve leg DOF. The waist adds one actuated joint (yaw). Each arm carries six actuated joints (shoulder pitch, roll, and yaw; elbow; wrist roll and yaw) for twelve arm DOF, and the neck adds two actuated joints (yaw and pitch) — 12 + 1 + 12 + 2 = twenty-seven actuated degrees of freedom in total.
The ankle is not a simple direct-drive joint: two “drive” motors mounted up near the knee
actuate a pair of push-rods that drive the ankle’s pitch and roll through a parallel
linkage — a real closed kinematic loop, which URDF cannot express directly. This
description encodes that loop as extra open-chain joints (a drive/link1_up/link2_up/
link1_down/link2_down/ankle_base chain per leg) alongside the direct ankle_pitch/
ankle_roll joints a controller actually commands — confirmed by JAKA’s own simplified
deployment model, which keeps only the direct joints and drops the linkage branch
entirely.
About this file — read before importing
This links directly to
JAKA_RL_Lab’s deploy/meshes directory,
JAKA’s own repository. This is a real, literal URDF, not a xacro template. ARMOR links
directly to the repository rather than re-hosting anything, so what you get is exactly
what’s published there, unmodified. See this entry’s license notice above: this repository
carries no license of any kind for JAKA’s own content, so review that before building on
this design.