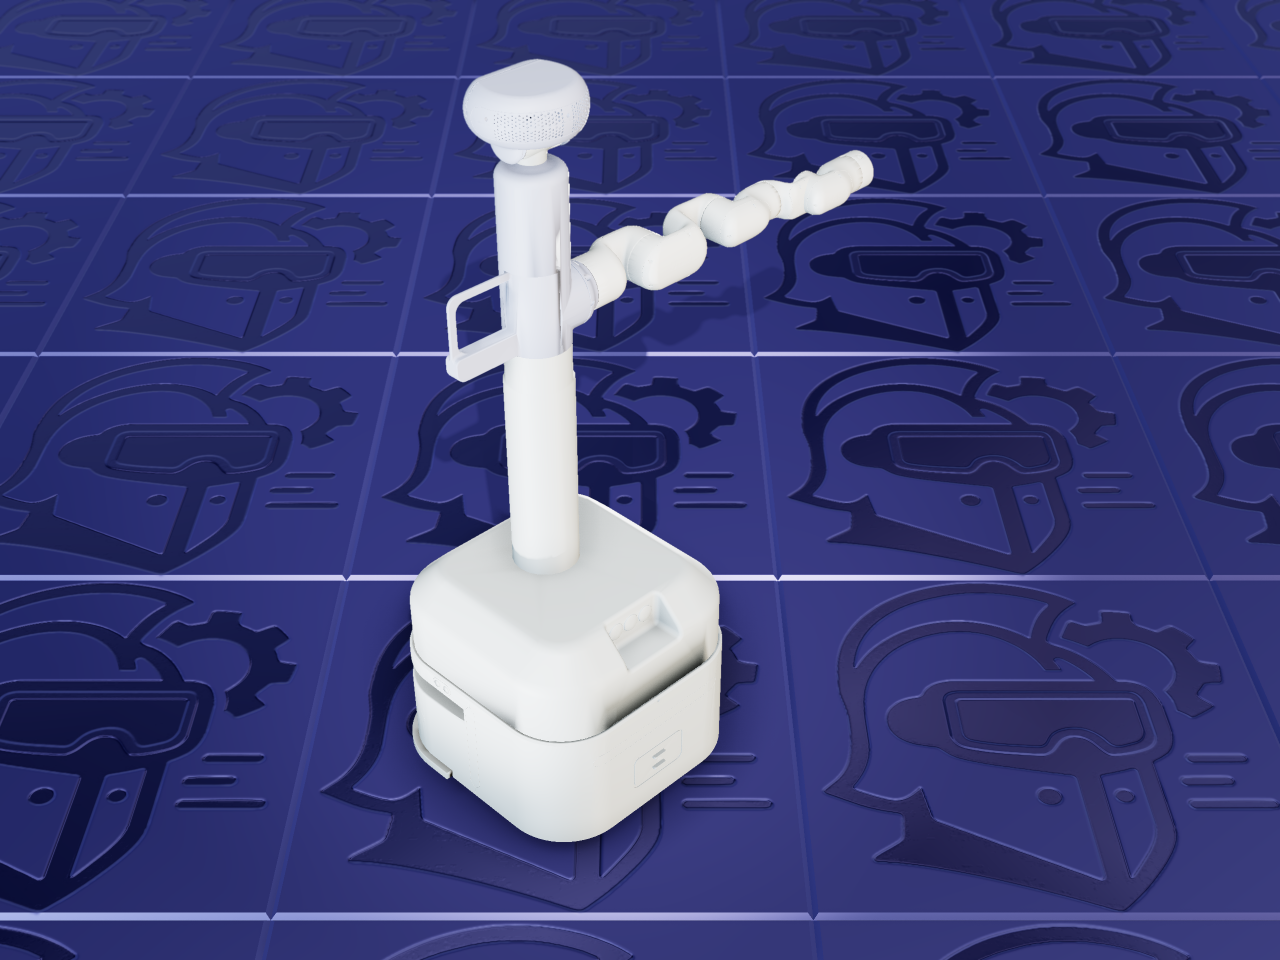
JAKA Lumi rendered in ARMOR
Mobile & Legged mobile manipulator wheeled manipulator 12 DOF

JAKA Lumi

by JAKA Robotics

JAKA's mobile-manipulator platform — a wheeled differential-drive base with a height-adjustable lift column, a 6-axis arm, and a small pan/tilt head mechanism.

Add to ARMOR

15 files 17.3 MB download

Opens in the ARMOR app on iPhone, iPad, or Mac. Don’t have it yet? Get ARMOR.

Model

15Links
12Joints
12Actuated DOF
14Meshes

Mesh formats: STL

JAKA Lumi is JAKA Robotics’ mobile-manipulator platform — a wheeled base built to bring a collaborative arm into a workspace rather than bolt it to a fixed table. This description models a single-arm configuration: a differential-drive wheeled base, a prismatic lift column that raises and lowers the whole upper body, a 6-axis collaborative arm (the same mechanism as JAKA’s MiniCobo), and a small pan/tilt head mechanism above it.

The mechanism

Two continuous joints drive the wheels. A prismatic joint raises and lowers the lift column, topped by a single revolute joint (a torso/shoulder-pan pivot) from which the mechanism branches: a two-joint head/neck mechanism on one side, and JAKA’s standard 6-axis arm (six revolute joints, plus a fixed tool-center-point frame) on the other. Twelve actuated joints in total — no mimic joints or closed kinematic loops anywhere in the description.

About this file — read before importing

This links directly to JAKA_Lumi’s jaka_lumi_description package, JAKA’s own repository. ARMOR links directly to that repository rather than re-hosting anything, so what you get is exactly what’s published there, unmodified. JAKA’s own promotional materials for Lumi show a two-armed configuration of this platform; the URDF actually published in this repository models the single-arm build described above, not the two-armed one pictured in marketing renders.

License & attribution

Source code
Apache-2.0
Model & mesh files
Apache-2.0
Attribution
JAKA_Lumi (JAKA Robotics) — Apache License 2.0, per the repository's own root LICENSE file. The jaka_lumi_description package's own package.xml separately says "BSD", but that's a boilerplate default value, not a considered choice — the repo-root LICENSE is the real, deliberately-committed license text and is treated as authoritative. See NOTES.md for the full reasoning.

ARMOR does not host or redistribute this model. Choosing “Open in ARMOR” downloads the files directly from JAKA Robotics’s own repository, unmodified. Your use of the model is governed by the license above.

Read the full license →
ARMOR is an independent tool published by DCDC LLC. It is not affiliated with, sponsored by, or endorsed by JAKA Robotics. "JAKA" and "Lumi" are used here only to identify the robot this file describes. This model is downloaded directly from JAKA's own repository under the Apache License 2.0, which you accept by downloading.

Looking for a different robot? Find more URDF sources or browse the rest of the gallery.