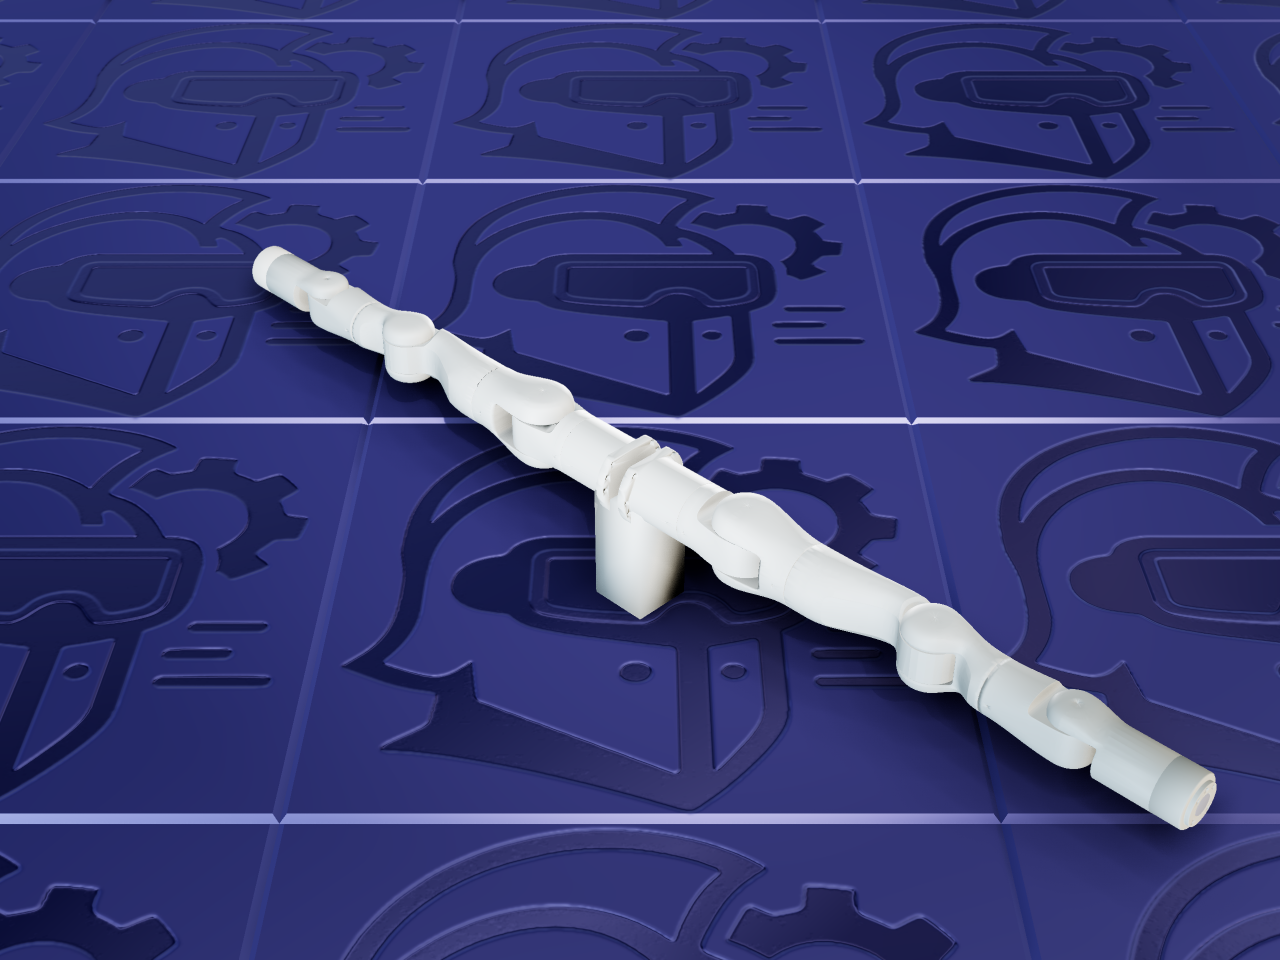
JAKA K1 is JAKA Robotics’ dual-arm collaborative platform — two independent 7-axis arms sharing one fixed base, aimed at tasks that benefit from two coordinated arms working together (assembly, bimanual handling) rather than a single arm alone.
The mechanism
Each arm carries seven actuated revolute joints in series, for fourteen actuated degrees of freedom in total — no mimic joints or closed kinematic loops. The extra joint per arm compared to JAKA’s 6-axis Zu/Pro/S/A/C lines gives each arm redundant degrees of freedom, useful for avoiding self-collision between the two arms and reaching around obstacles in a shared workspace.
About this file — read before importing
This links directly to
JAKA_K1’s jaka_k1_description package, JAKA’s
own repository. This is a real, literal URDF, not a xacro template (the package’s k1-arm/
subdirectory carries its own xacro tree for a single arm, and the combined dual-arm file
used here carries a few dead, commented-out xacro snippets left over from development, but
the file ARMOR actually imports is complete, literal XML — no macro expansion needed).
ARMOR links directly to the repository rather than re-hosting anything, so what you get is
exactly what’s published there, unmodified. See this entry’s license notice above: this
repository carries no license of any kind, so review that before building on this design.