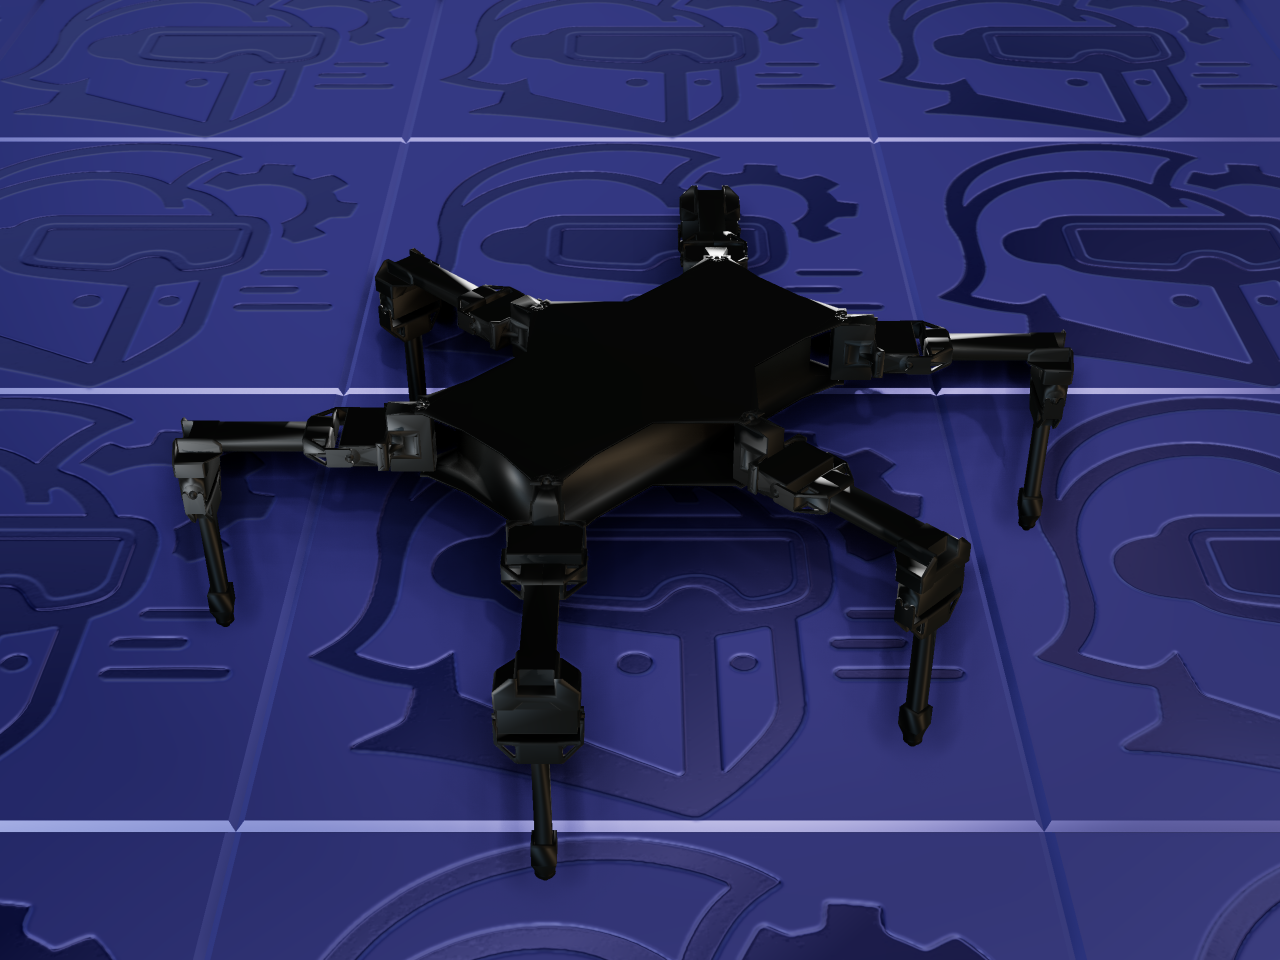
Trossen Robotics’ X-Series hexapod line covers four chassis/actuator combinations, all sharing the same six-legged mechanism: Alpha, the current flagship platform with a wider chassis and longer legs, and three Mark IV models built on a shared, more compact chassis — PincherX Mark IV, PincherX Mark IV Sensor (the same chassis with added sensor mounting), and WidowX Mark IV (the same chassis with more powerful servos).
The mechanism
Each of the six legs carries three actuated revolute joints — coxa, femur, and tibia — for eighteen degrees of freedom total, plus a fixed foot-contact frame at the end of each leg. No mimic joints or closed kinematic loops in any of the four models — a plain hexapod leg arrangement throughout, differing only in chassis dimensions and mesh geometry.
Choosing a variant
All four are mechanically identical in DOF and joint layout — the choice is purely which physical platform you have or want to visualize: the larger Alpha, or one of the three Mark IV chassis variants distinguished by their servo hardware.
About these files — read before importing
These files are not URDFs. Trossen Robotics publishes each hexapod model as a single,
self-contained .urdf.xacro — the entire leg mechanism is defined and instantiated six
times within that one file, with no further included files under this repository’s default
build arguments (an optional Gazebo-texture include and an optional external-URDF include
both exist in the file but are gated behind arguments that default to off). This gallery
entry links directly to the official
interbotix_ros_crawlers repository
— unmodified, exactly as Trossen Robotics publishes it. ARMOR expands the macros itself
after downloading, so Open in ARMOR gives you a working robot.