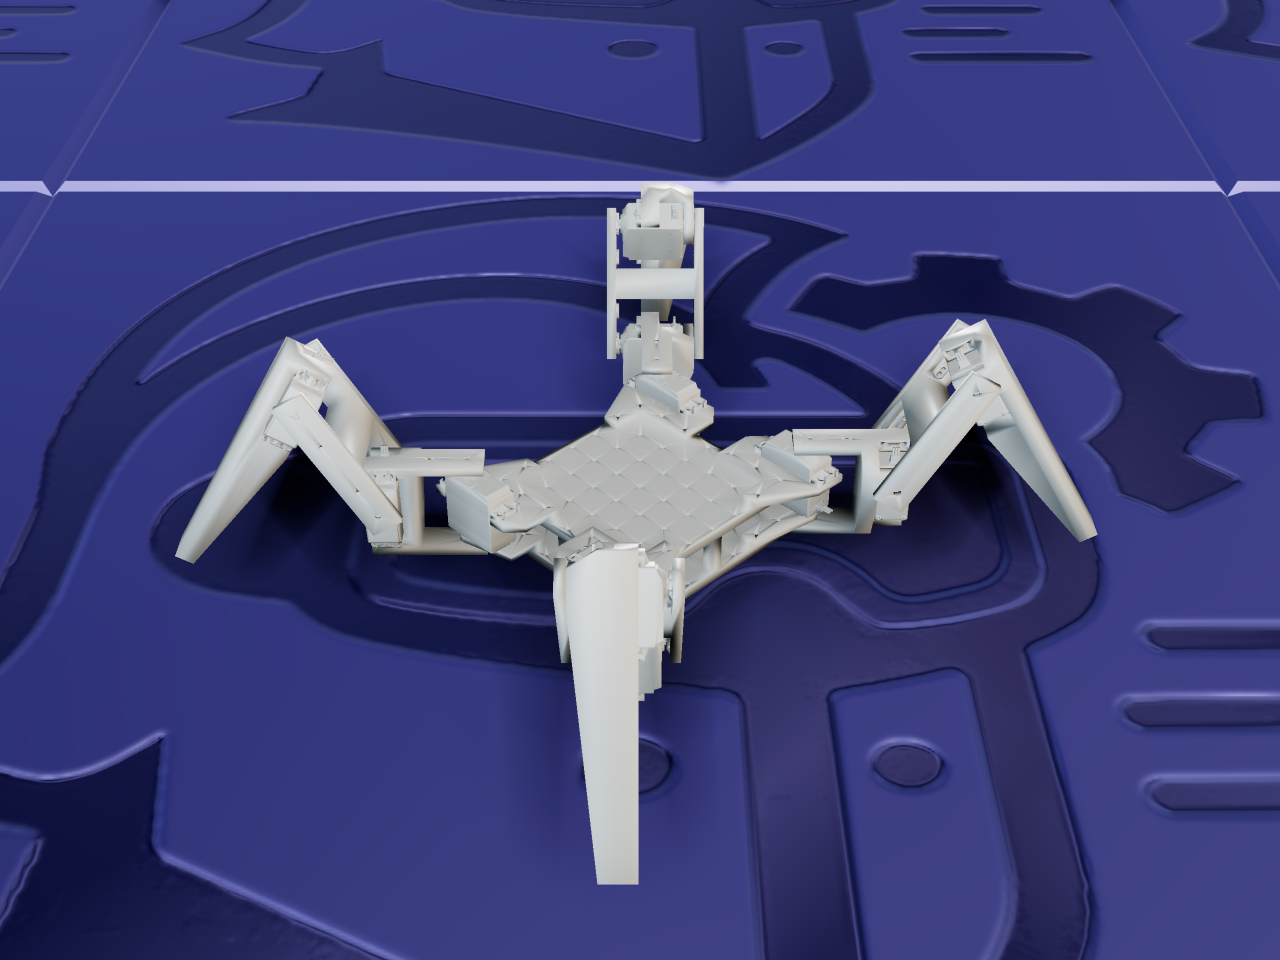
SPDR Bot rendered in ARMOR
Mobile & Legged quadruped legged 12 DOF open source reinforcement learning

SPDR Bot

by Indystrycc

A 4-legged desktop spider robot designed for NVIDIA Isaac Sim and Isaac Lab — a hobbyist build with a 3D-printable physical counterpart sold by its creator.

Add to ARMOR

17 files 6.8 MB download

Opens in the ARMOR app on iPhone, iPad, or Mac. Don’t have it yet? Get ARMOR.

Model

13Links
12Joints
12Actuated DOF
13Meshes

Mesh formats: STL

SPDR Bot is a 4-legged desktop spider robot from Indystrycc, designed as a learning platform for NVIDIA Isaac Sim and Isaac Lab reinforcement-learning experiments, with a 3D-printable physical build available from the creator.

The mechanism

Each of the four legs carries three actuated joints in series — a plain open serial chain per leg, twelve actuated joints total, with no mimic joints or closed kinematic loops. The description was generated directly from a Fusion 360 assembly via the CAD-to-URDF export pipeline, which is why every joint reads as type="continuous" (unlimited rotation) rather than a hand-tuned revolute range — a common signature of this class of exporter, not an error in the source file.

About this file — read before importing

This links directly to SpdrBot, Indystrycc’s own repository — the URDF description package bundled alongside the Isaac Sim/Isaac Lab training project and USD assets. ARMOR links directly to that repository rather than re-hosting anything, so what you get is exactly what’s published there, unmodified. See this entry’s license notice above — the bundled LICENSE file states MIT, but its copyright holder doesn’t match this project, so review it yourself before building on this design.

License & attribution

Source code
MIT
Model & mesh files
MIT
Attribution
SpdrBot_description (Indystrycc) — the LICENSE file bundled inside SpdrBot_description/ states the MIT License, credited to "Copyright (c) 2018 Toshinori Kitamura", a name with no visible connection to Indystrycc or this project and predating it — most likely leftover boilerplate from a template package rather than an intentional grant. The package.xml's own field is a literal, unedited "TODO", and the repository README separately says only "open for personal and educational use... consider linking back", which is vaguer than MIT. Published as MIT per the file's own text, at the user's explicit direction, with this discrepancy disclosed. See NOTES.md for the full reasoning.

ARMOR does not host or redistribute this model. Choosing “Open in ARMOR” downloads the files directly from Indystrycc’s own repository, unmodified. Your use of the model is governed by the license above.

Read the full license →
ARMOR is an independent tool published by DCDC LLC. It is not affiliated with, sponsored by, or endorsed by Indystrycc. This model is downloaded directly from the author's own repository. Its bundled LICENSE file states the MIT License, but is credited to a named third party unconnected to this project — see this entry's license notice above before building on it.

Looking for a different robot? Find more URDF sources or browse the rest of the gallery.