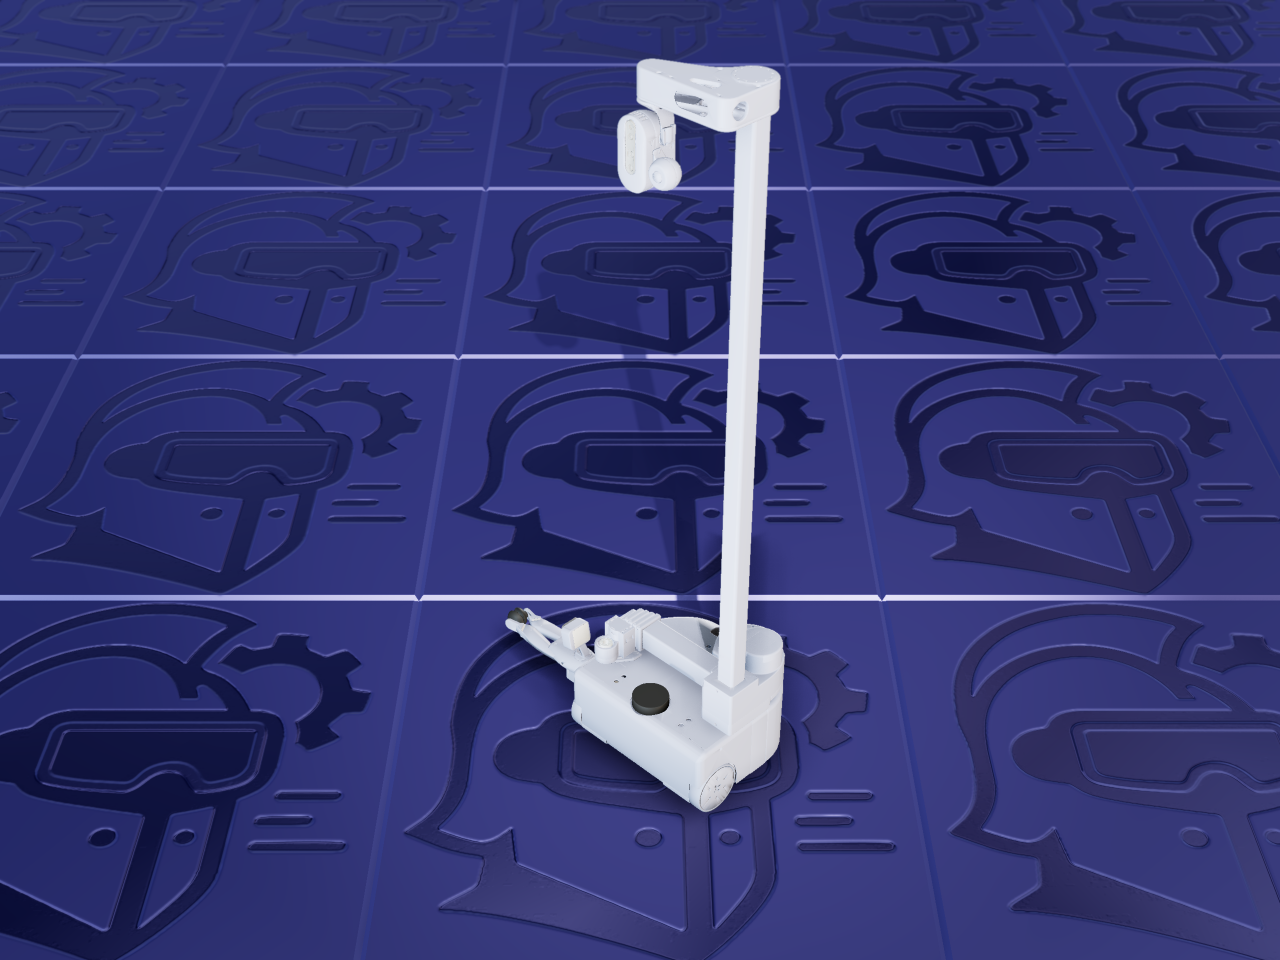
Stretch 3 is Hello Robot’s mobile manipulator: a wheeled base, a vertical mast with a lift carriage, and a telescoping arm that extends horizontally from it. This entry links directly to Hello Robot’s own URDF repository.
The mechanism
Two drive wheels (continuous joints) steer the base like a differential drive. The lift raises the arm carriage along the mast. The arm telescopes out from the carriage; the file models it as four prismatic segments of 0.13 m each, but Hello Robot’s own tooling collapses them into a single arm axis, so the arm counts as one actuated degree of freedom. The wrist adds three more (yaw, pitch, and roll), and the head has a pan and tilt pair that aims its cameras: 2 + 1 + 1 + 3 + 2 = nine actuated degrees of freedom. There are no closed kinematic loops.
The gripper variant also has two finger joints. The description gives them a range of zero, so in ARMOR the gripper stays in its rest position.
About these models
Hello Robot notes that the geometry in this repository is nominal and uncalibrated: a real Stretch carries its own calibration data, so a particular robot’s kinematics differ slightly from this description. The repository also carries URDFs for the earlier Stretch RE1 and RE2. They are not offered here: in a plain MuJoCo import, several of their tool files fail to load, and the Stretch 3 files do not.
About this file — read before importing
This links directly to the SE3 folder of Hello Robot’s
stretch_urdf repository. ARMOR links
directly to that repository rather than re-hosting anything, so what you get is exactly
what Hello Robot publishes, unmodified.