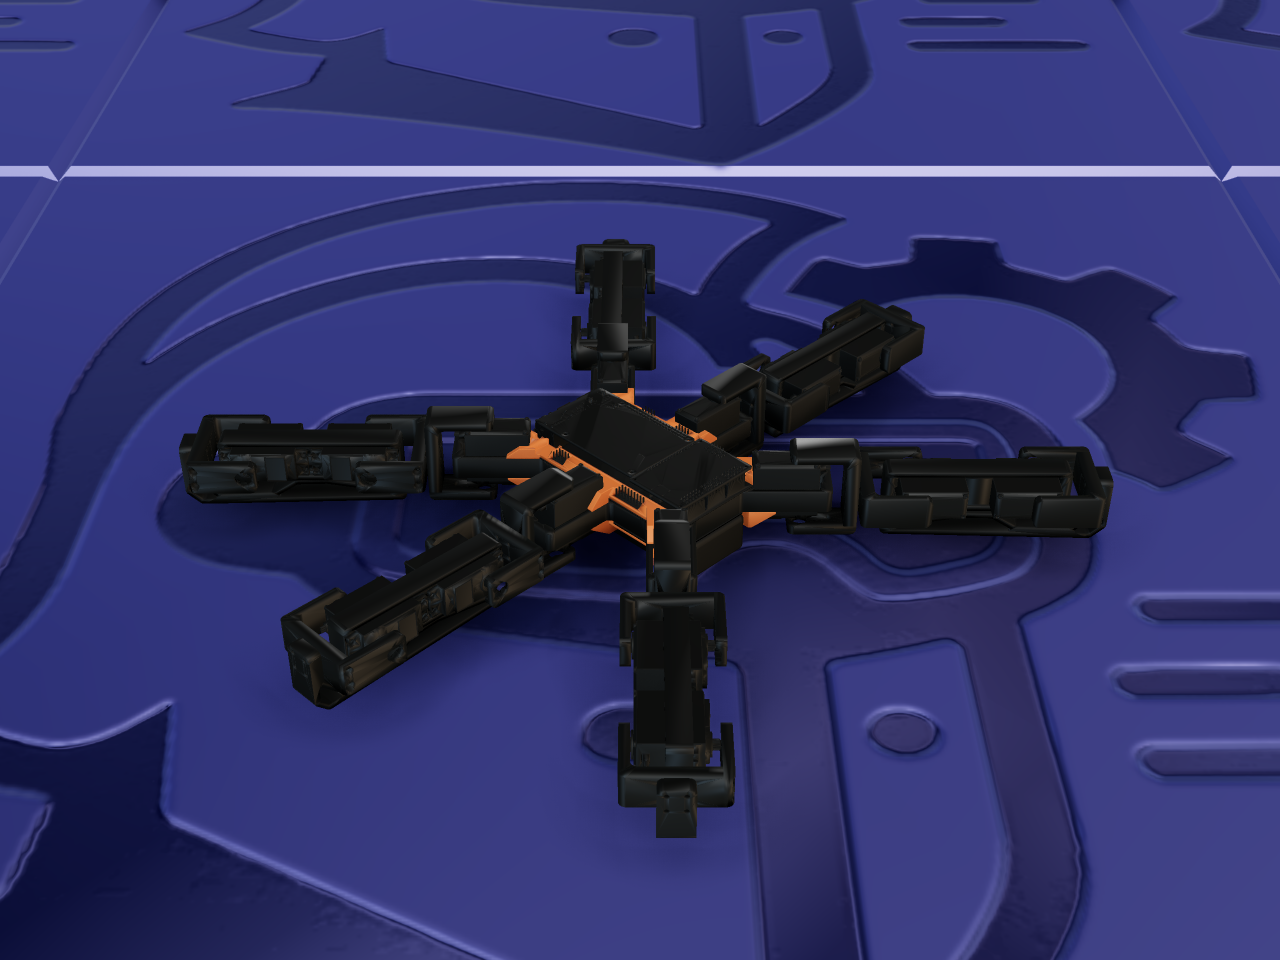
Hexapod (ggldnl) rendered in ARMOR
Mobile & Legged hexapod legged 18 DOF open source 3D printed

Hexapod (ggldnl)

by ggldnl

A fully open-source, low-cost 3D-printed hexapod — 18 actuated leg joints, a custom PCB and real-time firmware, with the same control core running the physical robot and its simulator.

Add to ARMOR

12 files 6.8 MB download

Opens in the ARMOR app on iPhone, iPad, or Mac. Don’t have it yet? Get ARMOR.

Model

72Links
18Joints
18Actuated DOF
11Meshes

Mesh formats: STL

The Hexapod project is an end-to-end, from-scratch six-legged robot: 3D-printable parts and a bill of materials, an optional custom PCB, C++ firmware running the control loop in real time, and a Raspberry Pi handling configuration and telemetry above it. The same firmware core compiles into a shared library used by the project’s own simulator, so gaits tuned in simulation run unmodified on the physical robot.

The mechanism

Each of the six legs carries three actuated revolute joints — coxa, femur, and tibia — for eighteen degrees of freedom total, a plain hexapod leg arrangement with no mimic joints or closed kinematic loops. The remaining fixed joints in the description tie the printed chassis and hardware components (battery, electronics mount, brackets) rigidly to the body.

About this file — read before importing

This links directly to Hexapod-Hardware, ggldnl’s own repository — the description package published alongside the printable parts, BOM, and assembly guide. ARMOR links directly to that repository rather than re-hosting anything, so what you get is exactly what’s published there, unmodified, under the CERN Open Hardware Licence v2 (Weakly Reciprocal).

License & attribution

Source code
CERN-OHL-W-2.0
Model & mesh files
CERN-OHL-W-2.0
Attribution
Hexapod-Hardware (ggldnl) — CERN Open Hardware Licence v2, Weakly Reciprocal.

ARMOR does not host or redistribute this model. Choosing “Open in ARMOR” downloads the files directly from ggldnl’s own repository, unmodified. Your use of the model is governed by the license above.

Read the full license →
ARMOR is an independent tool published by DCDC LLC. It is not affiliated with, sponsored by, or endorsed by ggldnl or gmatics. This model is downloaded directly from the author's own repository under the CERN Open Hardware Licence v2 (Weakly Reciprocal), which you accept by downloading.

Looking for a different robot? Find more URDF sources or browse the rest of the gallery.