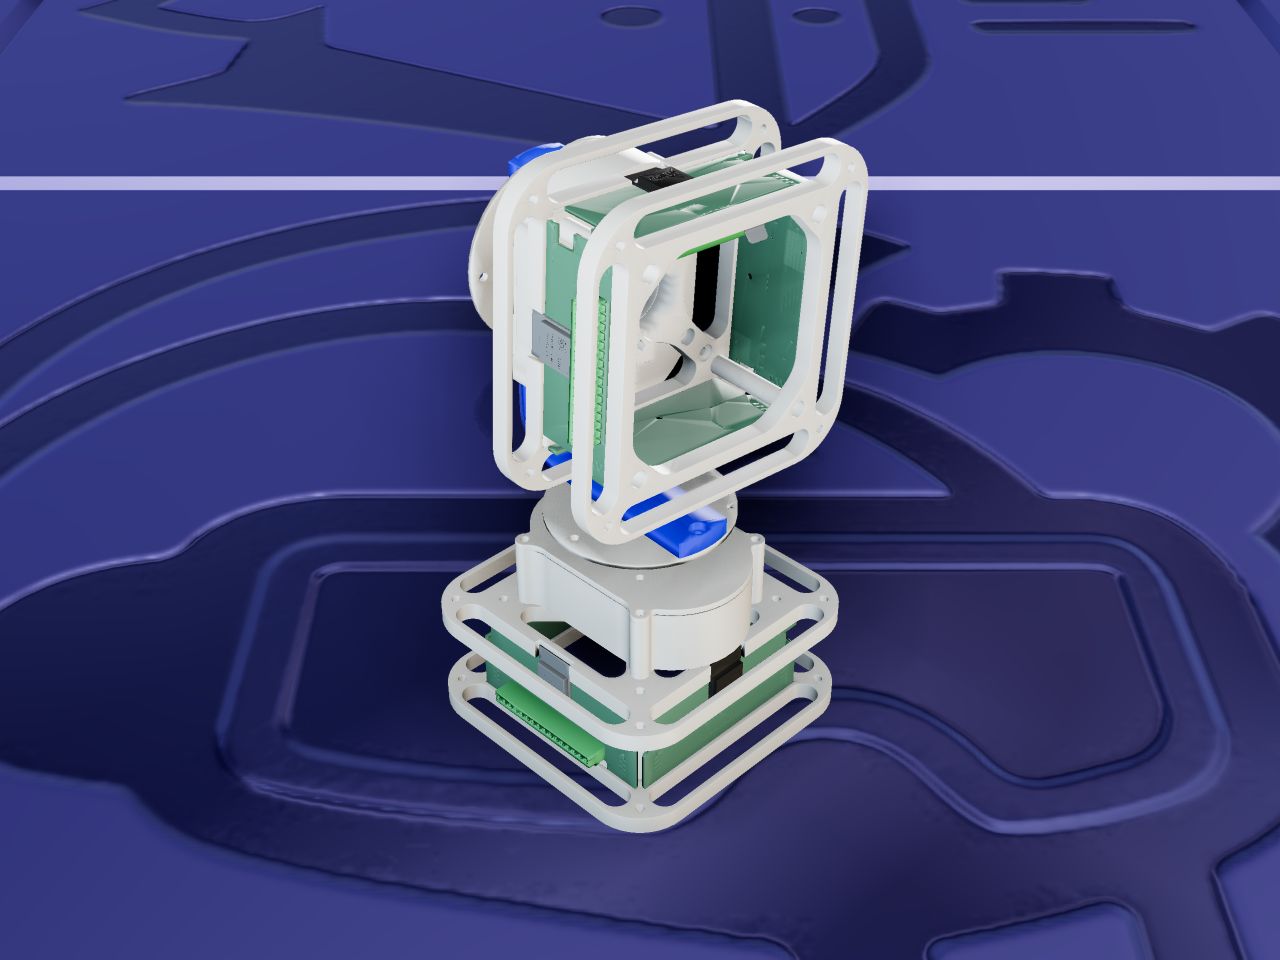
The GEMS Articulated Robot is a stationary 2-DOF pan/tilt mechanism built entirely from two GEMS Servomotor units and a connecting bracket — part of the GEMS (“Graceful Equalising of Mechatronics Students”) Erasmus+ project’s open-source mechatronics education hardware. Per the project’s own description, it “operates in a spherical coordinate system” and carries an ultrasound sensor to scan its surroundings, with the two servo units coordinating over wireless communication in the real hardware.
The mechanism
The base (grounded) servo’s output shaft drives a bracket that carries the entire second servo — housing and all — through a full rotation: pan. That second servo’s own output shaft then drives a small sensor mount independently: tilt. Two actuated degrees of freedom in total, each one the same housing/output-shaft interface every GEMS servomotor exposes externally — see the GEMS drivetrain page for why the internal gear train inside each unit isn’t modeled joint-by-joint.
About this file — read before importing
GEMS_Mechanics ships only native FreeCAD (.FCStd) source files — no pre-exported URDF, STL,
or STEP. This model was generated directly from that upstream FreeCAD assembly by a
purpose-built conversion pipeline (real OpenCASCADE geometry, real per-part color decoded
from the CAD’s own material data, and the assembly’s own joint graph parsed to recover the
real 2-DOF pan/tilt kinematics — no FreeCAD installation used at all), then self-hosted here
since no ready-to-link file exists upstream to point to instead. It’s shared under the same
CC BY-SA 4.0 license as the original CAD.
Parts sealed inside each servo’s housing and never externally visible on the assembled unit — fasteners, the internal gear train, and the motor/bearings — are omitted from the mesh entirely rather than modeled, keeping each mesh within the app’s real per-mesh triangle budget. Each of the four internal electronics boards’ own substrate shape and real color are kept (visible through the housing’s open frame), along with any individual board component large enough to matter (a connector, the ESP32 module, the ultrasonic sensor’s transducer pair) — only the swarm of genuinely tiny surface-mount parts (resistors, small ICs) is left out. See NOTES.md for the measured reasoning and exact size threshold.