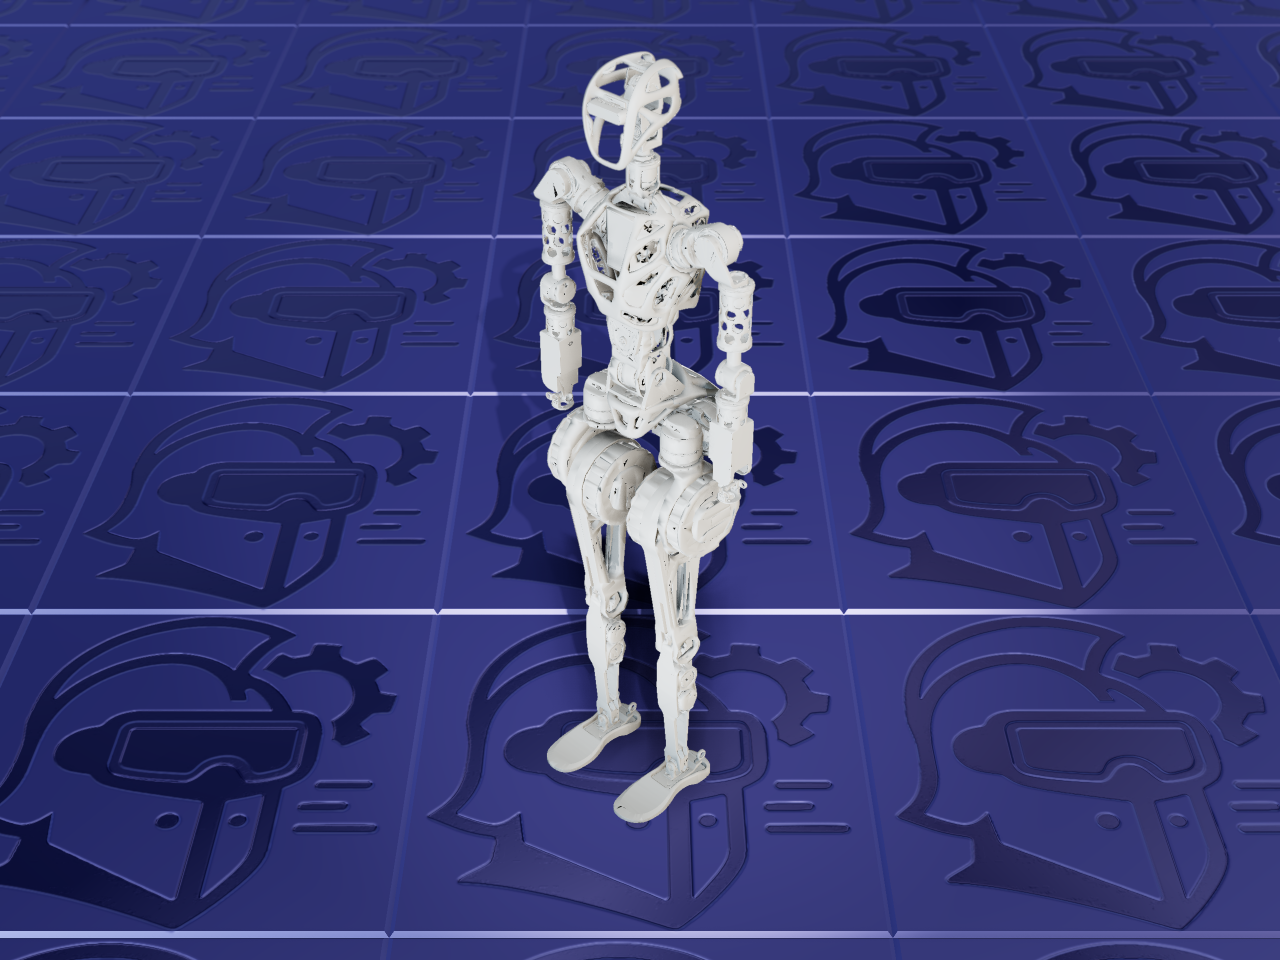
GR-1 is Fourier Intelligence’s general-purpose humanoid — a full-body bipedal platform sold in two generations: the original GR1T1 (“GR-1”) and the upgraded GR1T2 (“GR-1 Pro”), both sharing the same 32-DOF mechanism and available with an optional dexterous hand at each wrist.
The mechanism
Each leg carries six actuated joints (hip roll, yaw, and pitch; knee; ankle pitch and roll) for twelve leg DOF, the waist adds three actuated joints (yaw, pitch, roll), each arm carries seven actuated joints (shoulder pitch, roll, and yaw; elbow; wrist yaw, roll, and pitch) for fourteen arm DOF, and the head/neck adds three actuated joints (yaw, roll, pitch) — 12 + 3 + 14 + 3 = thirty-two actuated degrees of freedom on the base platform, all independently driven, no mimic joints or closed kinematic loops.
The optional dexterous hand adds a 6-DOF hand at each wrist — some finger joints in the
URDF carry a mimic constraint, mechanically coupled rather than independently actuated.
With both hands attached, total actuated DOF rises to 44.
Choosing a variant
Two independent choices: GR1T1 or GR1T2 (GR-1’s original vs. upgraded generation — mechanically identical in DOF, pick GR1T2 unless you specifically need the original), and with or without hands (the bare arm flange, or Fourier’s own 6-DOF dexterous hand at each wrist).
About this file — read before importing
This links directly to Wiki-GRx-Models, Fourier Intelligence’s own repository. These are real, literal URDFs (not xacro templates) — ARMOR downloads and imports each one directly, exactly as Fourier Intelligence publishes it, with no macro expansion step needed.