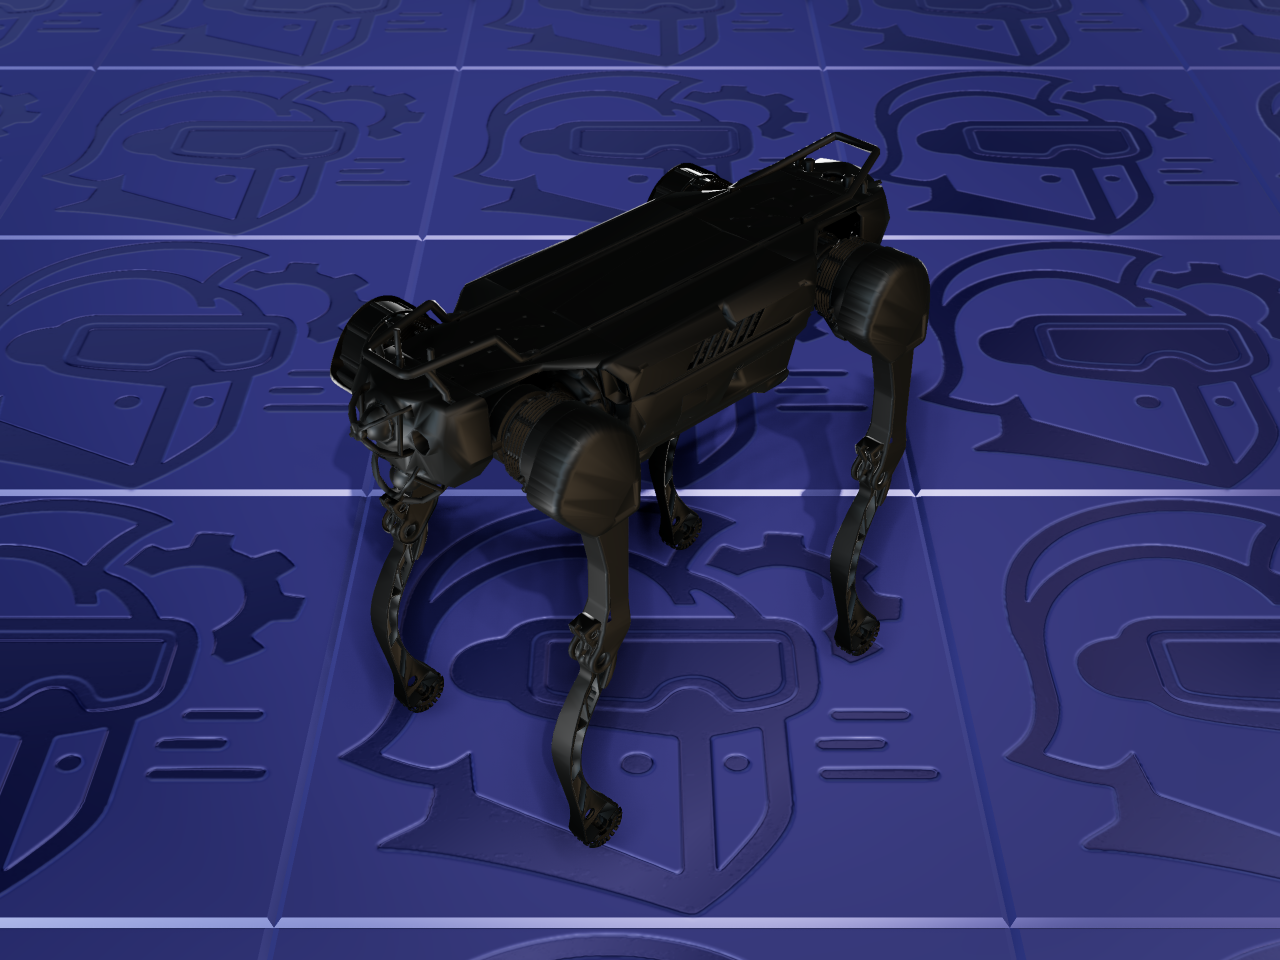
X30 is Deep Robotics’ industrial quadruped, aimed at inspection and emergency-response work. The model description includes the robot’s four LiDAR sensor mounts alongside the torso and legs.
The mechanism
Each leg carries three actuated joints: a hip abduction joint (HipX), a hip joint (HipY), and a knee. Four legs give twelve actuated degrees of freedom, all independently driven, with no mimic joints and no closed kinematic loops. Each foot is a fixed link, and the LiDAR housings are fixed links on the torso.
About this file — read before importing
This links directly to the X30 folder of Deep Robotics’
deep_robotics_model repository.
ARMOR links directly to that repository rather than re-hosting anything, so what you get is
exactly what Deep Robotics publishes, unmodified.