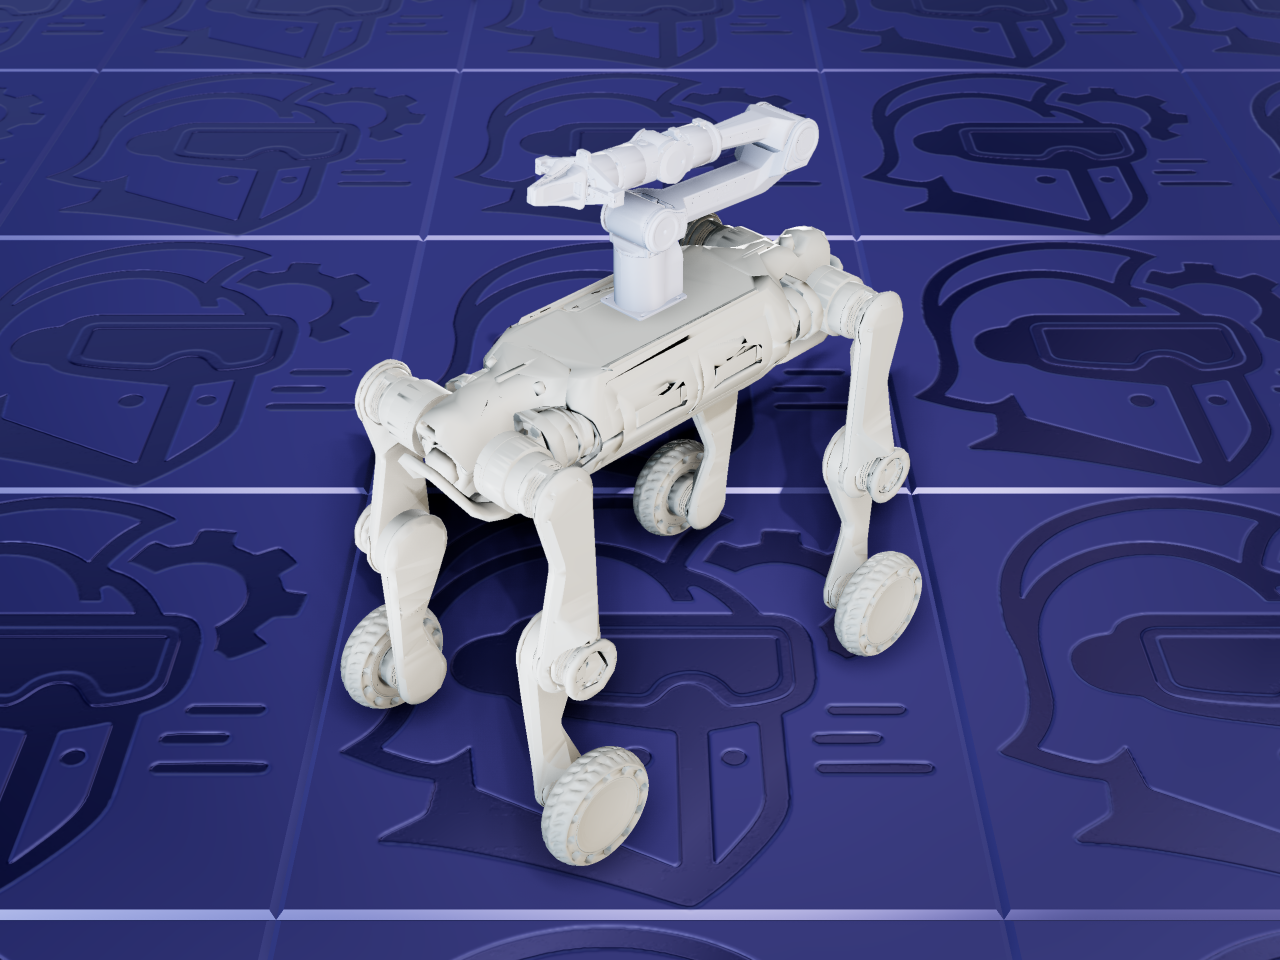
Lynx M20 is Deep Robotics’ wheeled-legged robot: a quadruped whose legs end in drive wheels, so it can roll on flat ground and step over obstacles. The repository publishes the original M20, the later M20S, and an M20 with a robot arm as three descriptions, which this entry offers as variants.
The mechanism
Each leg carries three revolute joints (hip abduction, hip, and knee) and a continuous wheel joint at the end, so four legs give sixteen actuated degrees of freedom (twelve leg joints plus four wheels), all independently driven, with no mimic joints and no closed kinematic loops. The camera and LiDAR mounts are fixed links.
The arm variant adds six revolute joints for the arm and two prismatic joints for the gripper fingers. The file defines the two fingers as separate joints with no mimic link, so the count here is twenty-four.
M20 or M20S?
The two share the same meshes and mass. They differ in the joint limits: the M20S’s description allows a higher torque at the leg joints and wheels, and the M20’s allows a higher leg-joint speed.
About this file — read before importing
This links directly to the M20, M20S, and M20_Piper folders of Deep Robotics’
deep_robotics_model repository.
ARMOR links directly to that repository rather than re-hosting anything, so what you get is
exactly what Deep Robotics publishes, unmodified.