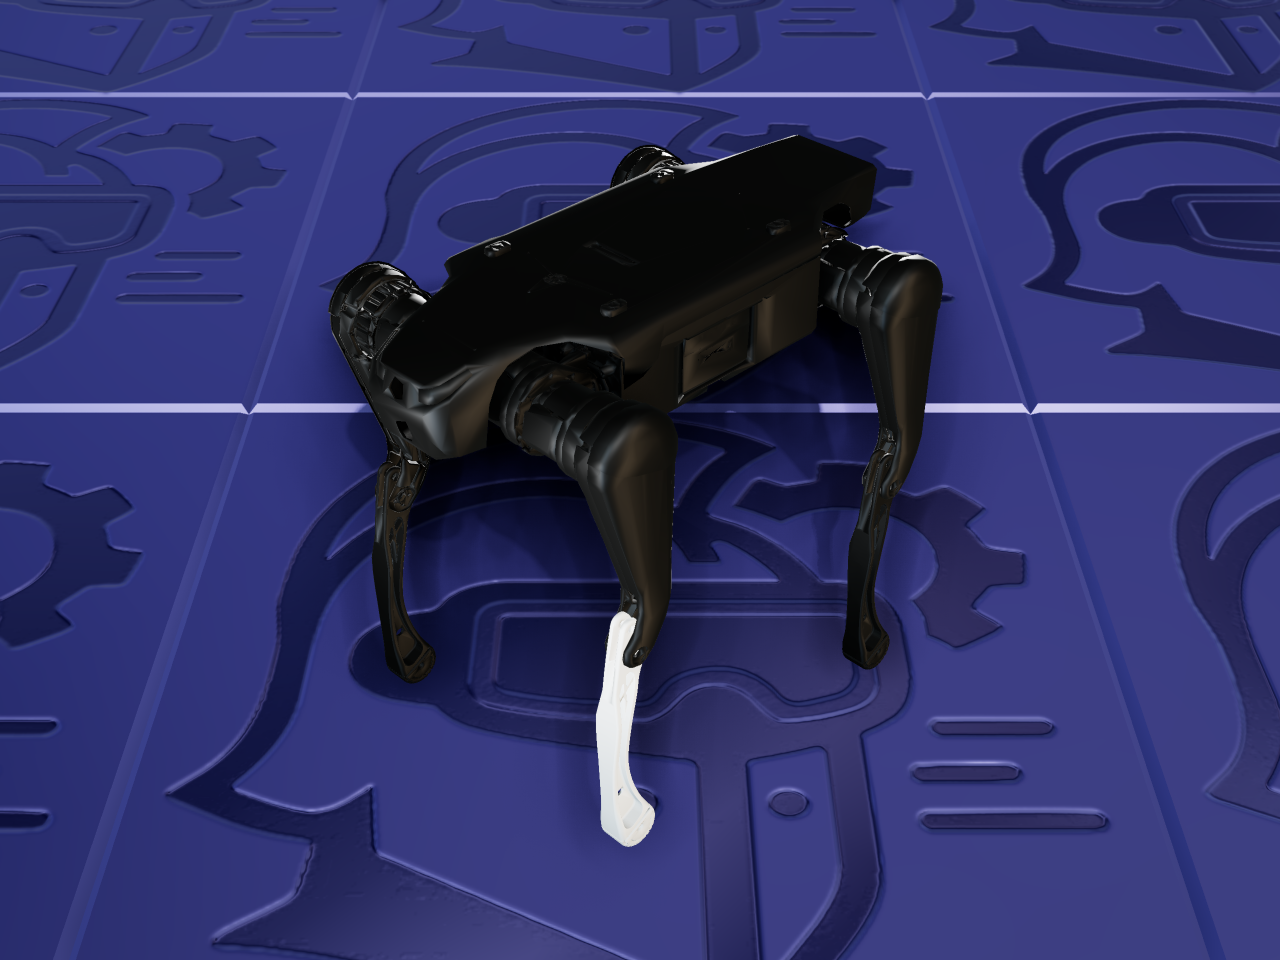
Lite3 is the compact quadruped in Deep Robotics’ lineup, positioned for developers. Deep Robotics publishes its model description in the same repository as its larger robots.
The mechanism
Each leg carries three actuated joints: a hip abduction joint (HipX), a hip joint (HipY), and a knee. Four legs give twelve actuated degrees of freedom, all independently driven, with no mimic joints and no closed kinematic loops. Each foot is a fixed link at the end of the shank.
About this file — read before importing
This links directly to the Lite3 folder of Deep Robotics’
deep_robotics_model repository.
ARMOR links directly to that repository rather than re-hosting anything, so what you get is
exactly what Deep Robotics publishes, unmodified.