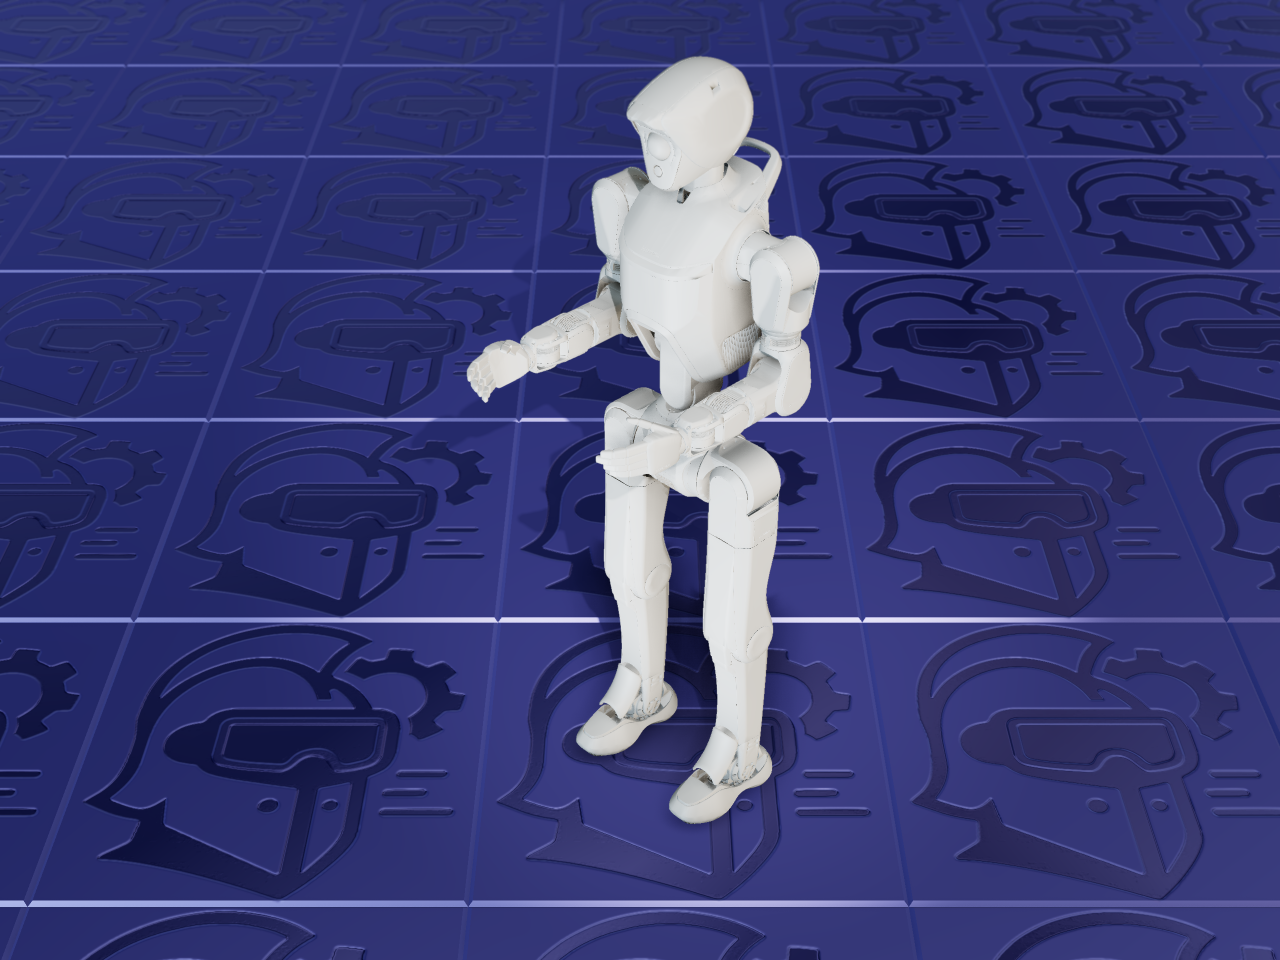
DR02 is Deep Robotics’ full-size humanoid, published here in two versions: the Pro, with a fuller set of joints, and the Standard. Deep Robotics publishes both in its model repository.
The mechanism
On the Pro, each leg carries six actuated joints (hip, knee, and ankle axes) for twelve leg DOF. The waist adds three, the neck two, and each arm seven (a three-axis shoulder, elbow, and three-axis wrist) for fourteen arm DOF: 12 + 3 + 2 + 14 = thirty-one actuated degrees of freedom, all independently driven, with no mimic joints or closed kinematic loops.
The Standard has the same six-joint legs, a single waist joint, and four-joint arms (a three-axis shoulder and an elbow), with no neck: 12 + 1 + 8 = twenty-one.
About this file — read before importing
This links directly to the DR02 folder of Deep Robotics’
deep_robotics_model repository.
ARMOR links directly to that repository rather than re-hosting anything, so what you get is
exactly what Deep Robotics publishes, unmodified.