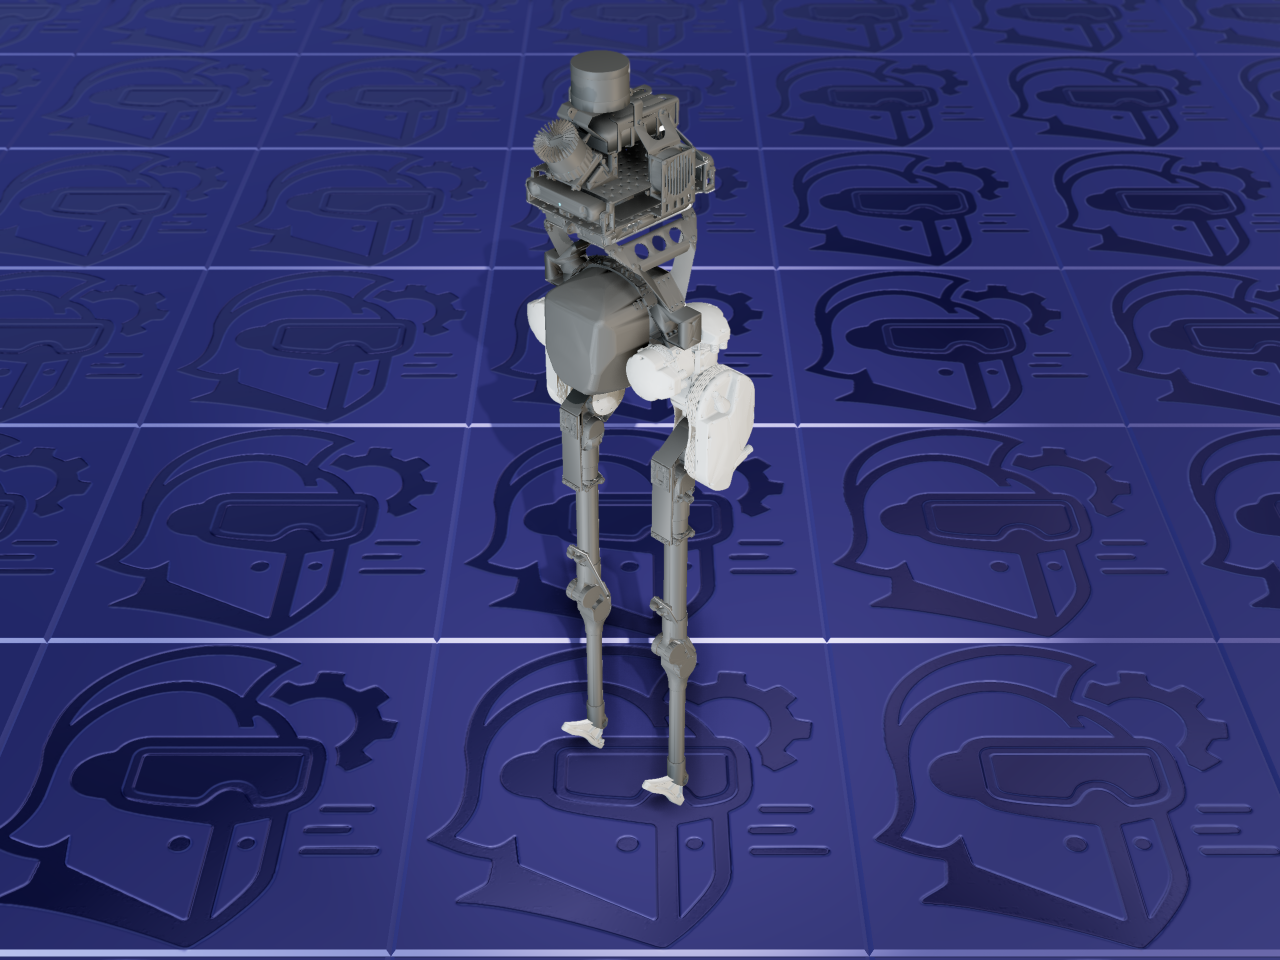
Cassie rendered in ARMOR
Mobile & Legged bipedal legged research 10 DOF

Cassie

by Agility Robotics

Agility Robotics' bipedal research platform — a spring-legged biped whose passive four-bar linkage leg design has made it one of the most widely used robots in legged locomotion research.

Add to ARMOR

Choose a collision treatment:

19 files 78.9 MB download

Opens in the ARMOR app on iPhone, iPad, or Mac. Don’t have it yet? Get ARMOR.

Model

23Links
14Joints
10Actuated DOF
18Meshes

Mesh formats: STL

Cassie is Agility Robotics’ bipedal research platform, spun out of Oregon State University’s Dynamic Robotics Laboratory — a spring-legged biped whose distinctive knee-forward, bird-like stance and passive elastic leg design have made it one of the most widely used robots in academic legged-locomotion research, from classical control through modern reinforcement learning.

The mechanism

Each leg carries five actuated joints — hip abduction, hip rotation, hip flexion, knee, and toe — for ten actuated degrees of freedom in total. The signature part of Cassie’s design is what happens between the knee and the foot: a passive four-bar linkage (an achilles rod and a spring-loaded shin/tarsus connection) provides compliant, spring-like ground contact without a dedicated actuator. URDF can’t express a true closed loop, so this description encodes that linkage as two extra open-chain joints per leg (knee_to_shin, ankle_joint) — kinematically dependent on the knee joint, not independently driven, per the repository’s own dependent_joints.yaml.

About this file — read before importing

This links directly to cassie_description, a third-party academic repository from the University of Michigan’s Biped Lab — Agility Robotics has never published a URDF for Cassie itself. See this entry’s license notice above: this repository carries no license of any kind, so review that before building on this design. ARMOR links directly to the repository rather than re-hosting anything, so what you get is exactly what’s published there, unmodified.

License & attribution

Source code
none
Model & mesh files
none
Attribution
cassie_description (UMich-BipedLab) has no license anywhere in the repository — no LICENSE file, and package.xml's own field is a literal, unedited "TODO" (confirmed via GitHub's own repository metadata showing no detected license). Agility Robotics itself has never published a URDF for Cassie at all. Published here anyway, link-only, at the user's explicit direction.

ARMOR does not host or redistribute this model. Choosing “Open in ARMOR” downloads the files directly from Agility Robotics’s own repository, unmodified. Your use of the model is governed by the license above.

ARMOR is an independent tool published by DCDC LLC. It is not affiliated with, sponsored by, or endorsed by Agility Robotics or the University of Michigan's Biped Lab. "Cassie" is used here only to identify the robot this file describes. This model is downloaded directly from a third-party academic repository, not from Agility Robotics — see the license notice above before building on it.

Looking for a different robot? Find more URDF sources or browse the rest of the gallery.