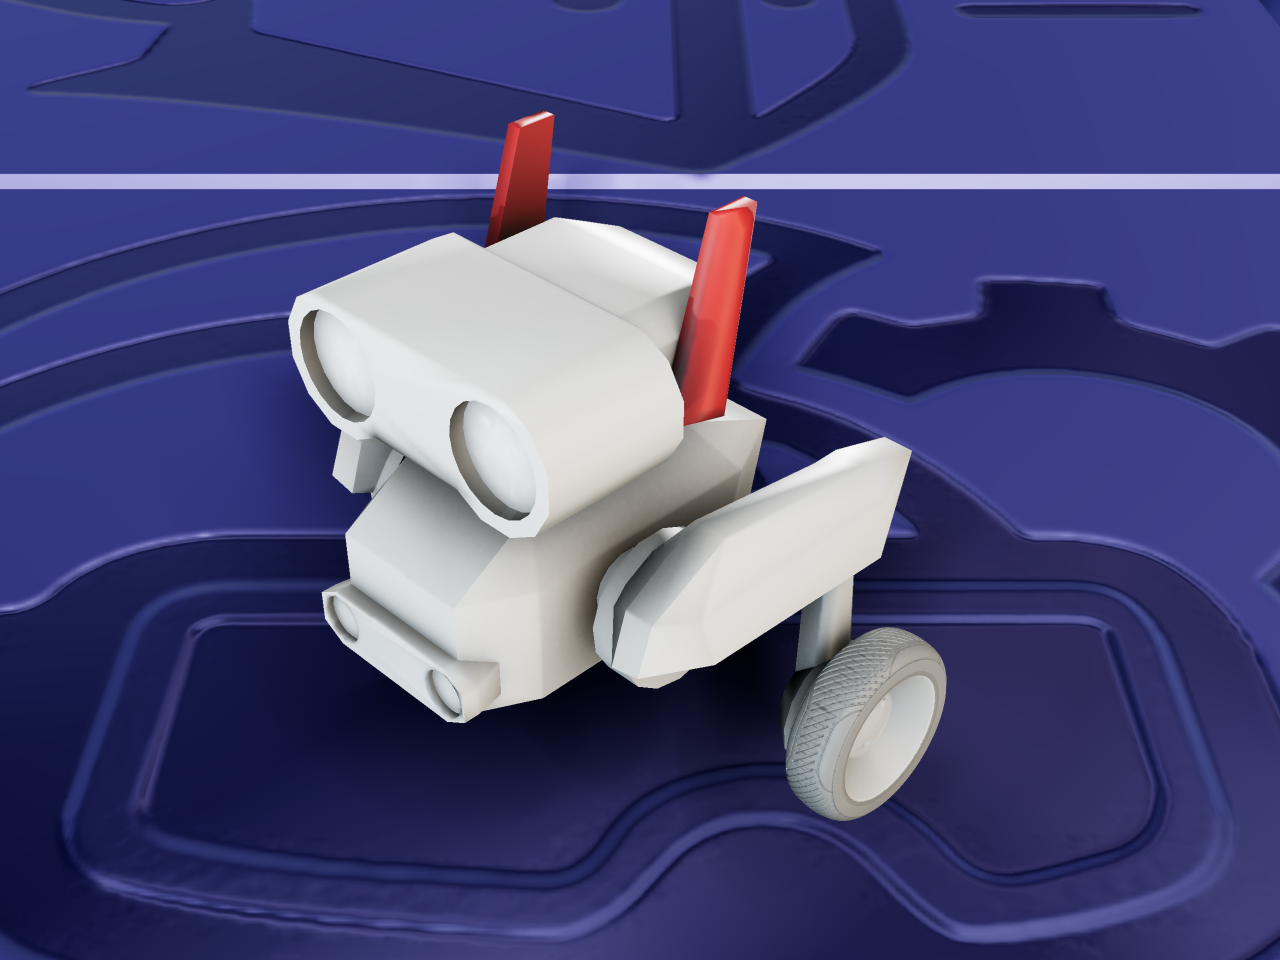
BENI is a small wheeled-legged robot from Mondo Robotics, a camera robot that balances and rolls on two wheeled legs and can jump. Mondo Robotics published its model alongside the training code and trained policies in the open-beni repository, which also runs the robot in a browser game.
The mechanism
Each leg has a hip joint (L1 or R1), a knee joint (L2 or R2), and a continuous wheel joint (LW or RW) at its end. The head adds a yaw and a roll joint, for eight actuated degrees of freedom in all. There are no mimic joints and no closed kinematic loops. The head’s roll joint can move only ±0.05 rad (about ±3°), and its yaw joint has a torque limit of 0.1 N·m; both are as the author published them.
About this file — read before importing
This links directly to the assets/beni_base folder of Mondo Robotics’
open-beni repository. The same folder holds
the MuJoCo model that the project’s training code loads; this URDF has the same joints,
limits, and masses. ARMOR links directly to that repository rather than re-hosting
anything, so what you get is exactly what Mondo Robotics publishes, unmodified.