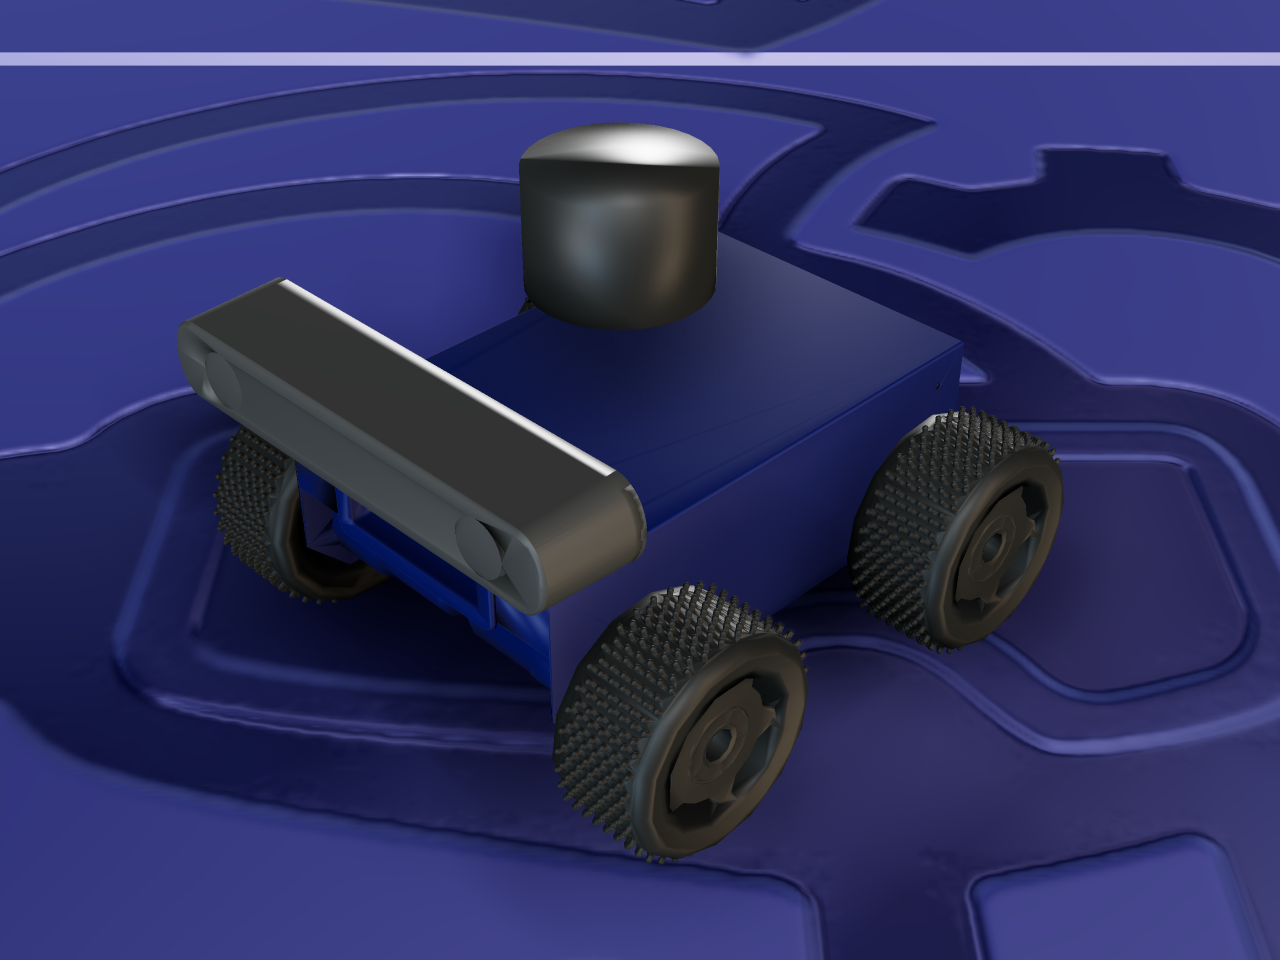
Axioma rendered in ARMOR
Mobile & Legged wheeled 4WD autonomous SLAM open source 4 DOF

Axioma

by Mario David Alvarez Vallejo

A four-wheel-drive autonomous mobile robot for industrial logistics, with a 2D LiDAR, an IMU, and a ZED 2i stereo camera — an open-source ROS 2 platform with SLAM, visual SLAM, and Nav2 navigation.

Add to ARMOR

6 files 4.8 MB download

Opens in the ARMOR app on iPhone, iPad, or Mac. Don’t have it yet? Get ARMOR.

Model

15Links
14Joints
4Actuated DOF
4Meshes

Mesh formats: DAE, STL

Axioma is a four-wheel-drive autonomous mobile robot for industrial logistics, designed by Mario David Alvarez Vallejo and published as an open-source ROS 2 workspace. The same repository carries its SLAM, visual SLAM, sensor fusion, and navigation software, and a Gazebo simulation.

The mechanism

A rigid chassis carries four independently driven wheels (continuous joints), which steer the robot by skidding, the way a tracked vehicle turns, so there is no steering joint. The wheels are the four actuated degrees of freedom; there are no mimic joints and no closed kinematic loops. A 2D LiDAR, an IMU, and a ZED 2i stereo camera are mounted on fixed joints, so they add frames but no motion.

About this file — read before importing

The author’s description is xacro, not plain URDF, because the ZED 2i camera adds eight frames whose offsets are computed rather than typed out. This gallery entry links directly to the author’s own Axioma_robot repository, unmodified, and ARMOR expands the macros itself after downloading, so Open in ARMOR gives you a working robot.

License & attribution

Source code
Apache-2.0
Model & mesh files
Apache-2.0
Attribution
Axioma_robot (Mario David Alvarez Vallejo) — Apache License 2.0, per the repository's own LICENSE file and every package's package.xml.

ARMOR does not host or redistribute this model. Choosing “Open in ARMOR” downloads the files directly from Mario David Alvarez Vallejo’s own repository, unmodified. Your use of the model is governed by the license above.

Read the full license →
ARMOR is an independent tool published by DCDC LLC. It is not affiliated with, sponsored by, or endorsed by Mario David Alvarez Vallejo. This model is downloaded directly from the author's own repository under the Apache License 2.0, which you accept by downloading.

Looking for a different robot? Find more URDF sources or browse the rest of the gallery.