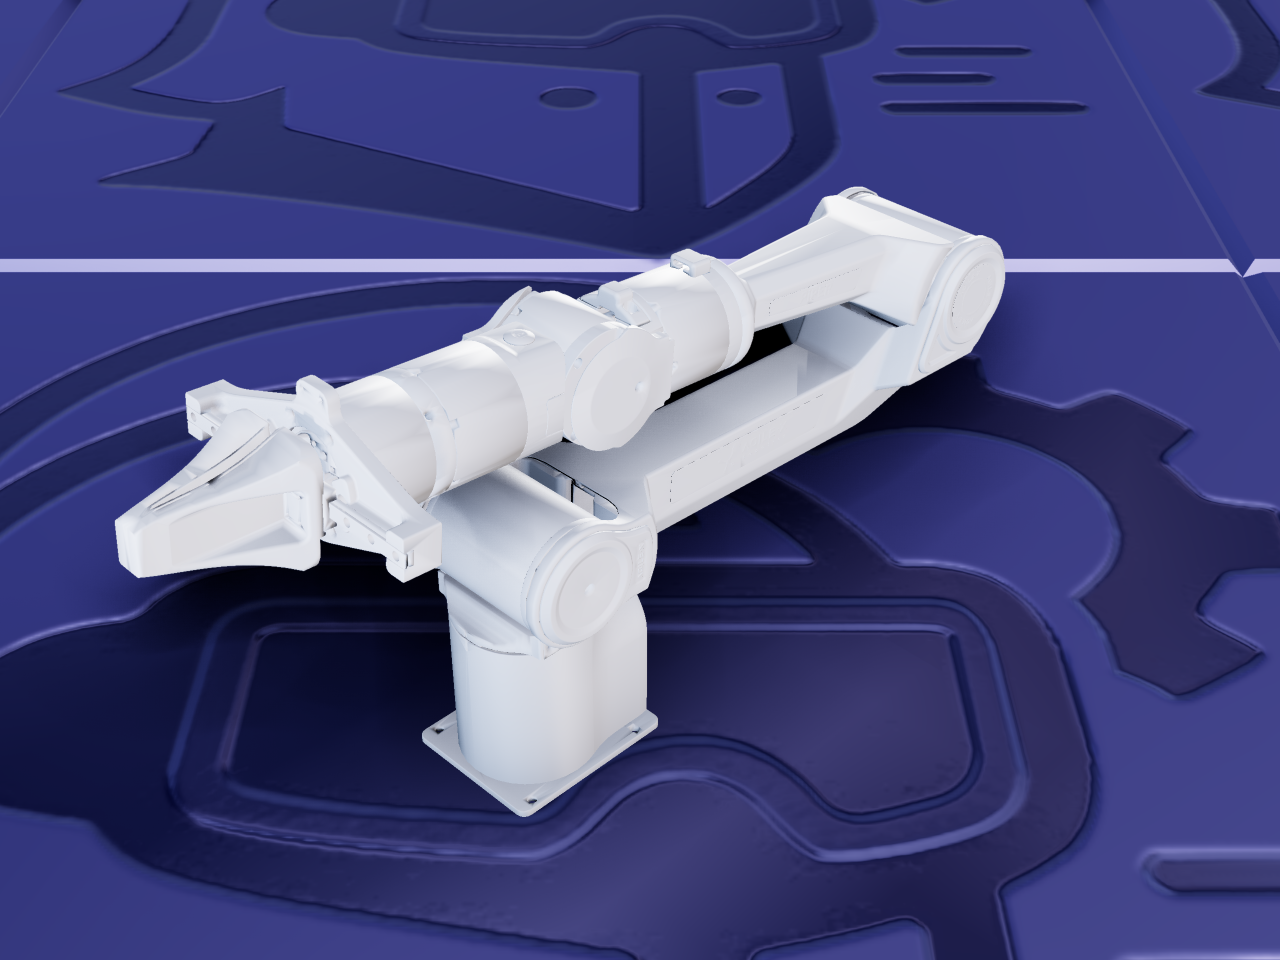
PiPER is a lightweight six-axis robotic arm from AgileX Robotics,
used for manipulation research and embodied-AI work. AgileX publishes the model description
in its piper_ros repository alongside the ROS packages for driving the arm.
The mechanism
The arm is a serial chain of six revolute joints (joint1 to joint6) from the base to the wrist flange. The gripper adds two prismatic finger joints, joint7 and joint8. The file defines them separately, but AgileX’s own simulation scripts drive joint8 as the negative of joint7, so the gripper is one actuated degree of freedom and the arm with gripper has seven. There are no closed kinematic loops.
Which variant matches your robot?
AgileX’s README says the right URDF depends on the arm’s firmware. Firmware S-V1.6-3 or newer offsets the second and third joints’ coordinate systems by about two degrees, and the default files here use that. If your arm runs older firmware, choose the matching older firmware variant. Each pair is otherwise the same arm, and each is also offered without the gripper.
About this file — read before importing
This links directly to the piper_description package of AgileX’s
piper_ros repository. ARMOR links directly to
that repository rather than re-hosting anything, so what you get is exactly what AgileX
publishes, unmodified.